LAST LIGHT
The objective is to recover a six-degree-of-freedom vehicle from an initially descending, laterally displaced and deliberately tilted state, reject atmospheric wind and sensor uncertainty, command thrust and two-axis thrust-vector control (TVC), stabilize the rigid-body attitude, and converge to a near-zero terminal position and velocity. The work is intended as a reverse-engineering and learning framework: every mathematical block is sufficiently explicit to be re- derived, implemented and tested independently.
Challenge
The main challenge was to integrate a complete closed-loop Guidance, Navigation and Control (GNC) architecture with a nonlinear 6-DOF vehicle model while maintaining numerical stability and physically meaningful behavior. Particular attention was required to prevent uncontrolled rotation around the vehicle longitudinal axis and to ensure that position, velocity and attitude errors converged throughout the descent.
Approach
A modular Python-based 6-DOF simulation was developed by separating the system into plant dynamics, navigation, guidance, and control. The plant includes gravity, atmospheric drag, stochastic wind, variable mass, thrust-vector control, and actuator degradation, while the navigation subsystem combines inertial propagation with simulated GPS, barometric, and attitude measurements. The guidance layer generates altitude-dependent velocity and acceleration references for powered descent, and the controller converts them into thrust, TVC, and quaternion-based attitude-control commands. A fixed upright reference attitude is kept separate from the deliberately tilted initial condition, allowing the vehicle to recover from large orientation errors while converging toward the landing target.
Outcome
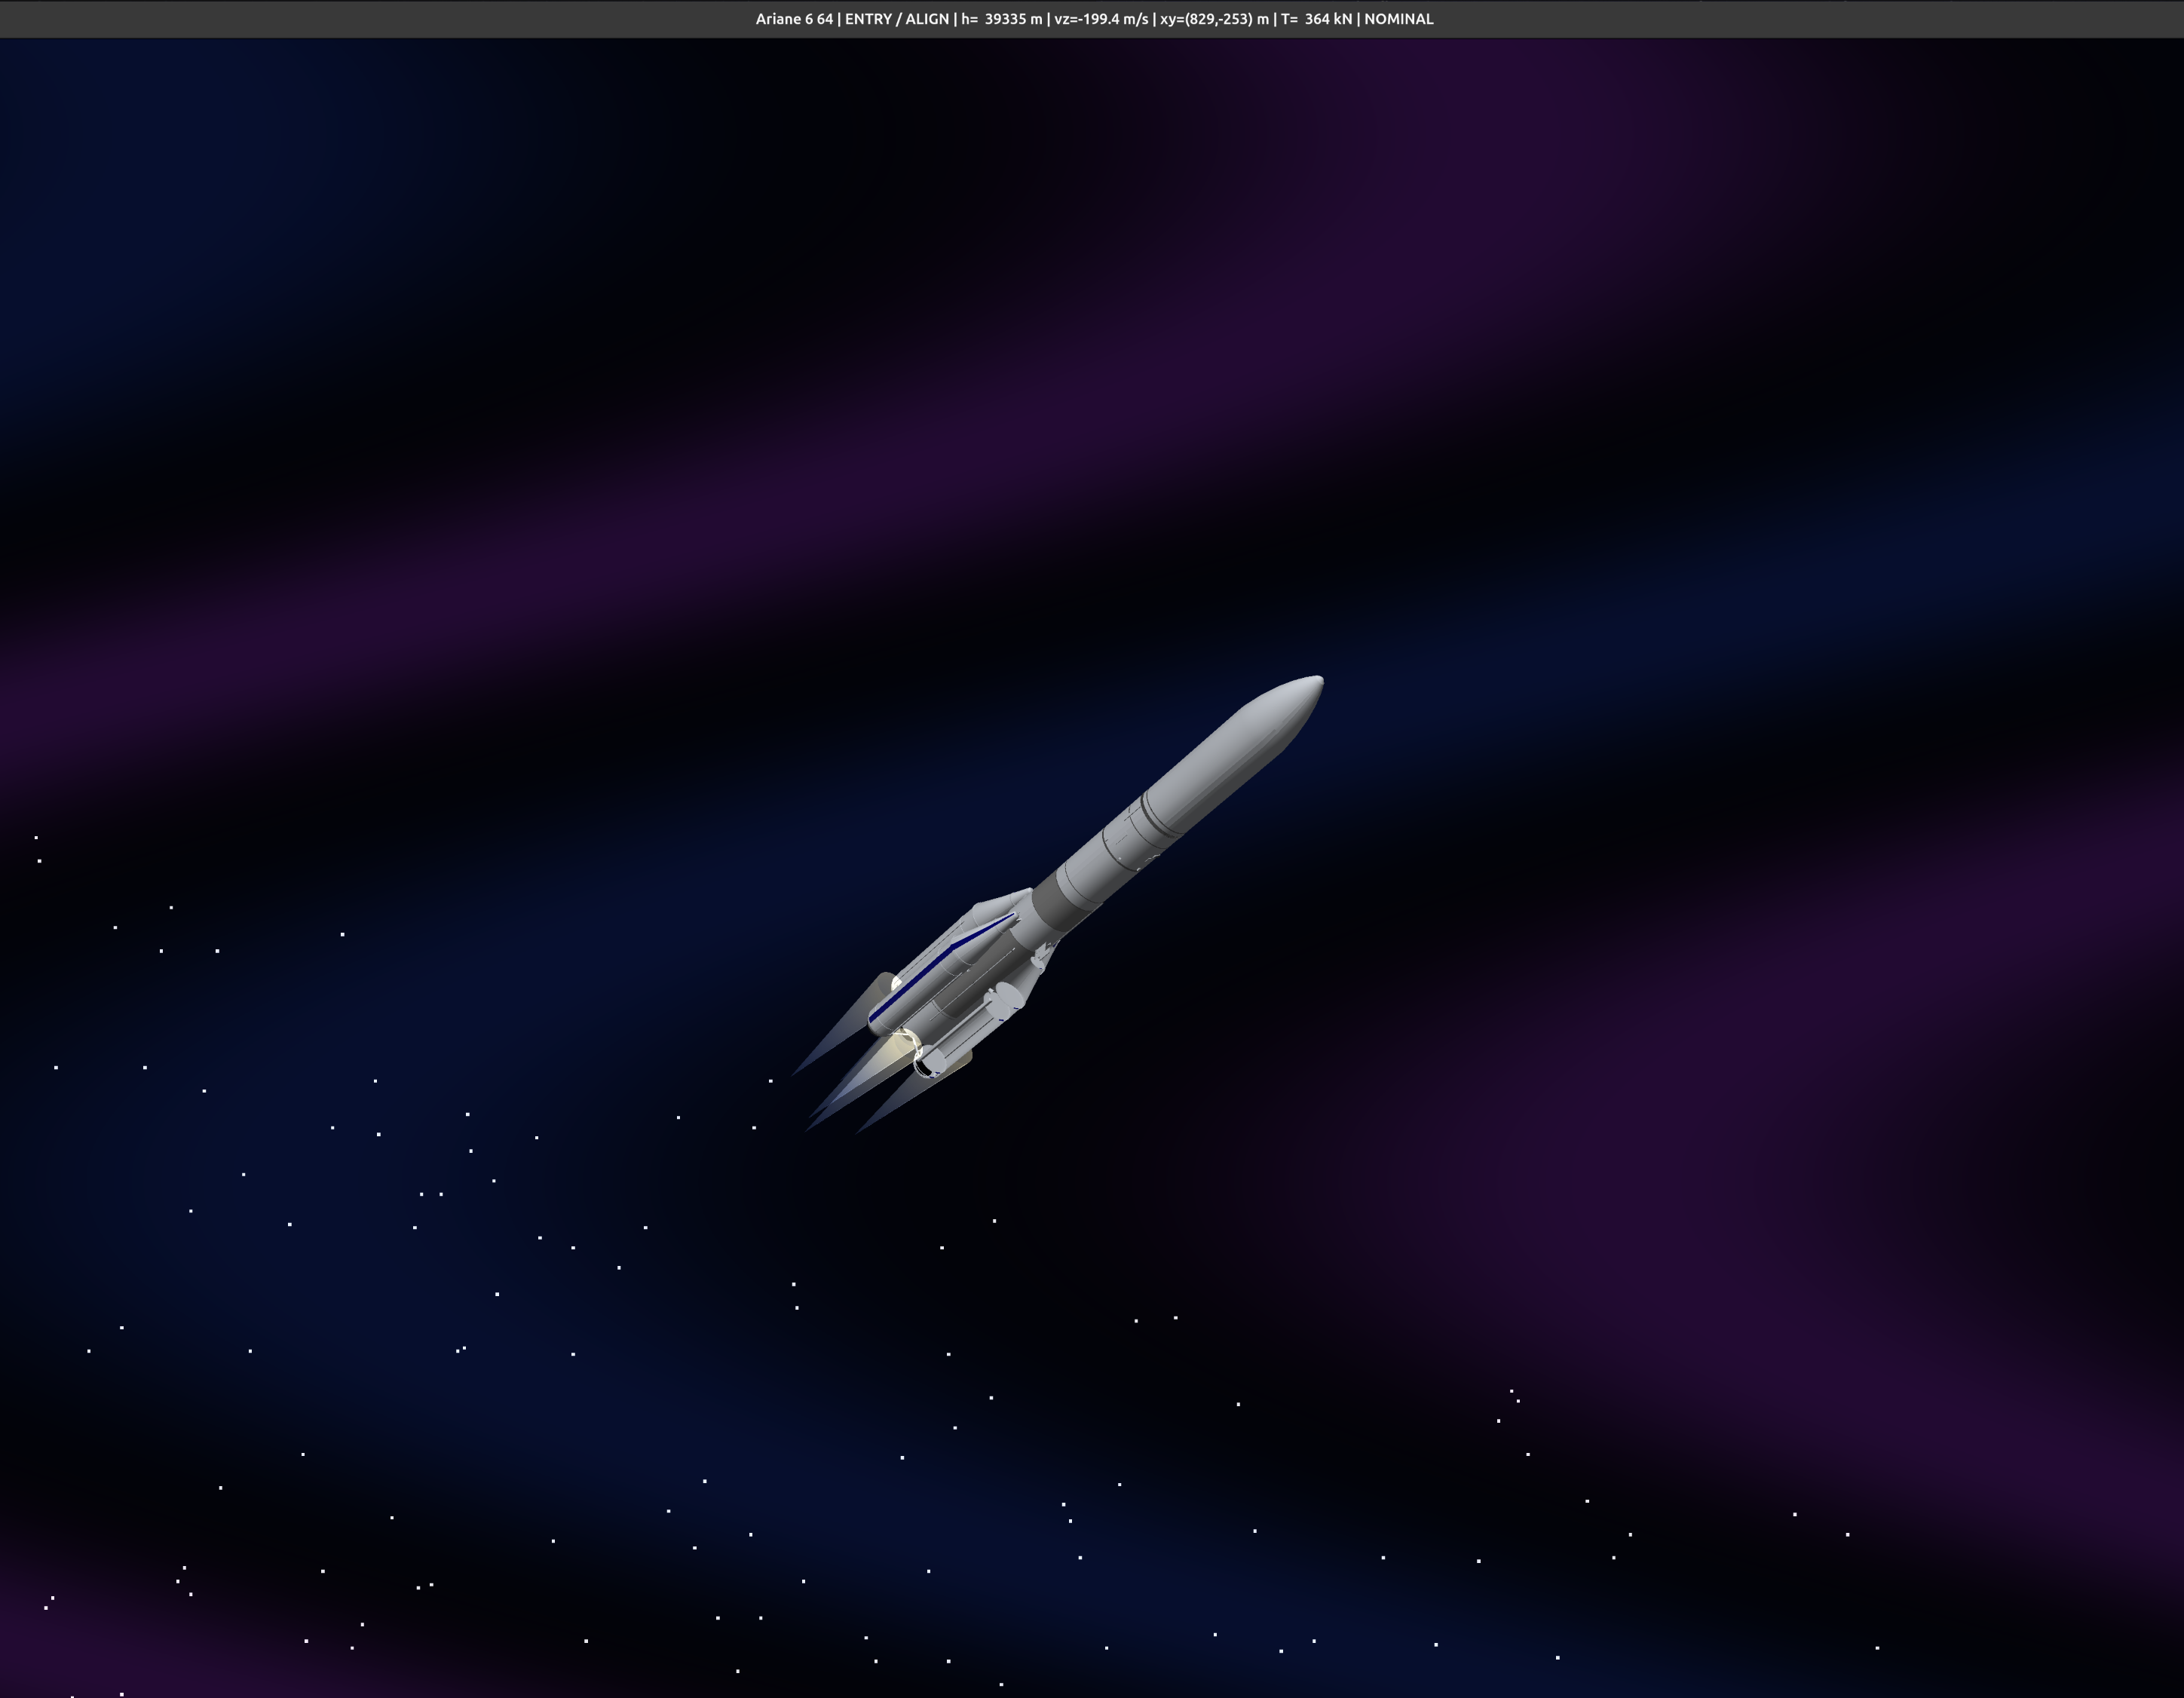
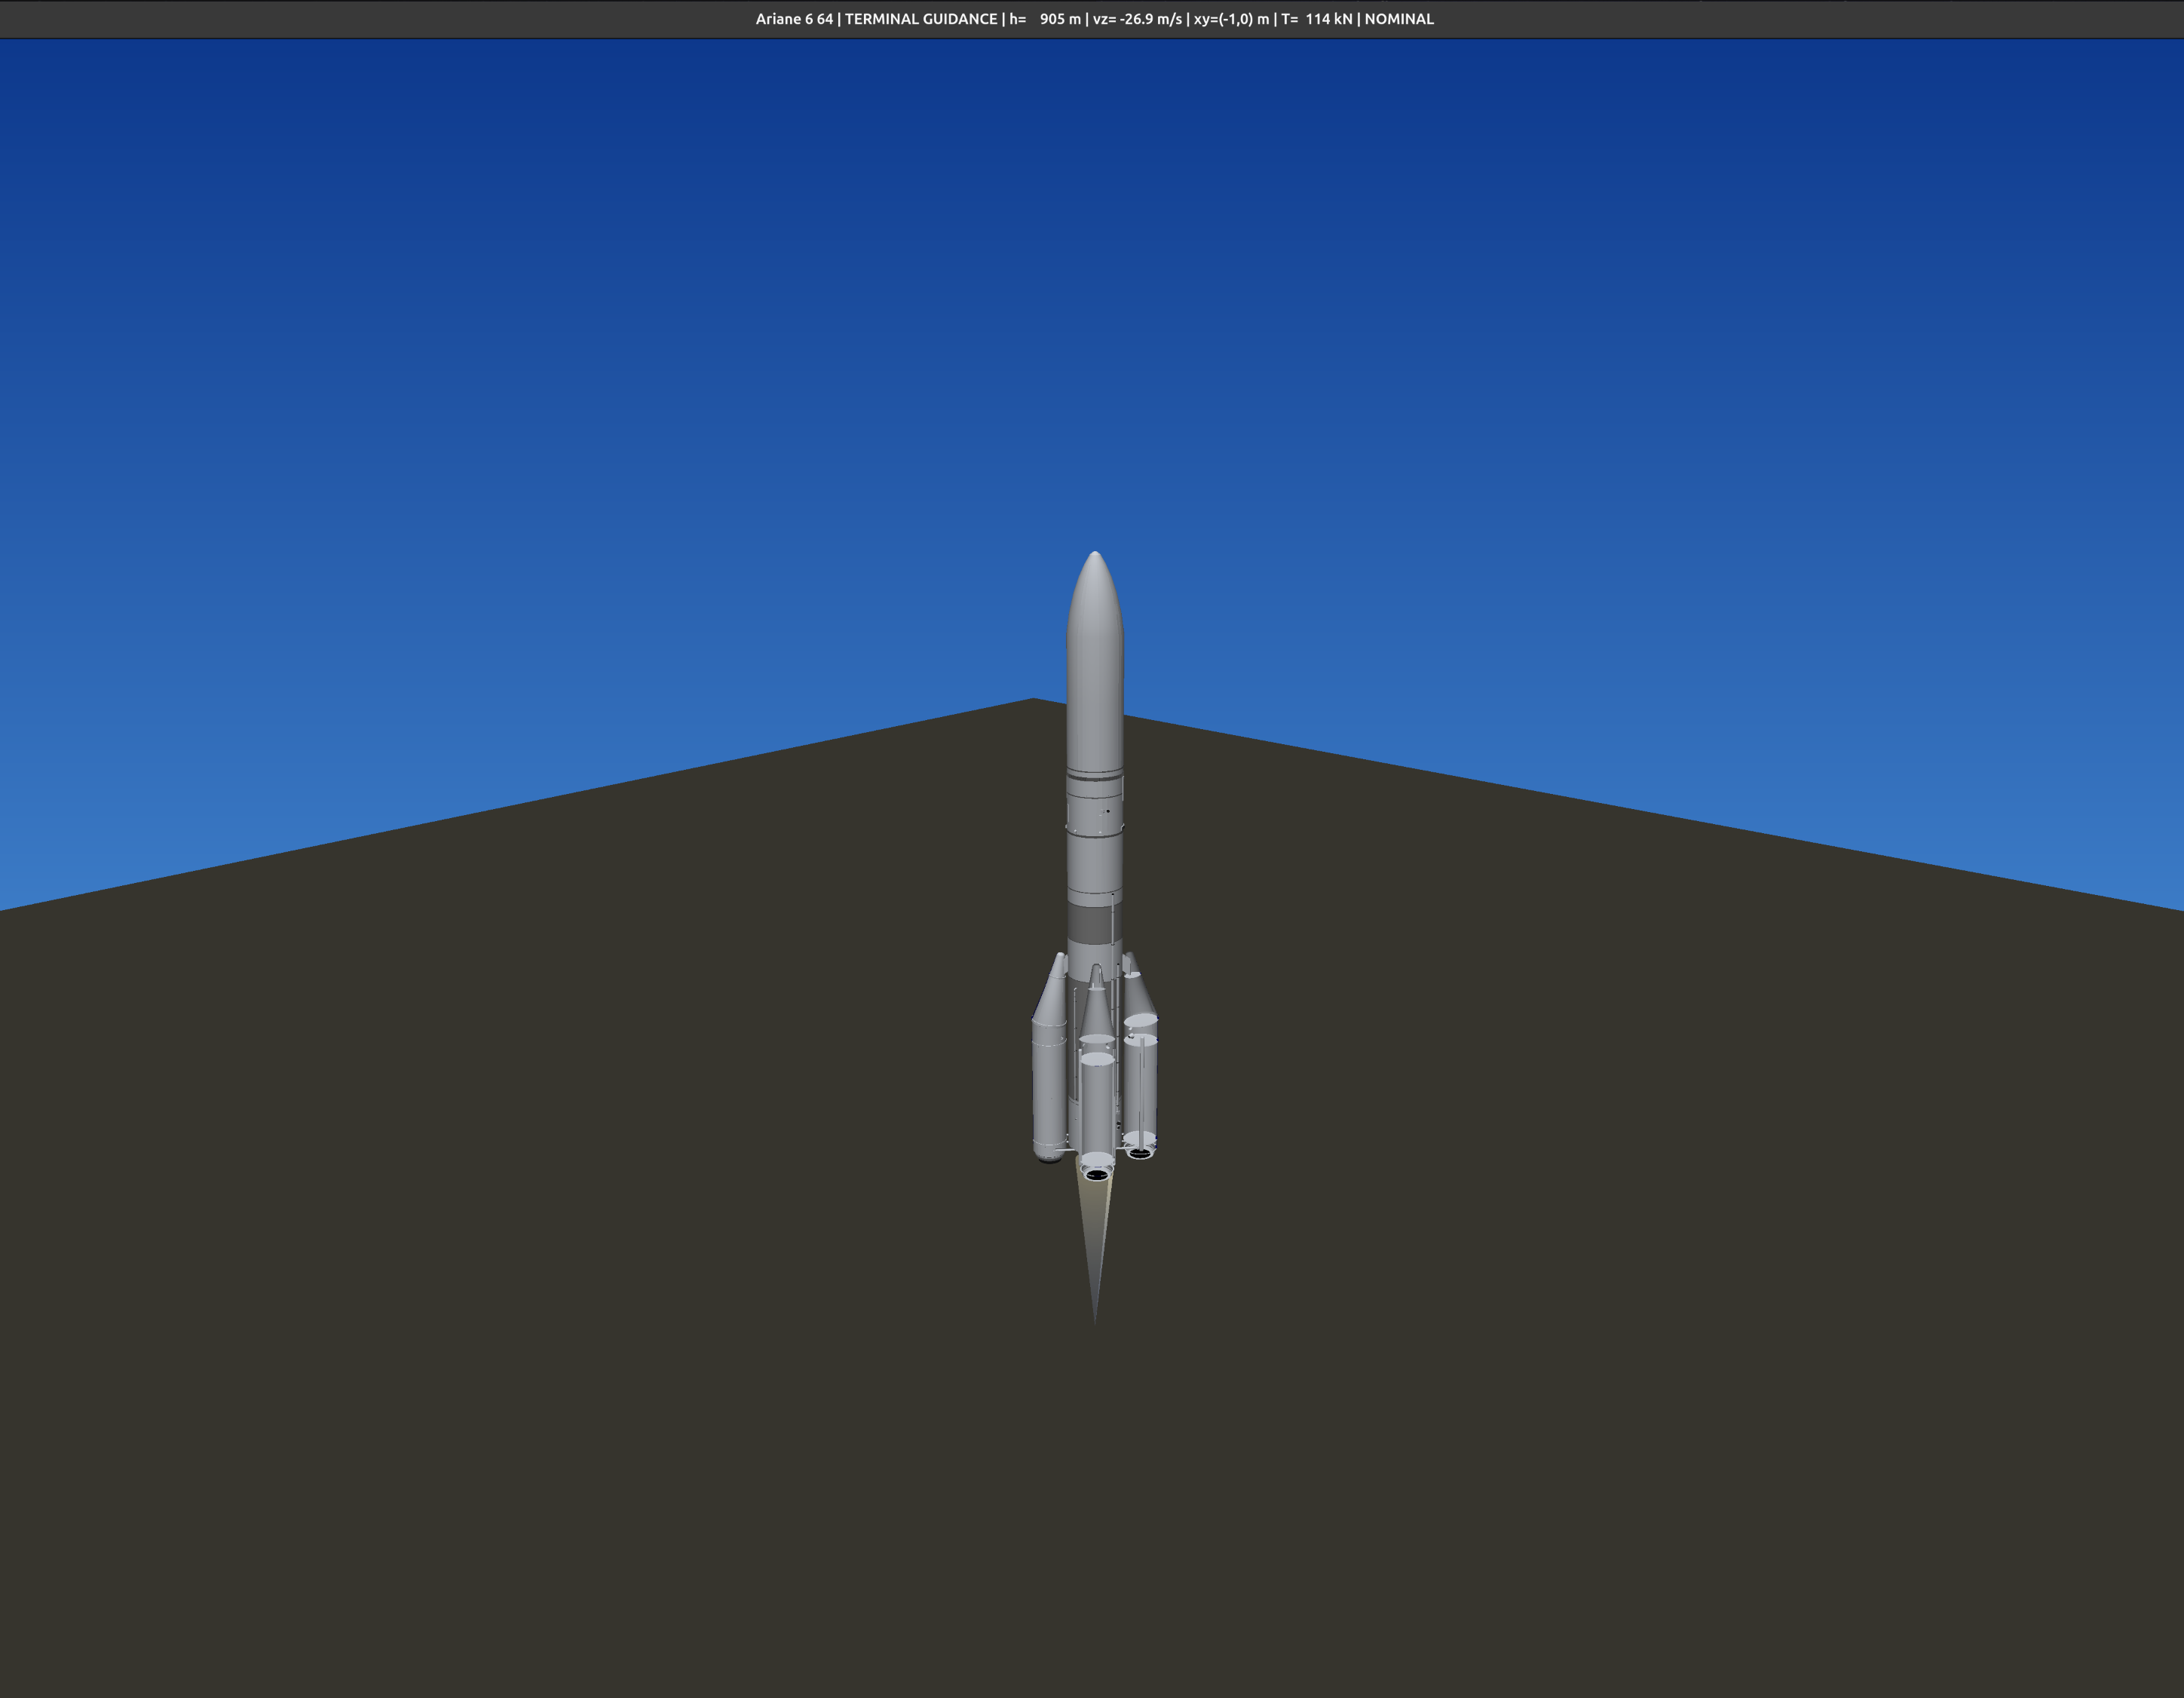
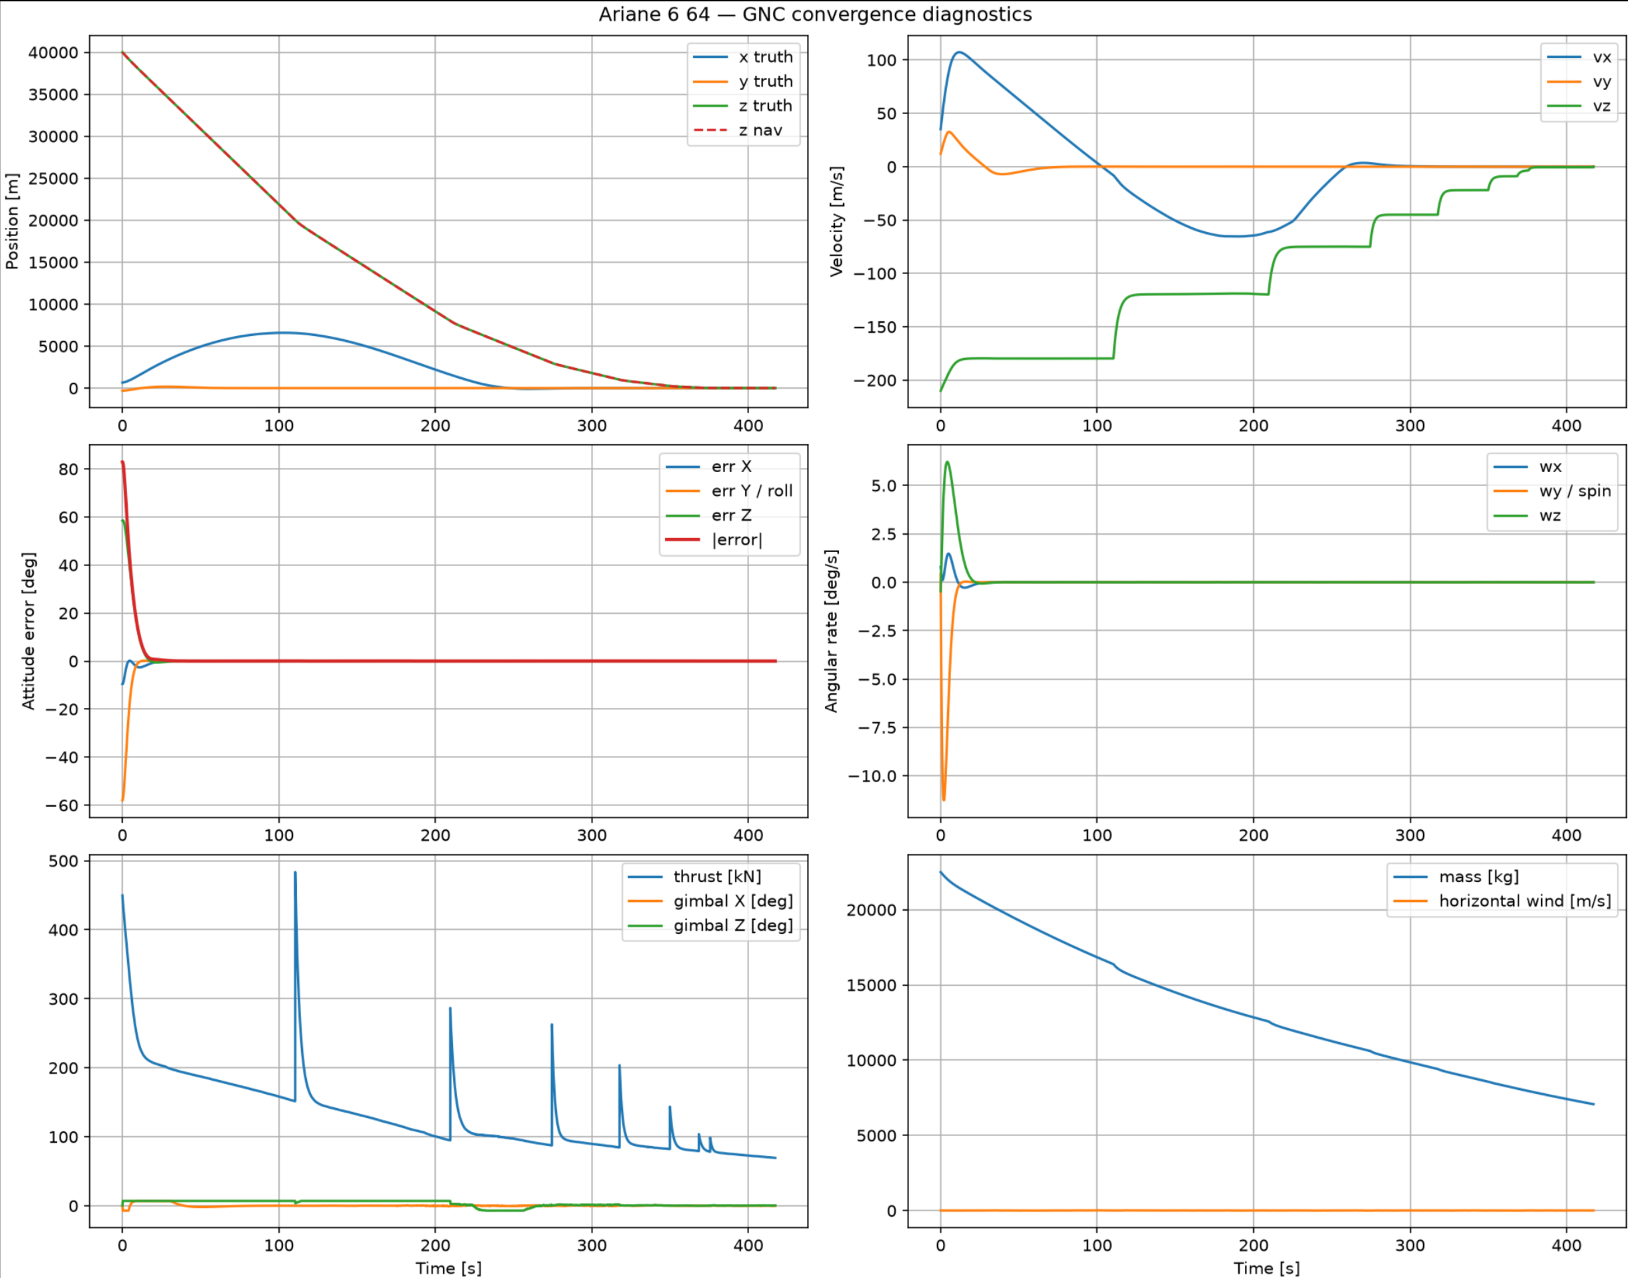
The final simulation demonstrates a stable autonomous powered descent from 40 km altitude, with the vehicle starting from a significant attitude perturbation and non-zero angular rates, then progressively stabilizing as attitude error and body rates converge toward zero. At the same time, the guidance and control system reduce horizontal position error, manage descent velocity through successive braking phases, and drive the vehicle toward the target landing point. The result is a complete conceptual GNC demonstrator with measurable convergence in position, velocity, attitude, thrust, and TVC behavior, supported by a desktop 3D visualization of the Ariane 6 64 vehicle and engine plume effects.