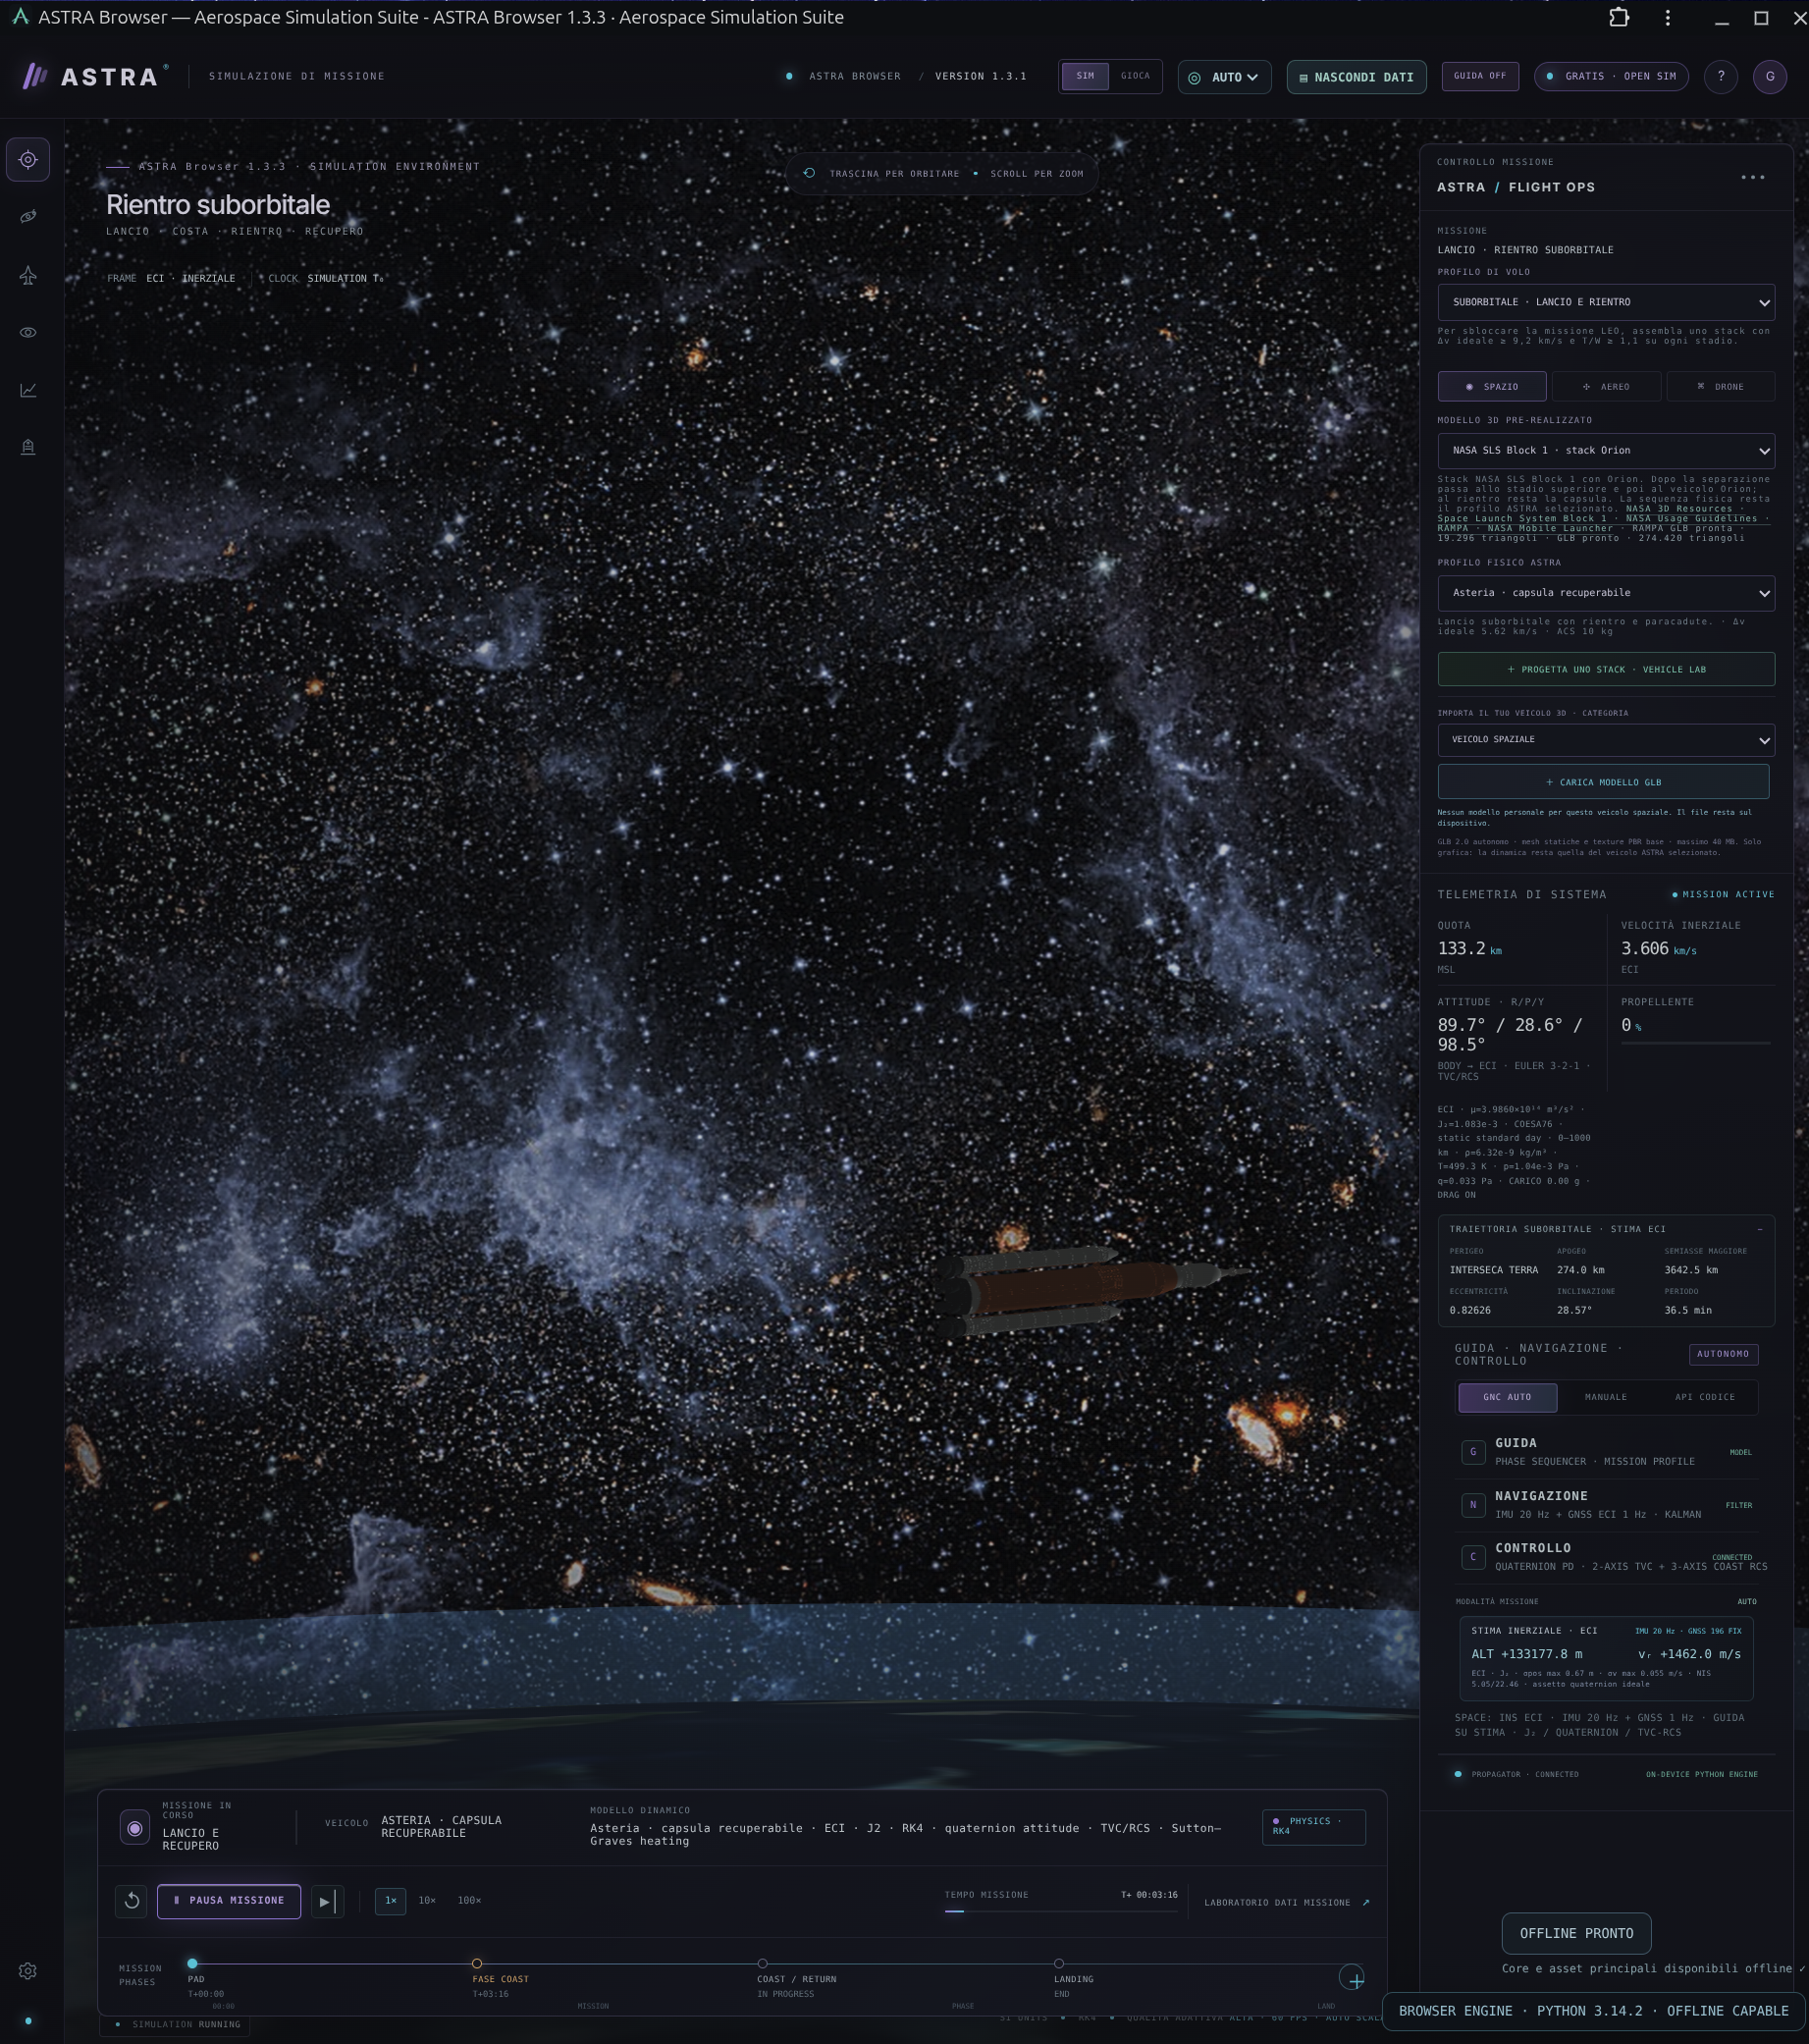
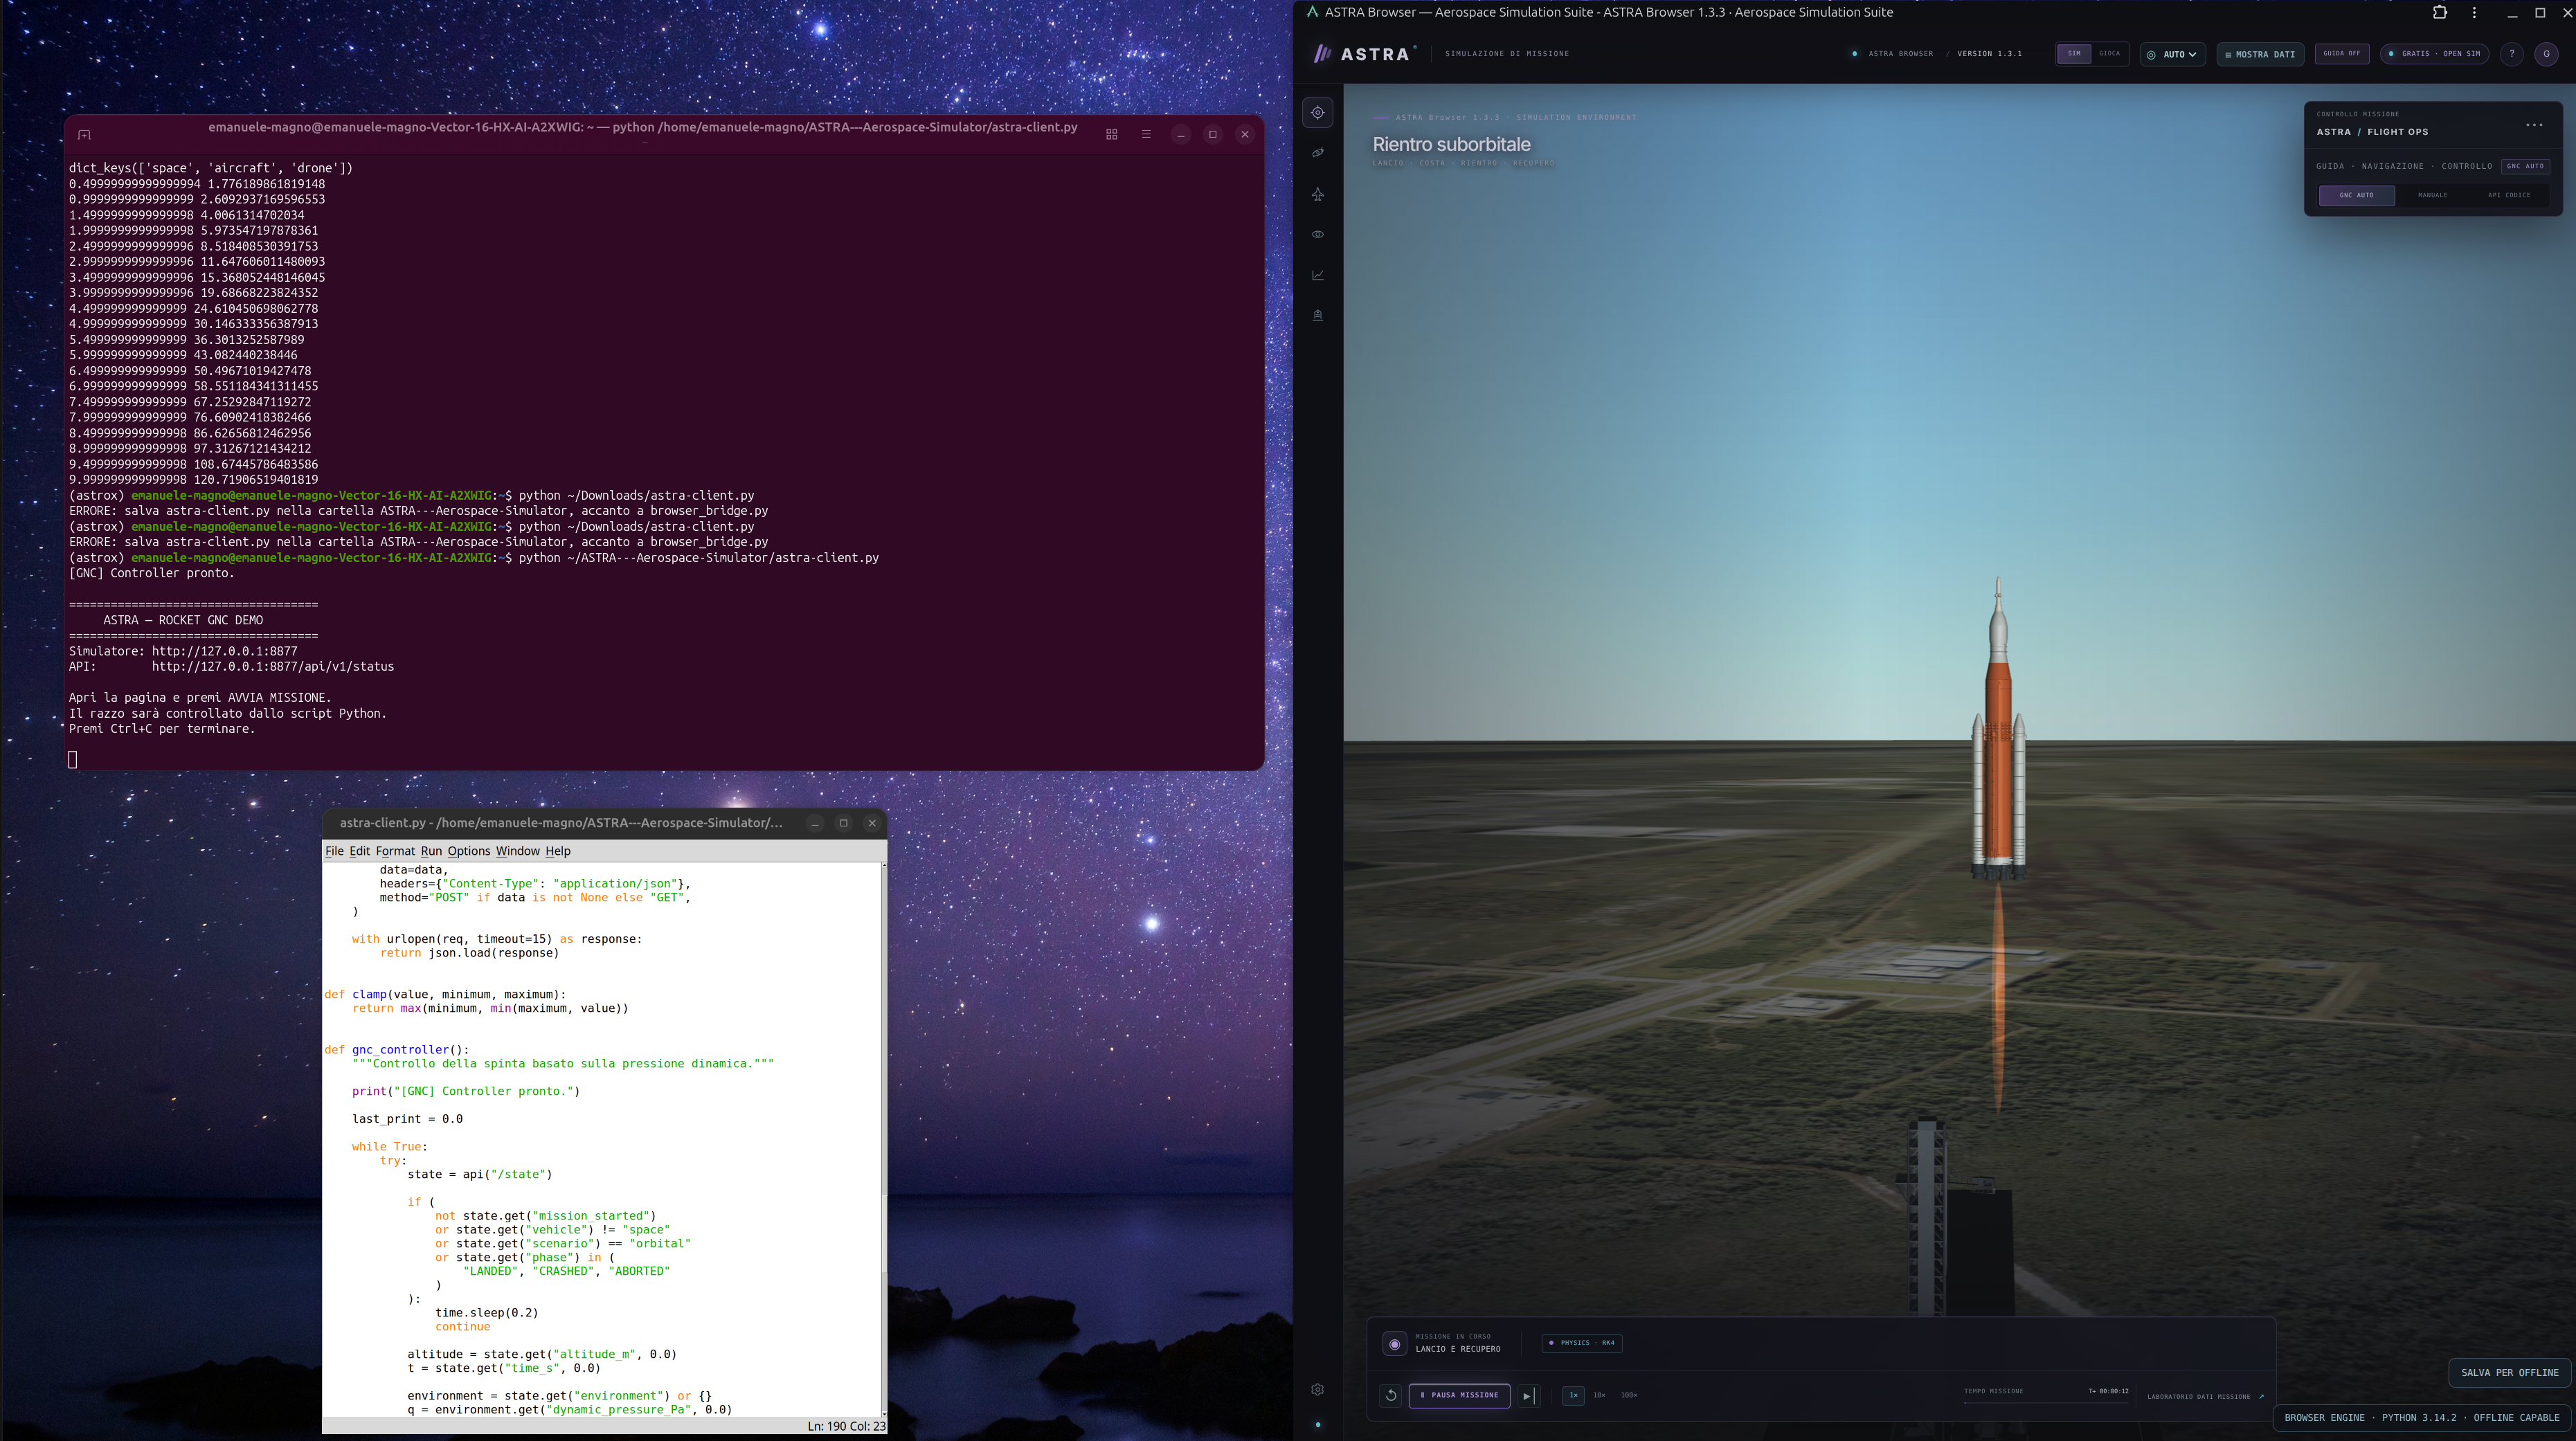
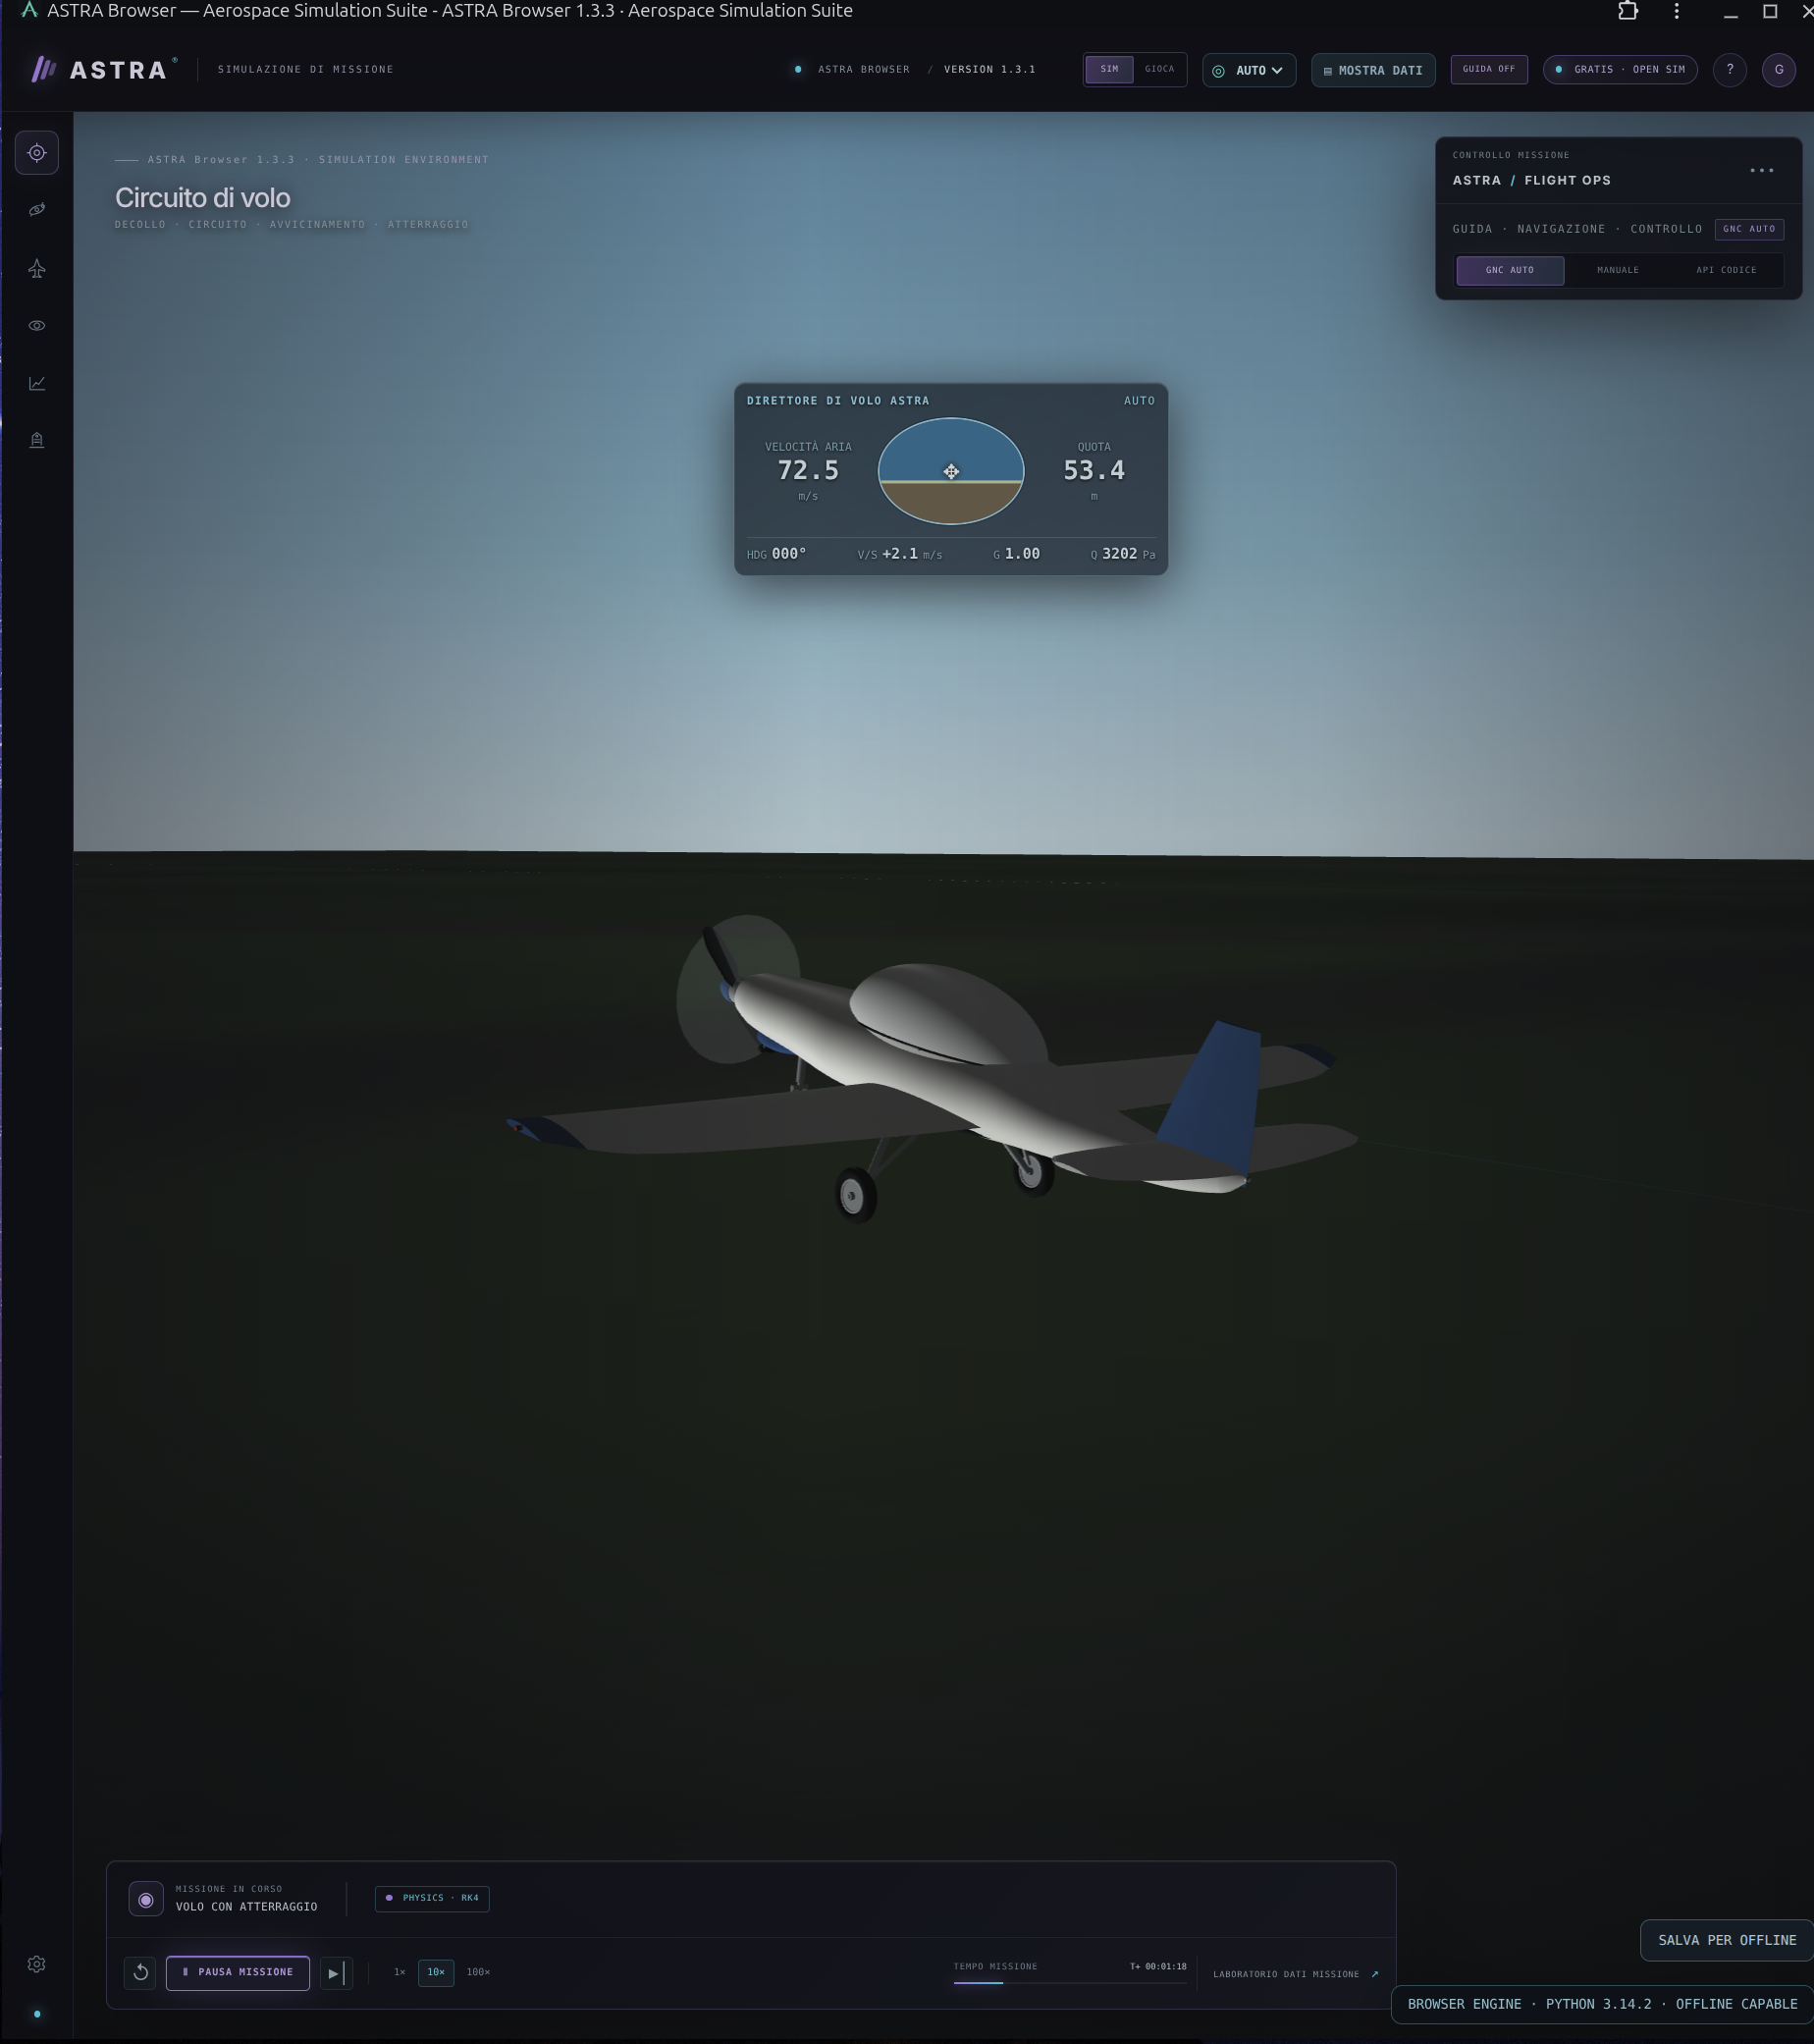
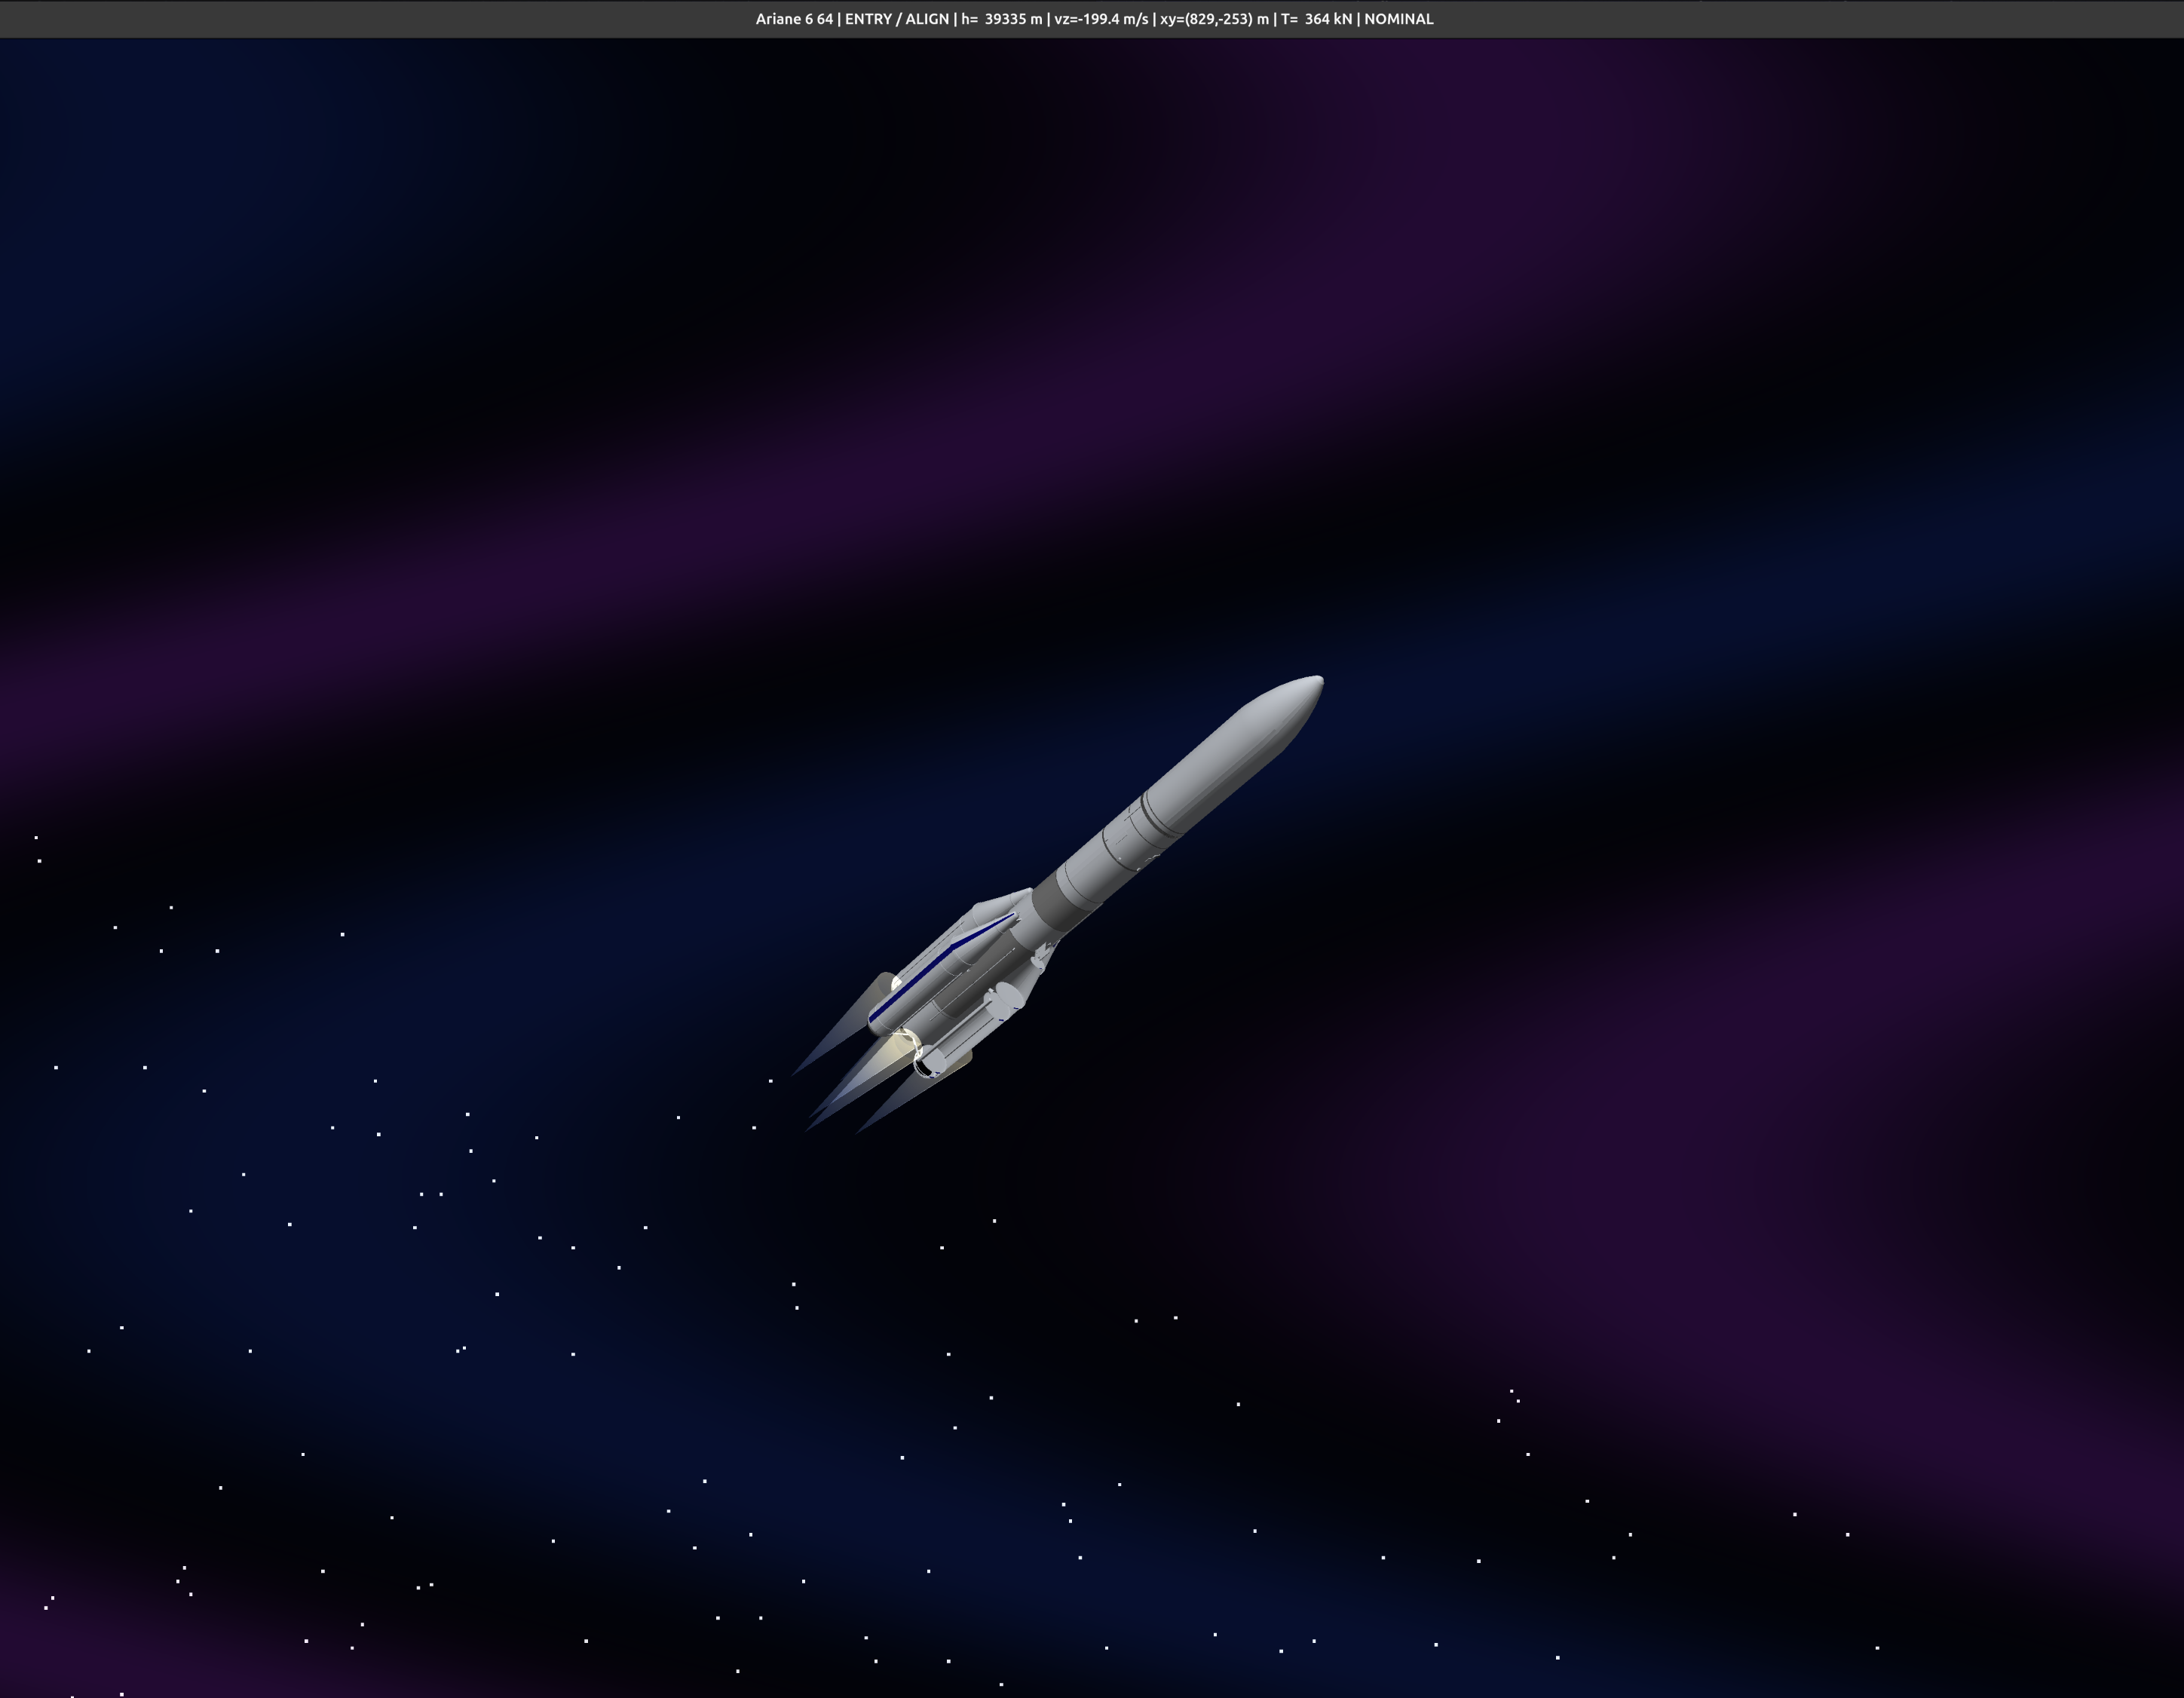
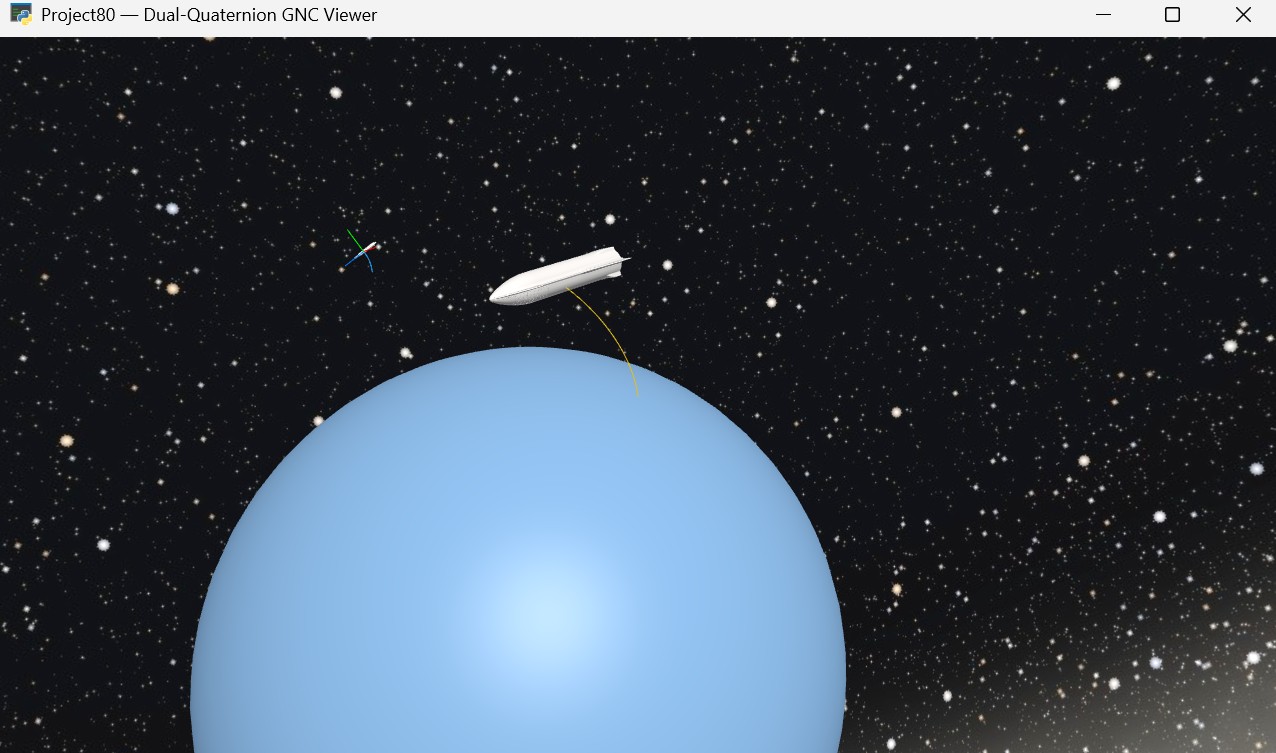
A high-fidelity aerospace simulation environment designed to visualize orbital mechanics, spacecraft dynamics, and mission operations in real time. The simulator serves as both an engineering tool and an educational platform for aerospace system development.
Create an accurate yet interactive simulation capable of reproducing realistic spacecraft behavior while remaining flexible enough for integrating future GNC, ADCS, and mission-planning modules.
Approach
Implemented a modular simulation engine combining orbital mechanics, spacecraft dynamics, visualization, and numerical integration techniques. The architecture emphasizes extensibility, allowing new spacecraft subsystems and control algorithms to be integrated with minimal modifications.
Outcome
Delivered a scalable spacecraft simulator suitable for validating aerospace algorithms, demonstrating orbital maneuvers, and supporting future research in autonomous space systems.
Tools
PythonNumPyMatplotlib
Roadmap
Astra Space Simulator
A high-fidelity spacecraft simulation environment designed to visualize orbital mechanics, spacecraft dynamics, and mission operations in real time. The simulator serves as both an engineering tool and an educational platform for spacecraft system development.
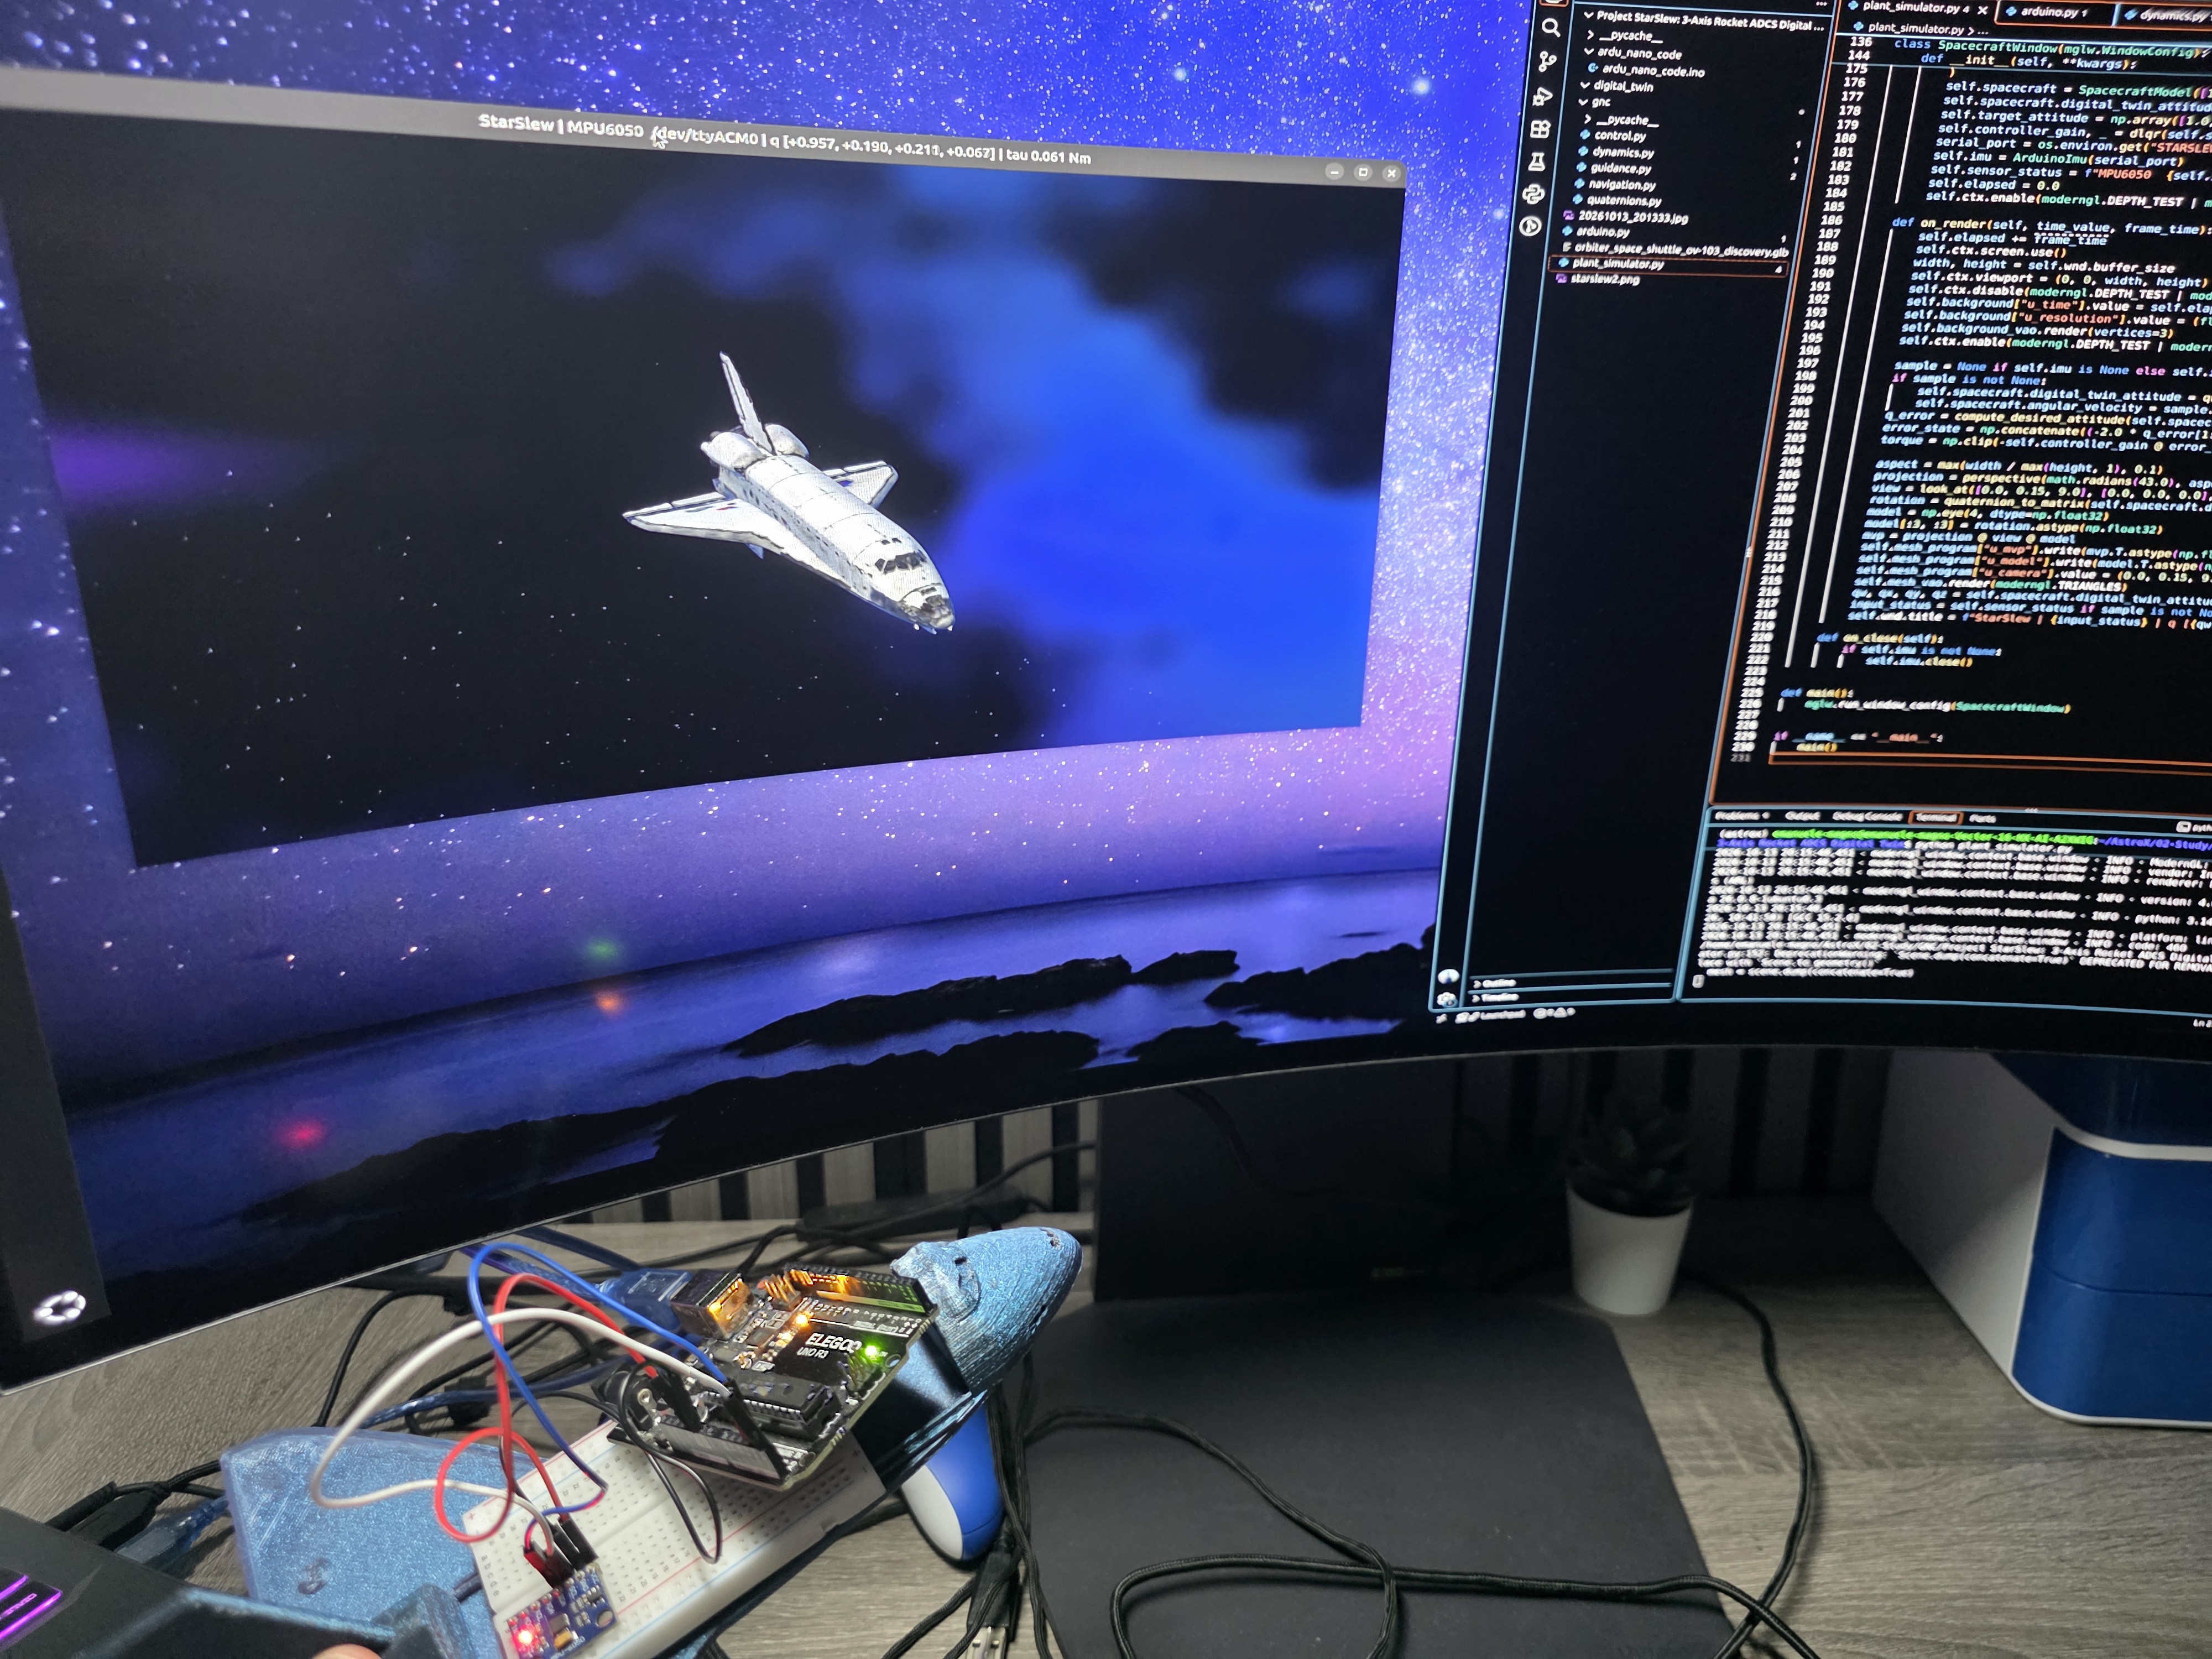
TECHNICAL PROJECT / Project StarSlew 3-Axis Rocket ADCS Digital Twin
StarSlew is a 3-axis attitude-control digital twin that connects an Arduino Nano and MPU6050 to a quaternion-based GNC software stack and a 3D spacecraft visualization.
TECHNICAL PROJECT / Robust 6-DOF Guidance, Navigation and Control for Autonomous Powered Descent Under Wind, Navigation Uncertainty and Partial Actuator Degradation
The objective is to recover a six-degree-of-freedom vehicle from an initially descending, laterally displaced and
deliberately tilted state, reject atmospheric wind and sensor uncertainty, command thrust and two-axis t…
TECHNICAL PROJECT / Dual Quaternion GNC for Spacecraft Proximity Operations
A six-degree-of-freedom Guidance, Navigation and Control framework using dual quaternions to simultaneously represent spacecraft translation and rotation during autonomous proximity operations.