✳ ASTROX/ 02
← MISSION ARCHIVE / GNC

QUIET RENDEZVOUS

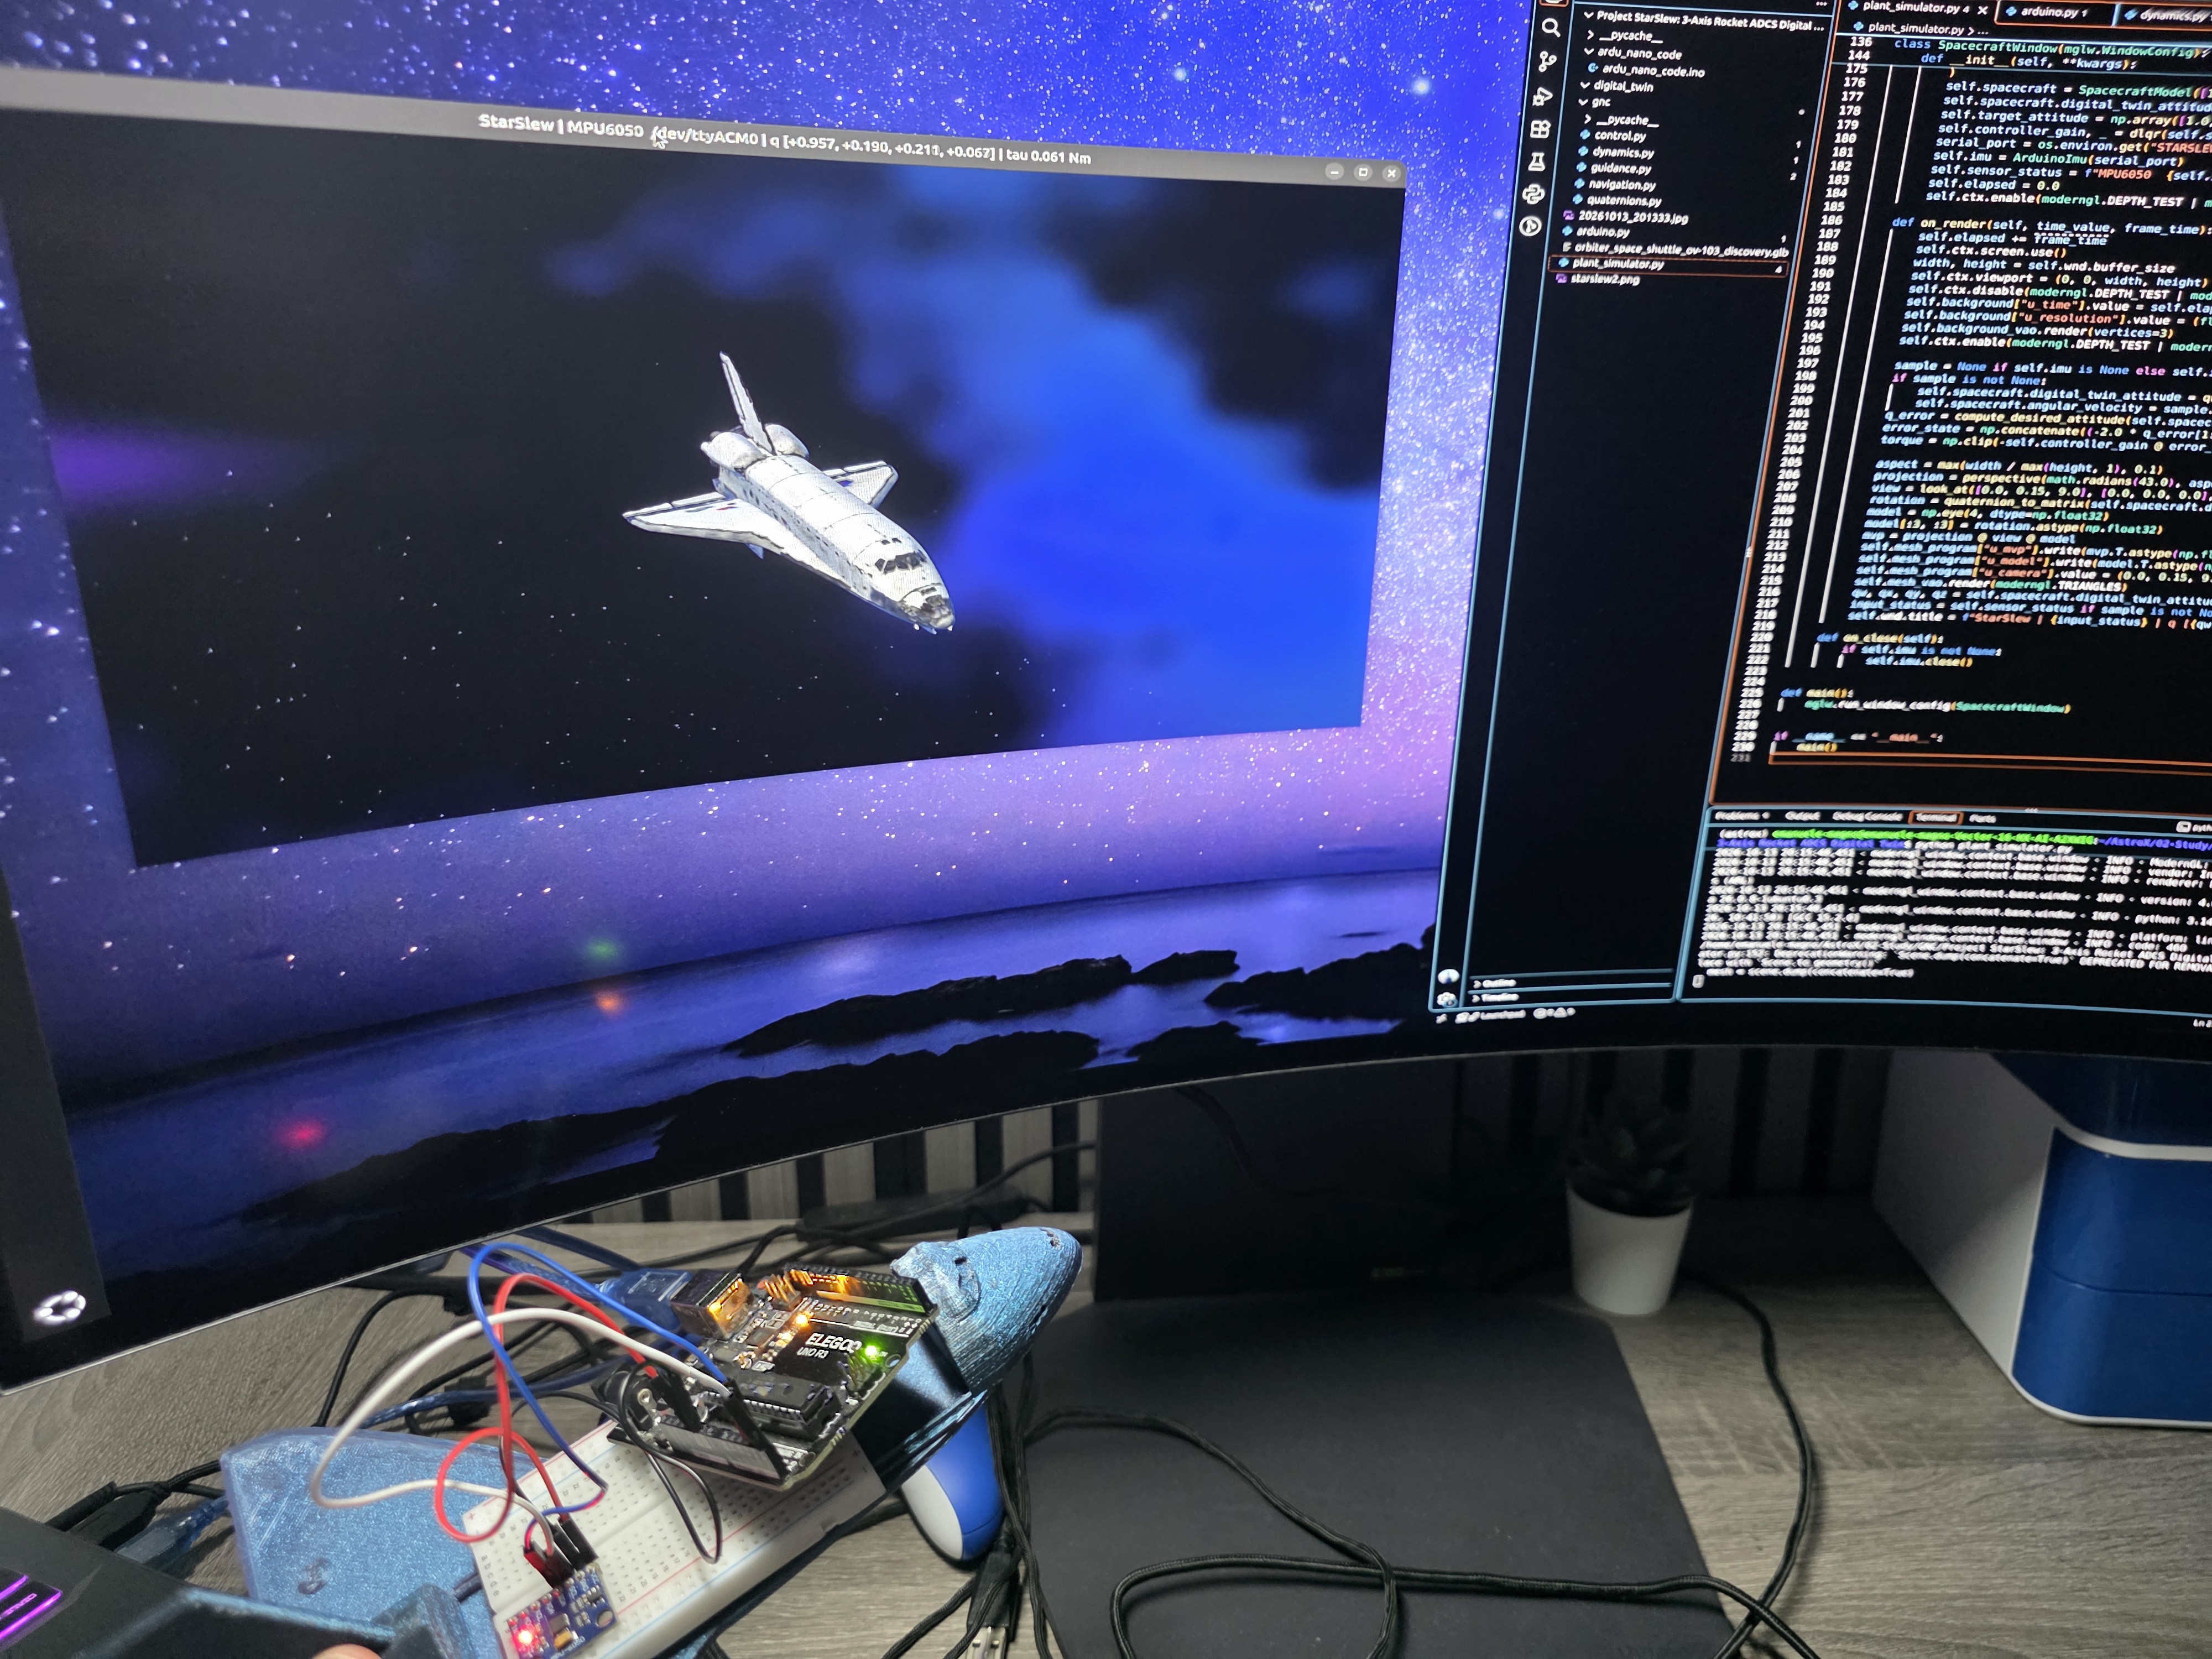
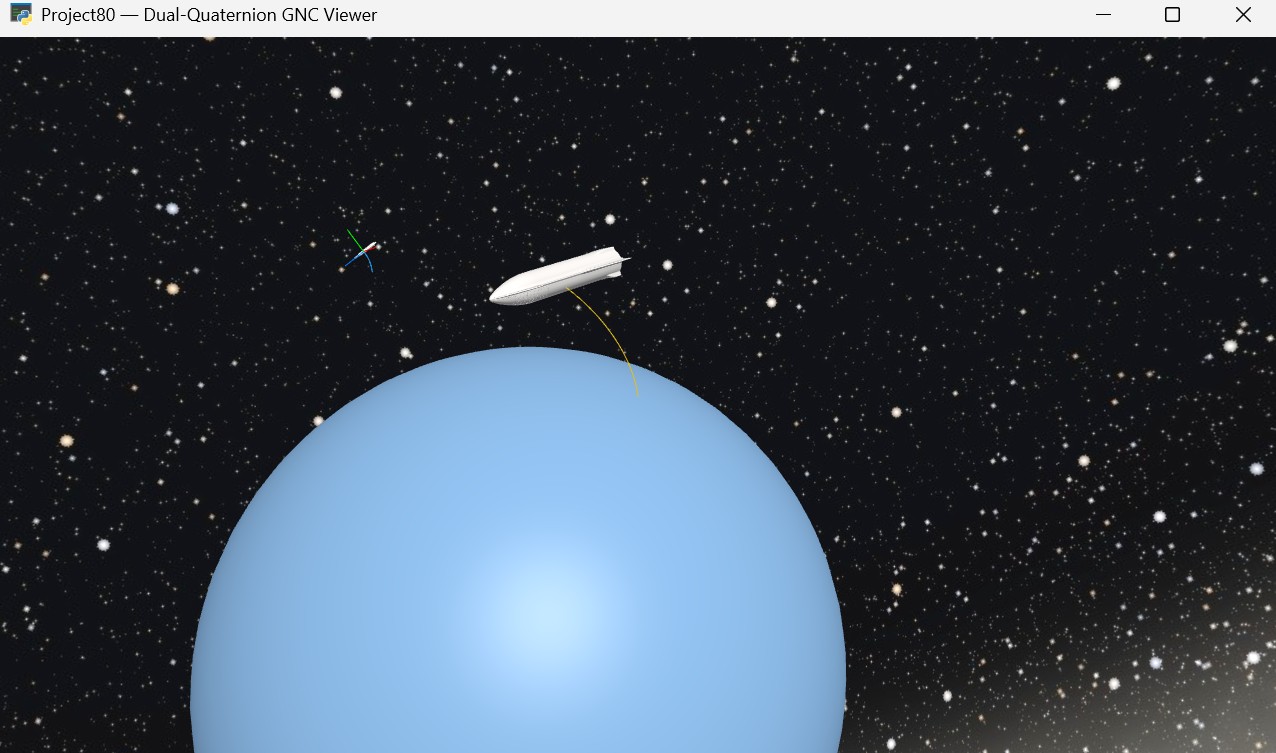
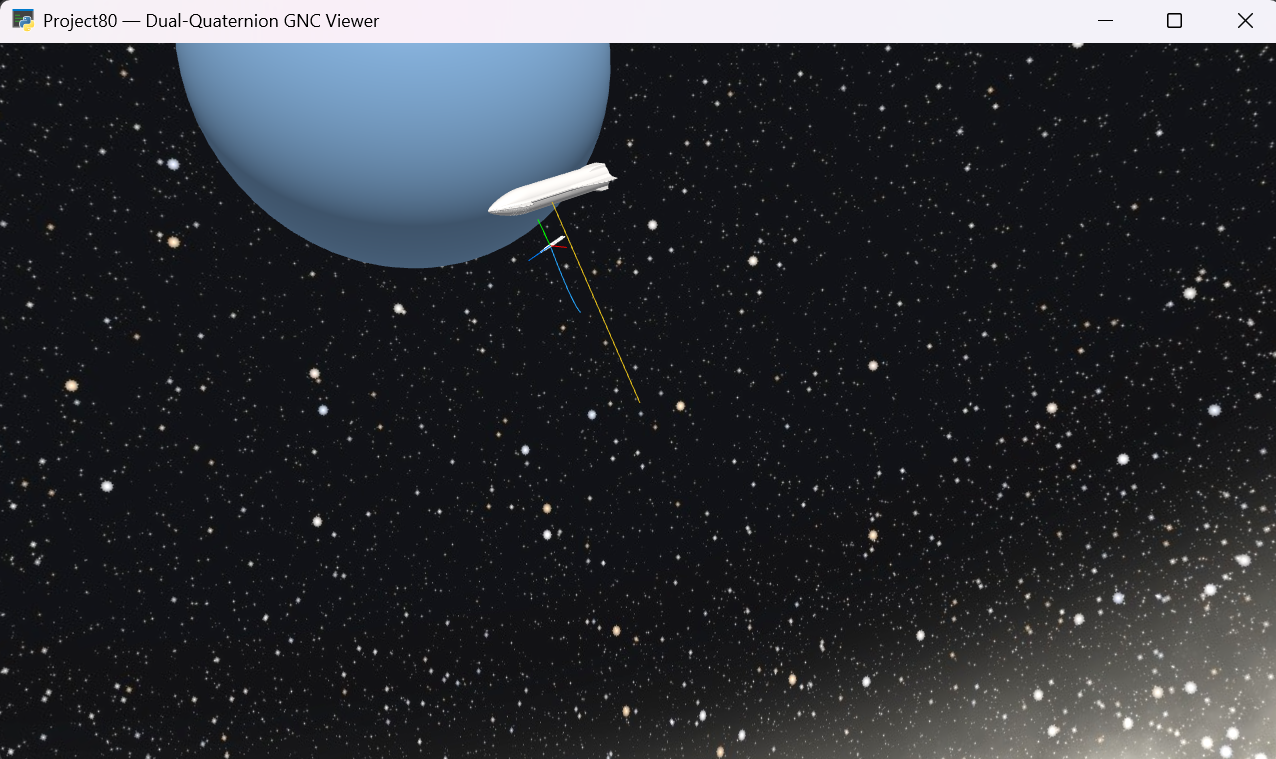
TECHNICAL PROJECT / Dual Quaternion GNC for Spacecraft Proximity Operations

A six-degree-of-freedom Guidance, Navigation and Control framework using dual quaternions to simultaneously represent spacecraft translation and rotation during autonomous proximity operations.
2026_06

Source code ↗

Challenge

Develop a unified mathematical representation capable of controlling both spacecraft position and orientation without singularities or inconsistent reference frames.

Approach

Implemented dual quaternion kinematics and control algorithms to integrate translational and rotational motion into a single control framework. The system performs coordinated relative motion while maintaining precise attitude alignment.

Outcome

Successfully demonstrated stable and accurate autonomous proximity maneuvers using a compact six-degree-of-freedom control formulation suitable for advanced rendezvous missions.

Tools

PythonNumPySciPy

Roadmap

  1. Dual Quaternion GNC for Spacecraft Proximity Operations

    A six-degree-of-freedom Guidance, Navigation and Control framework using dual quaternions to simultaneously represent spacecraft translation and rotation during autonomous proximity operations.

    Completed
MISSION CONSOLE / BROWSER RUN

QUIET RENDEZVOUS

Browser model · assumptions shown

Run a planar Clohessy–Wiltshire relative-motion approach with bounded control and a keep-out zone. The model runs locally in this browser; it does not execute unpublished source code.

INITIAL CONDITIONS / MODEL PARAMETERS

SCHEMATIC 3D / DRAG TO ROTATE

Illustrative geometry; not the original CAD model.

Adjust the conditions, then run the simulation.

Model assumptions and limits

RELATED / SHARED TECHNOLOGIES

LAST LIGHT

GNC Completed

LAST LIGHT ↗

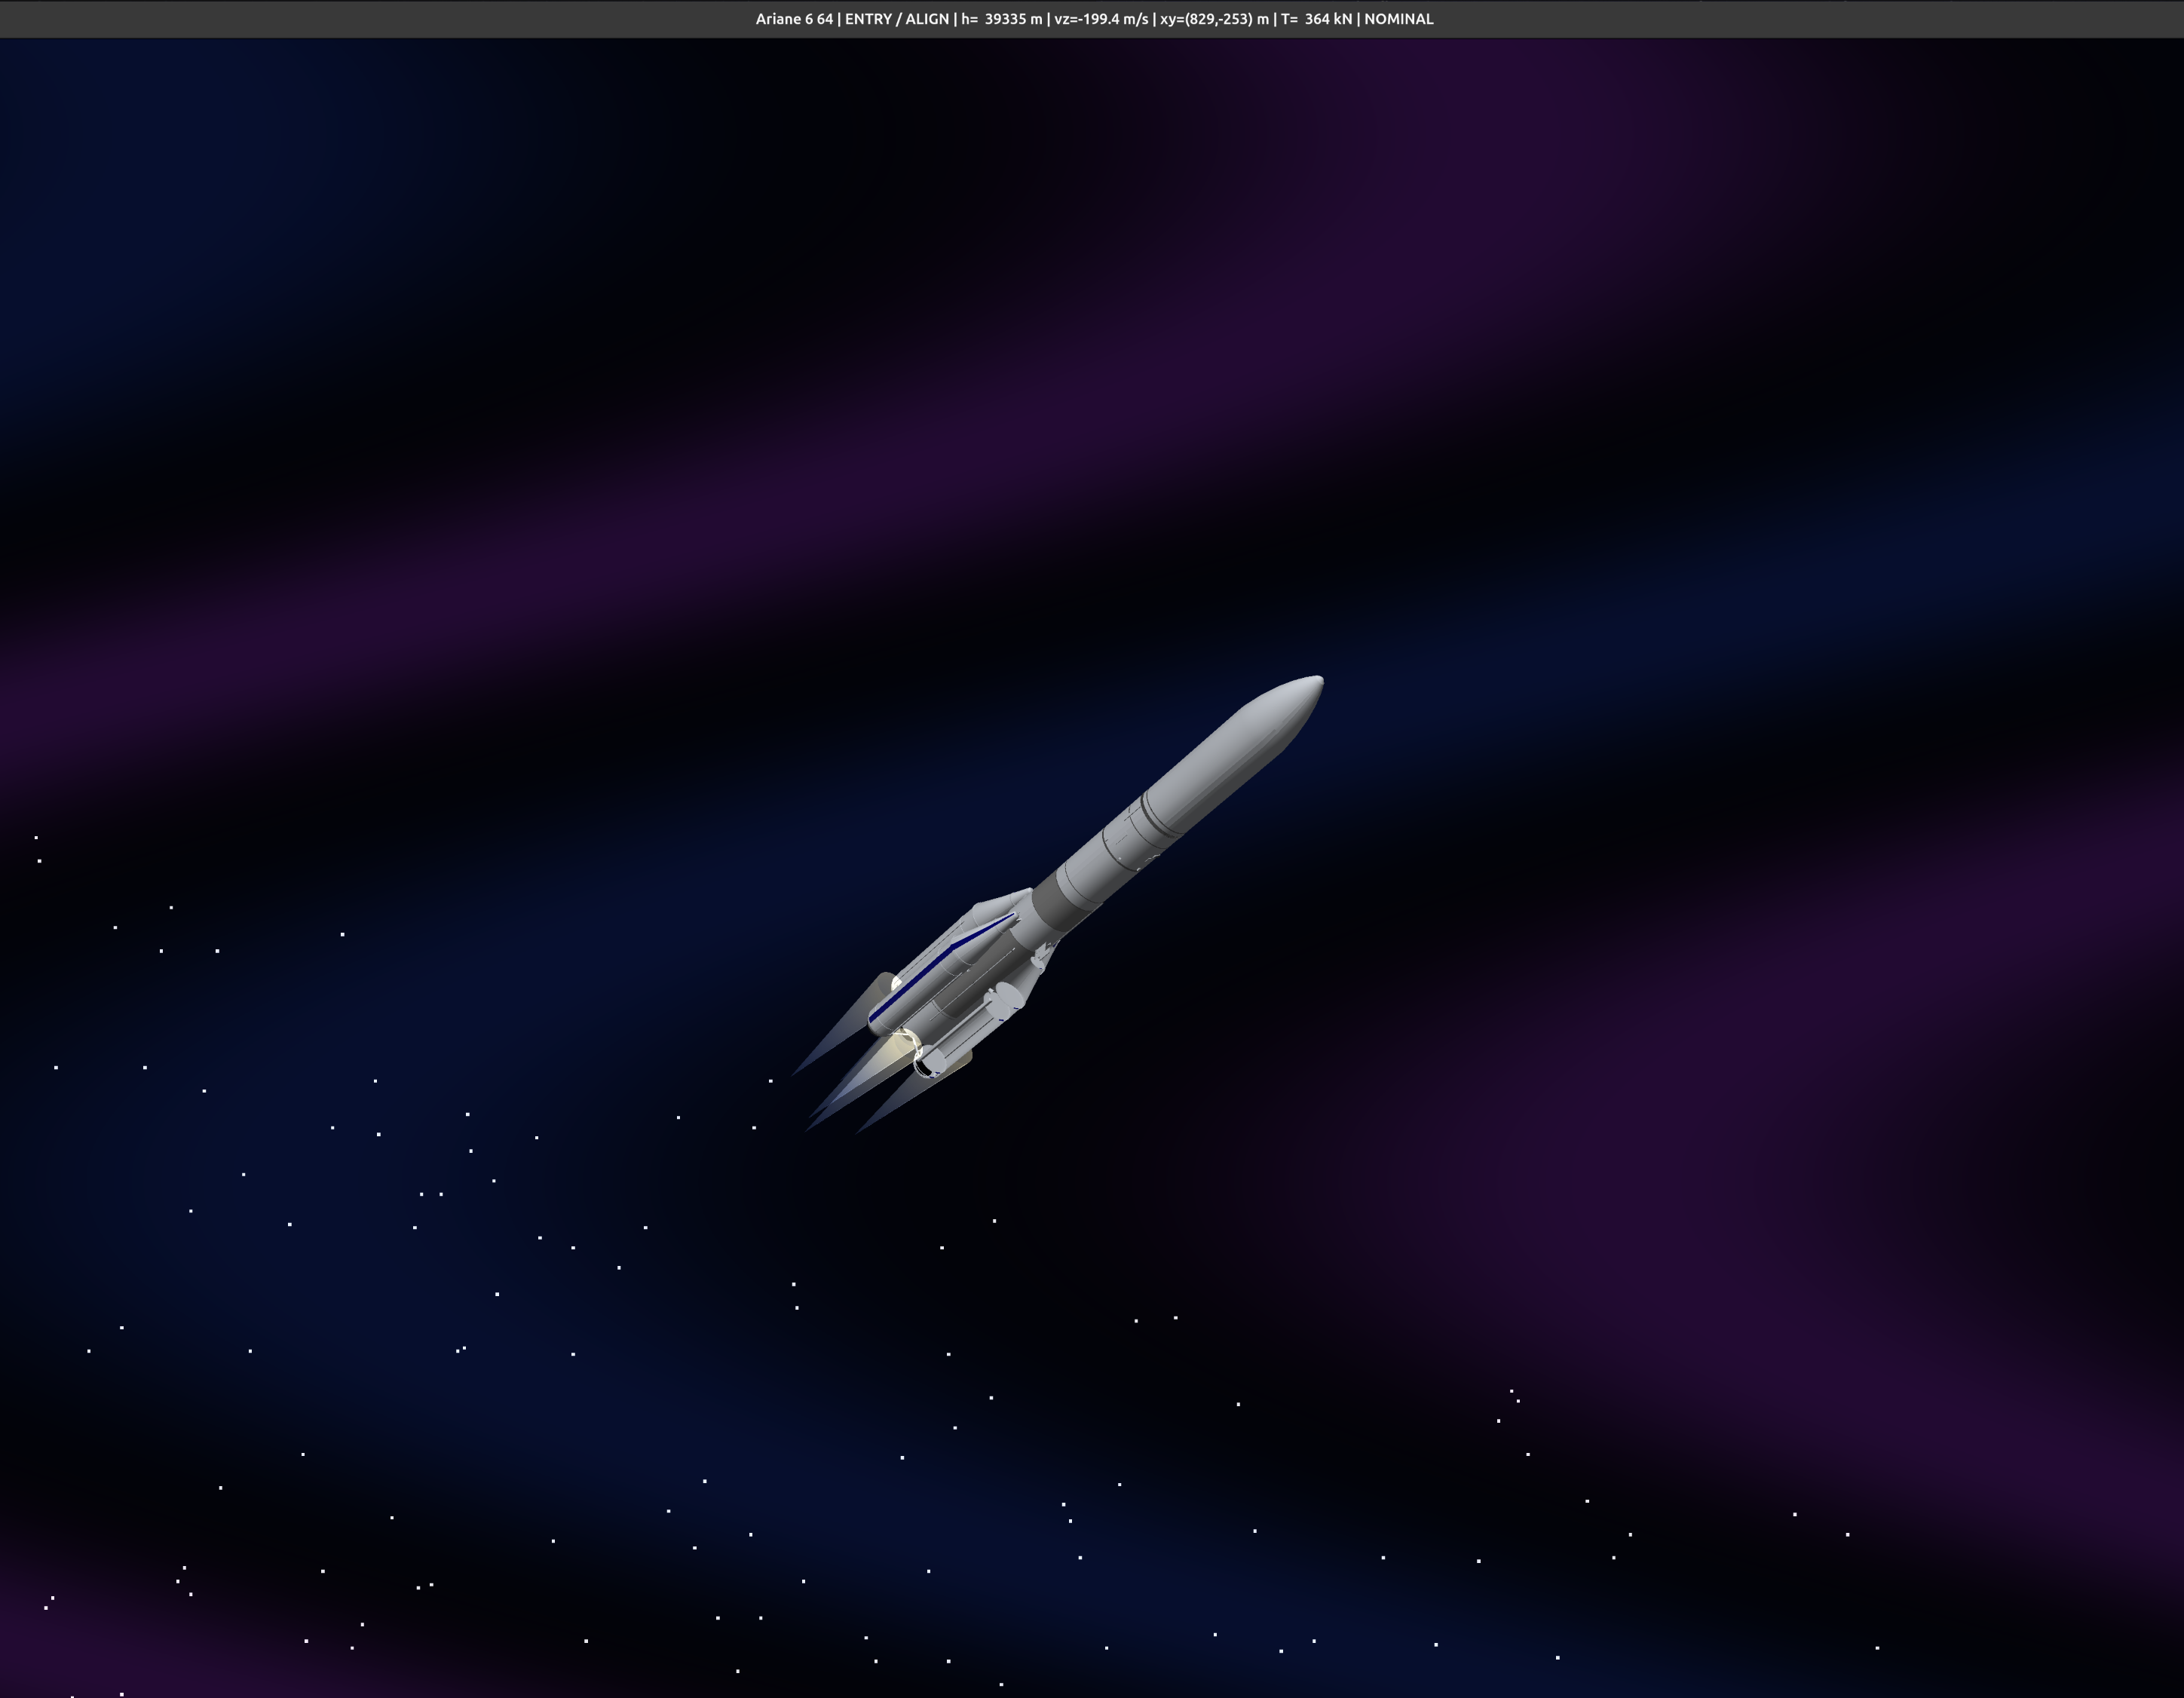
TECHNICAL PROJECT / Robust 6-DOF Guidance, Navigation and Control for Autonomous Powered Descent Under Wind, Navigation Uncertainty and Partial Actuator Degradation

The objective is to recover a six-degree-of-freedom vehicle from an initially descending, laterally displaced and deliberately tilted state, reject atmospheric wind and sensor uncertainty, command thrust and two-axis t…

Run simulation ↗

Find your next destination.

TAB TO NAVIGATE · ENTER TO OPEN · ESC TO CLOSE