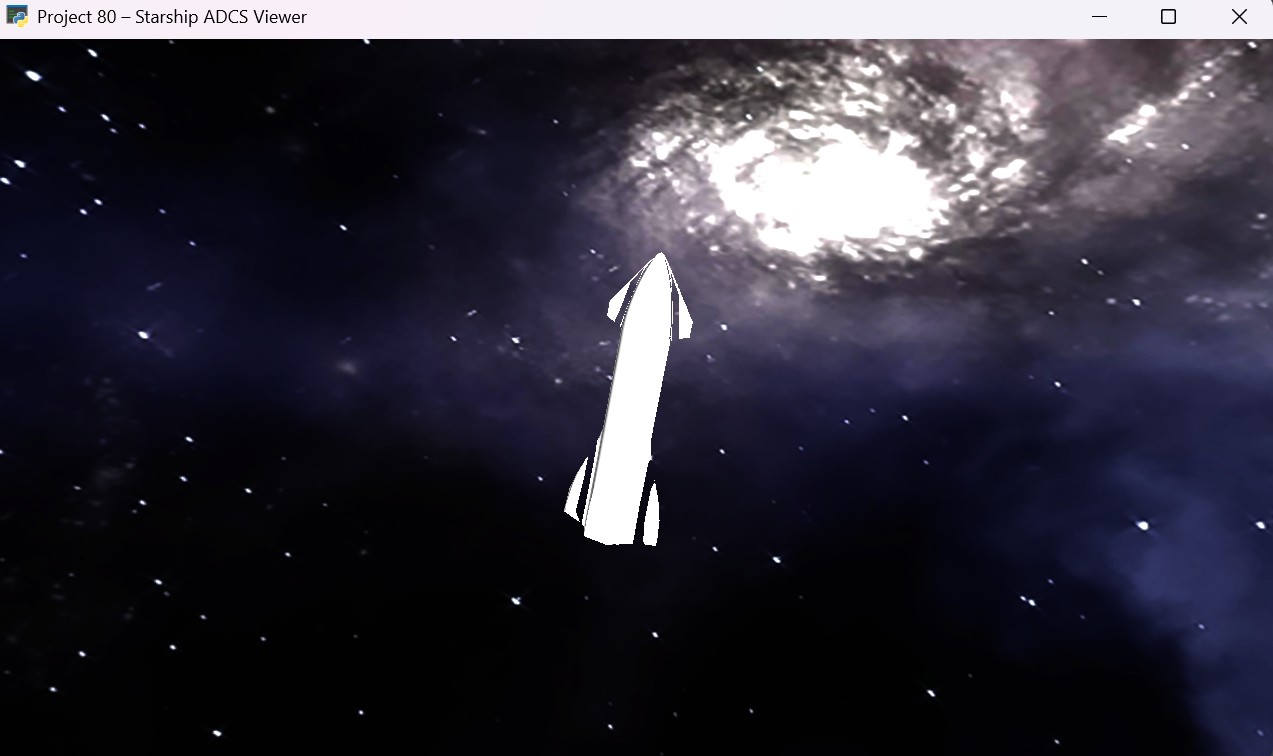
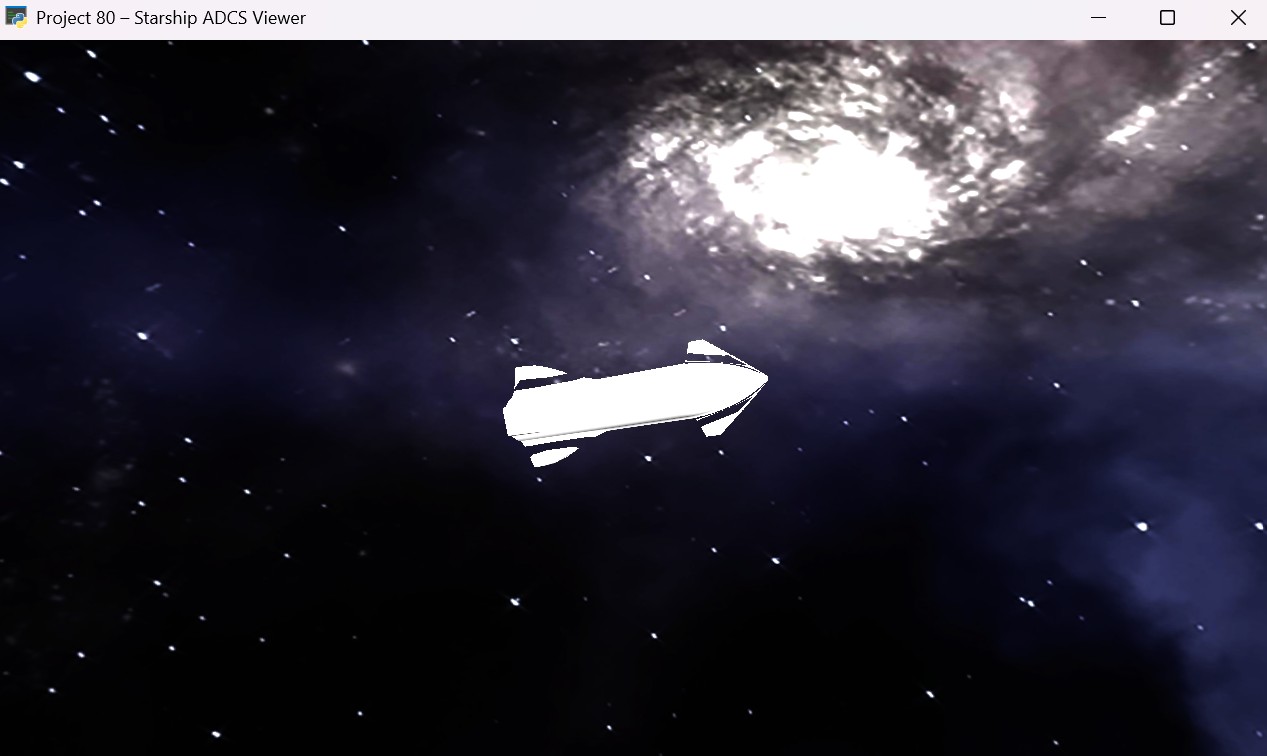
Maintain stable spacecraft orientation across all rotational axes while minimizing pointing error, oscillations, and control effort.
Approach
Developed a full-state feedback controller based on LQR optimization. The controller continuously computes optimal reaction torques to stabilize spacecraft attitude with high precision and robustness.
Outcome
Achieved accurate three-axis attitude stabilization with low steady-state error and smooth control behavior, demonstrating the applicability of optimal control methods to spacecraft ADCS design.
Tools
PythonNumPySciPyControl
Roadmap
ADCS System – Optimal LQR Control for 3-Axis Stabilization
An optimal attitude control system that achieves precise three-axis spacecraft stabilization using Linear Quadratic Regulator (LQR) control.
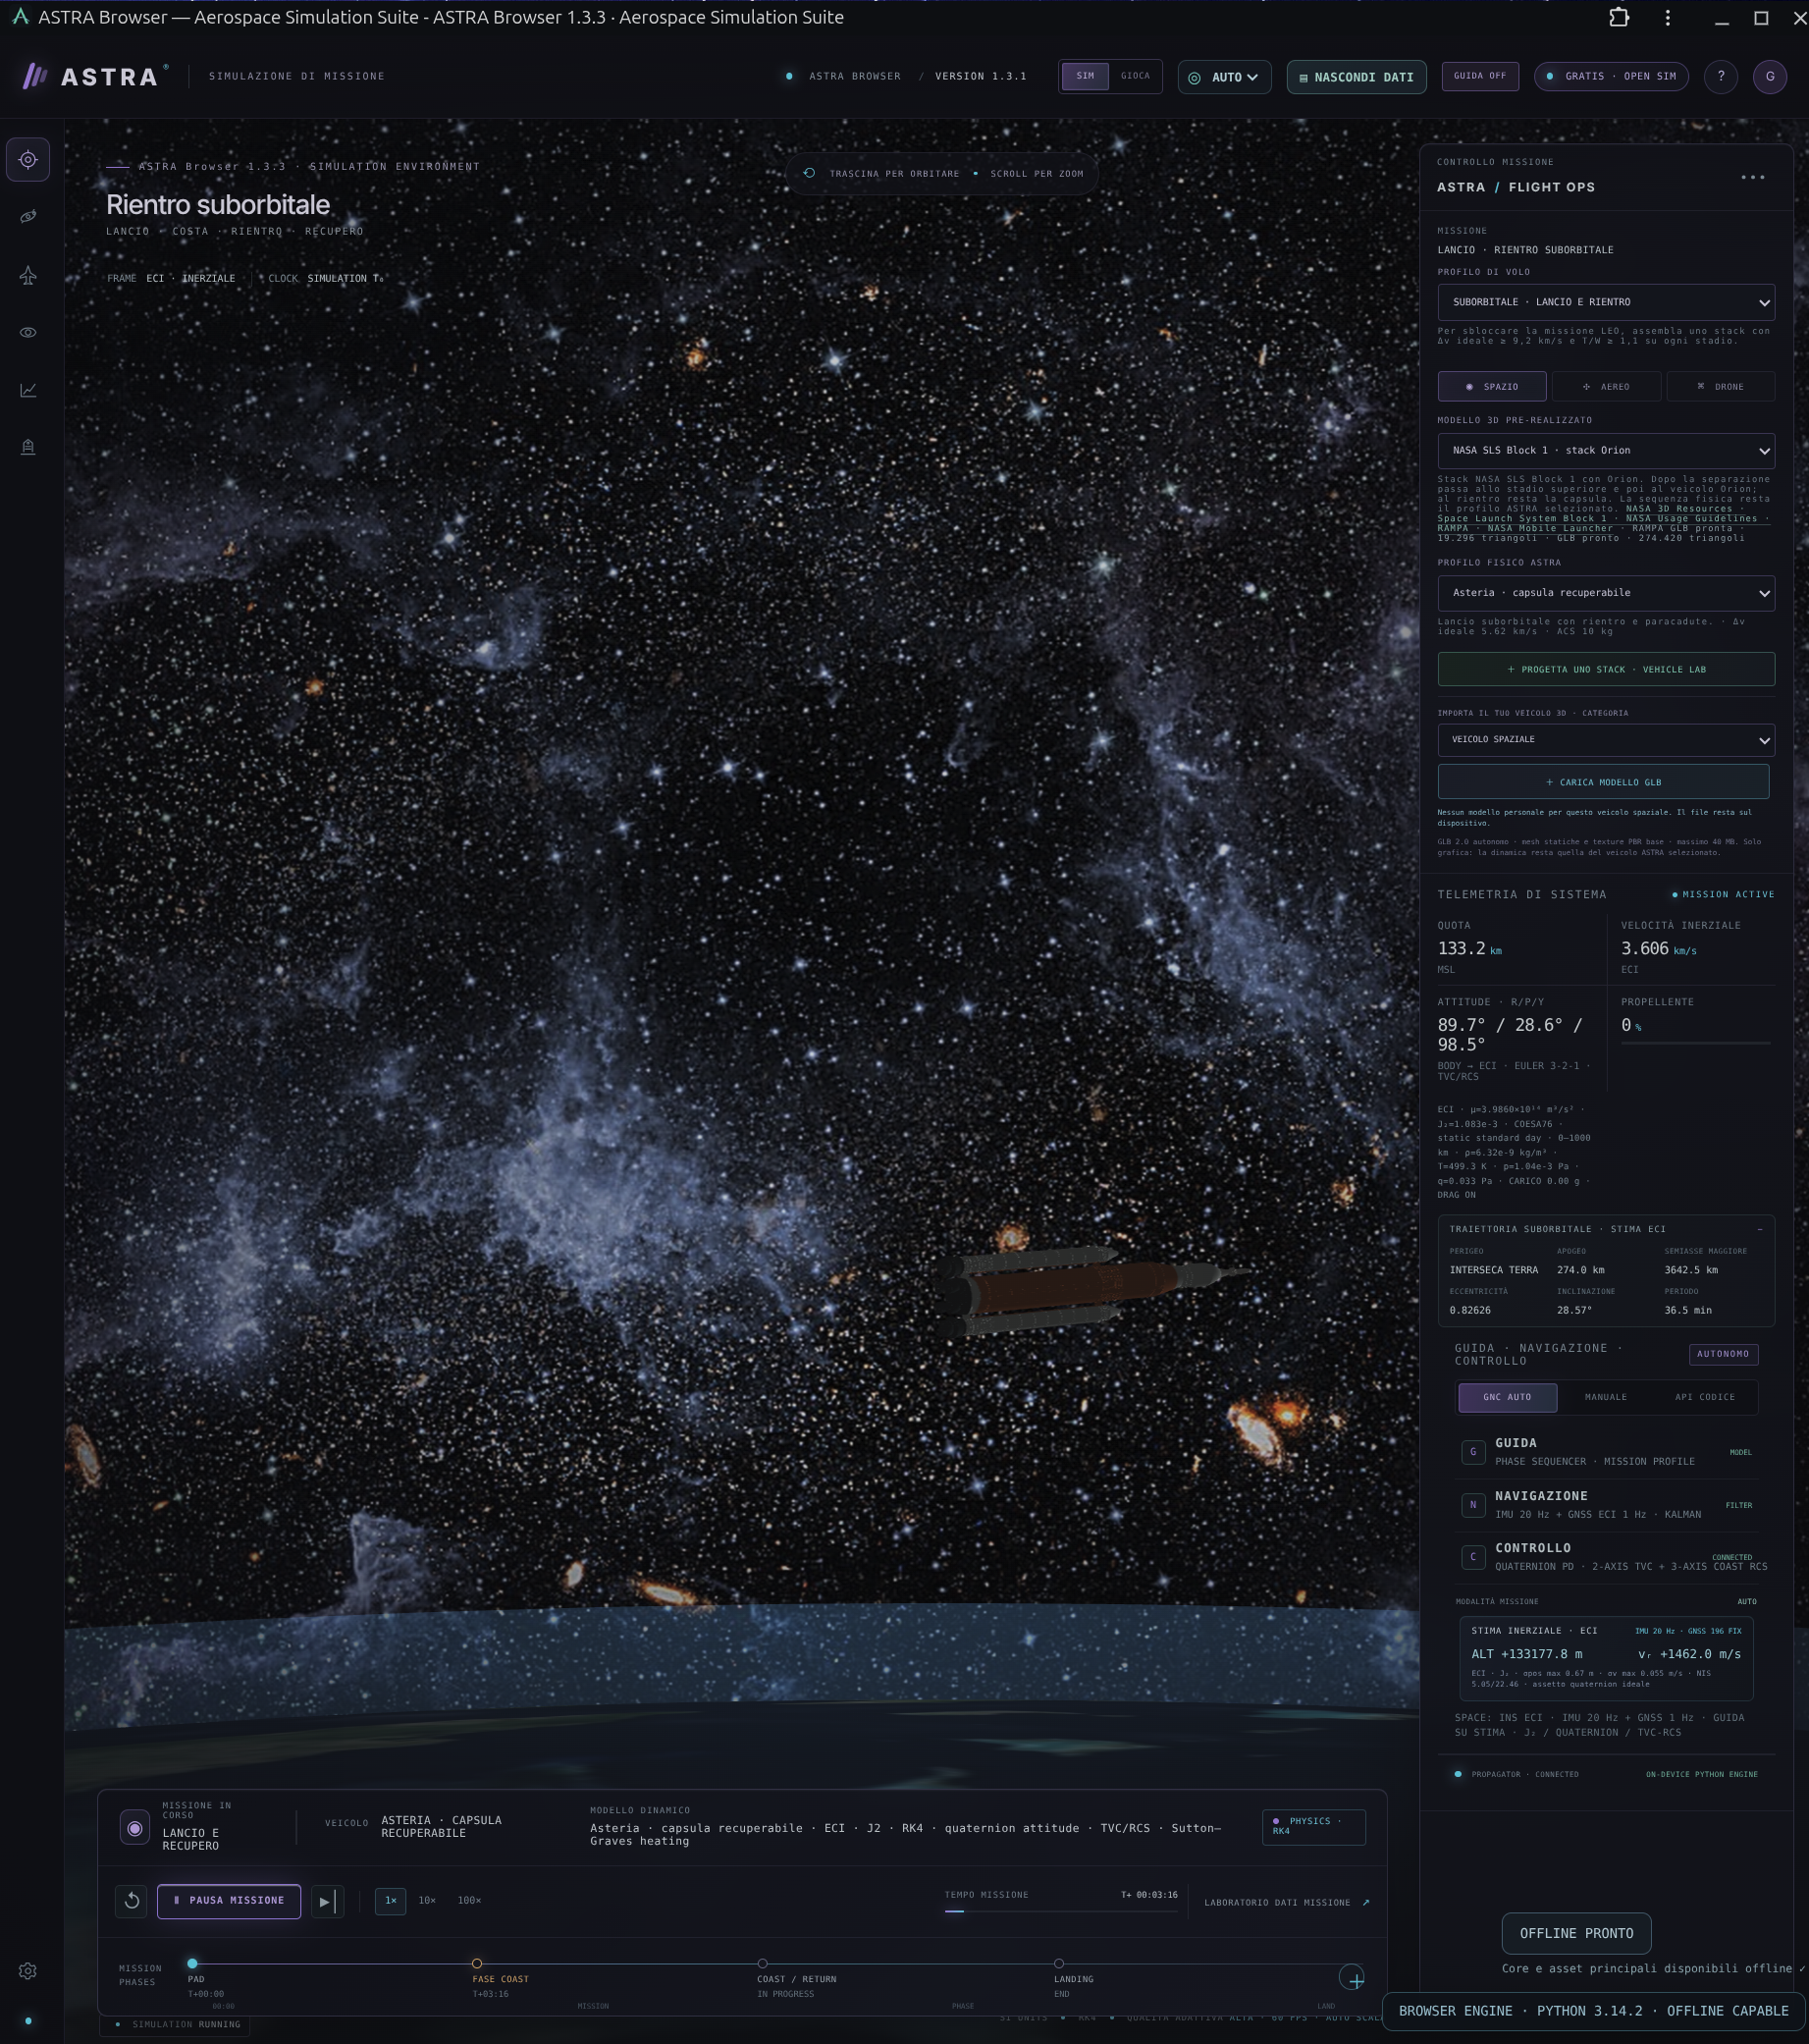
A high-fidelity aerospace simulation environment designed to visualize orbital mechanics, spacecraft dynamics, and mission operations in real time. The simulator serves as both an engineering tool and an educational pla…
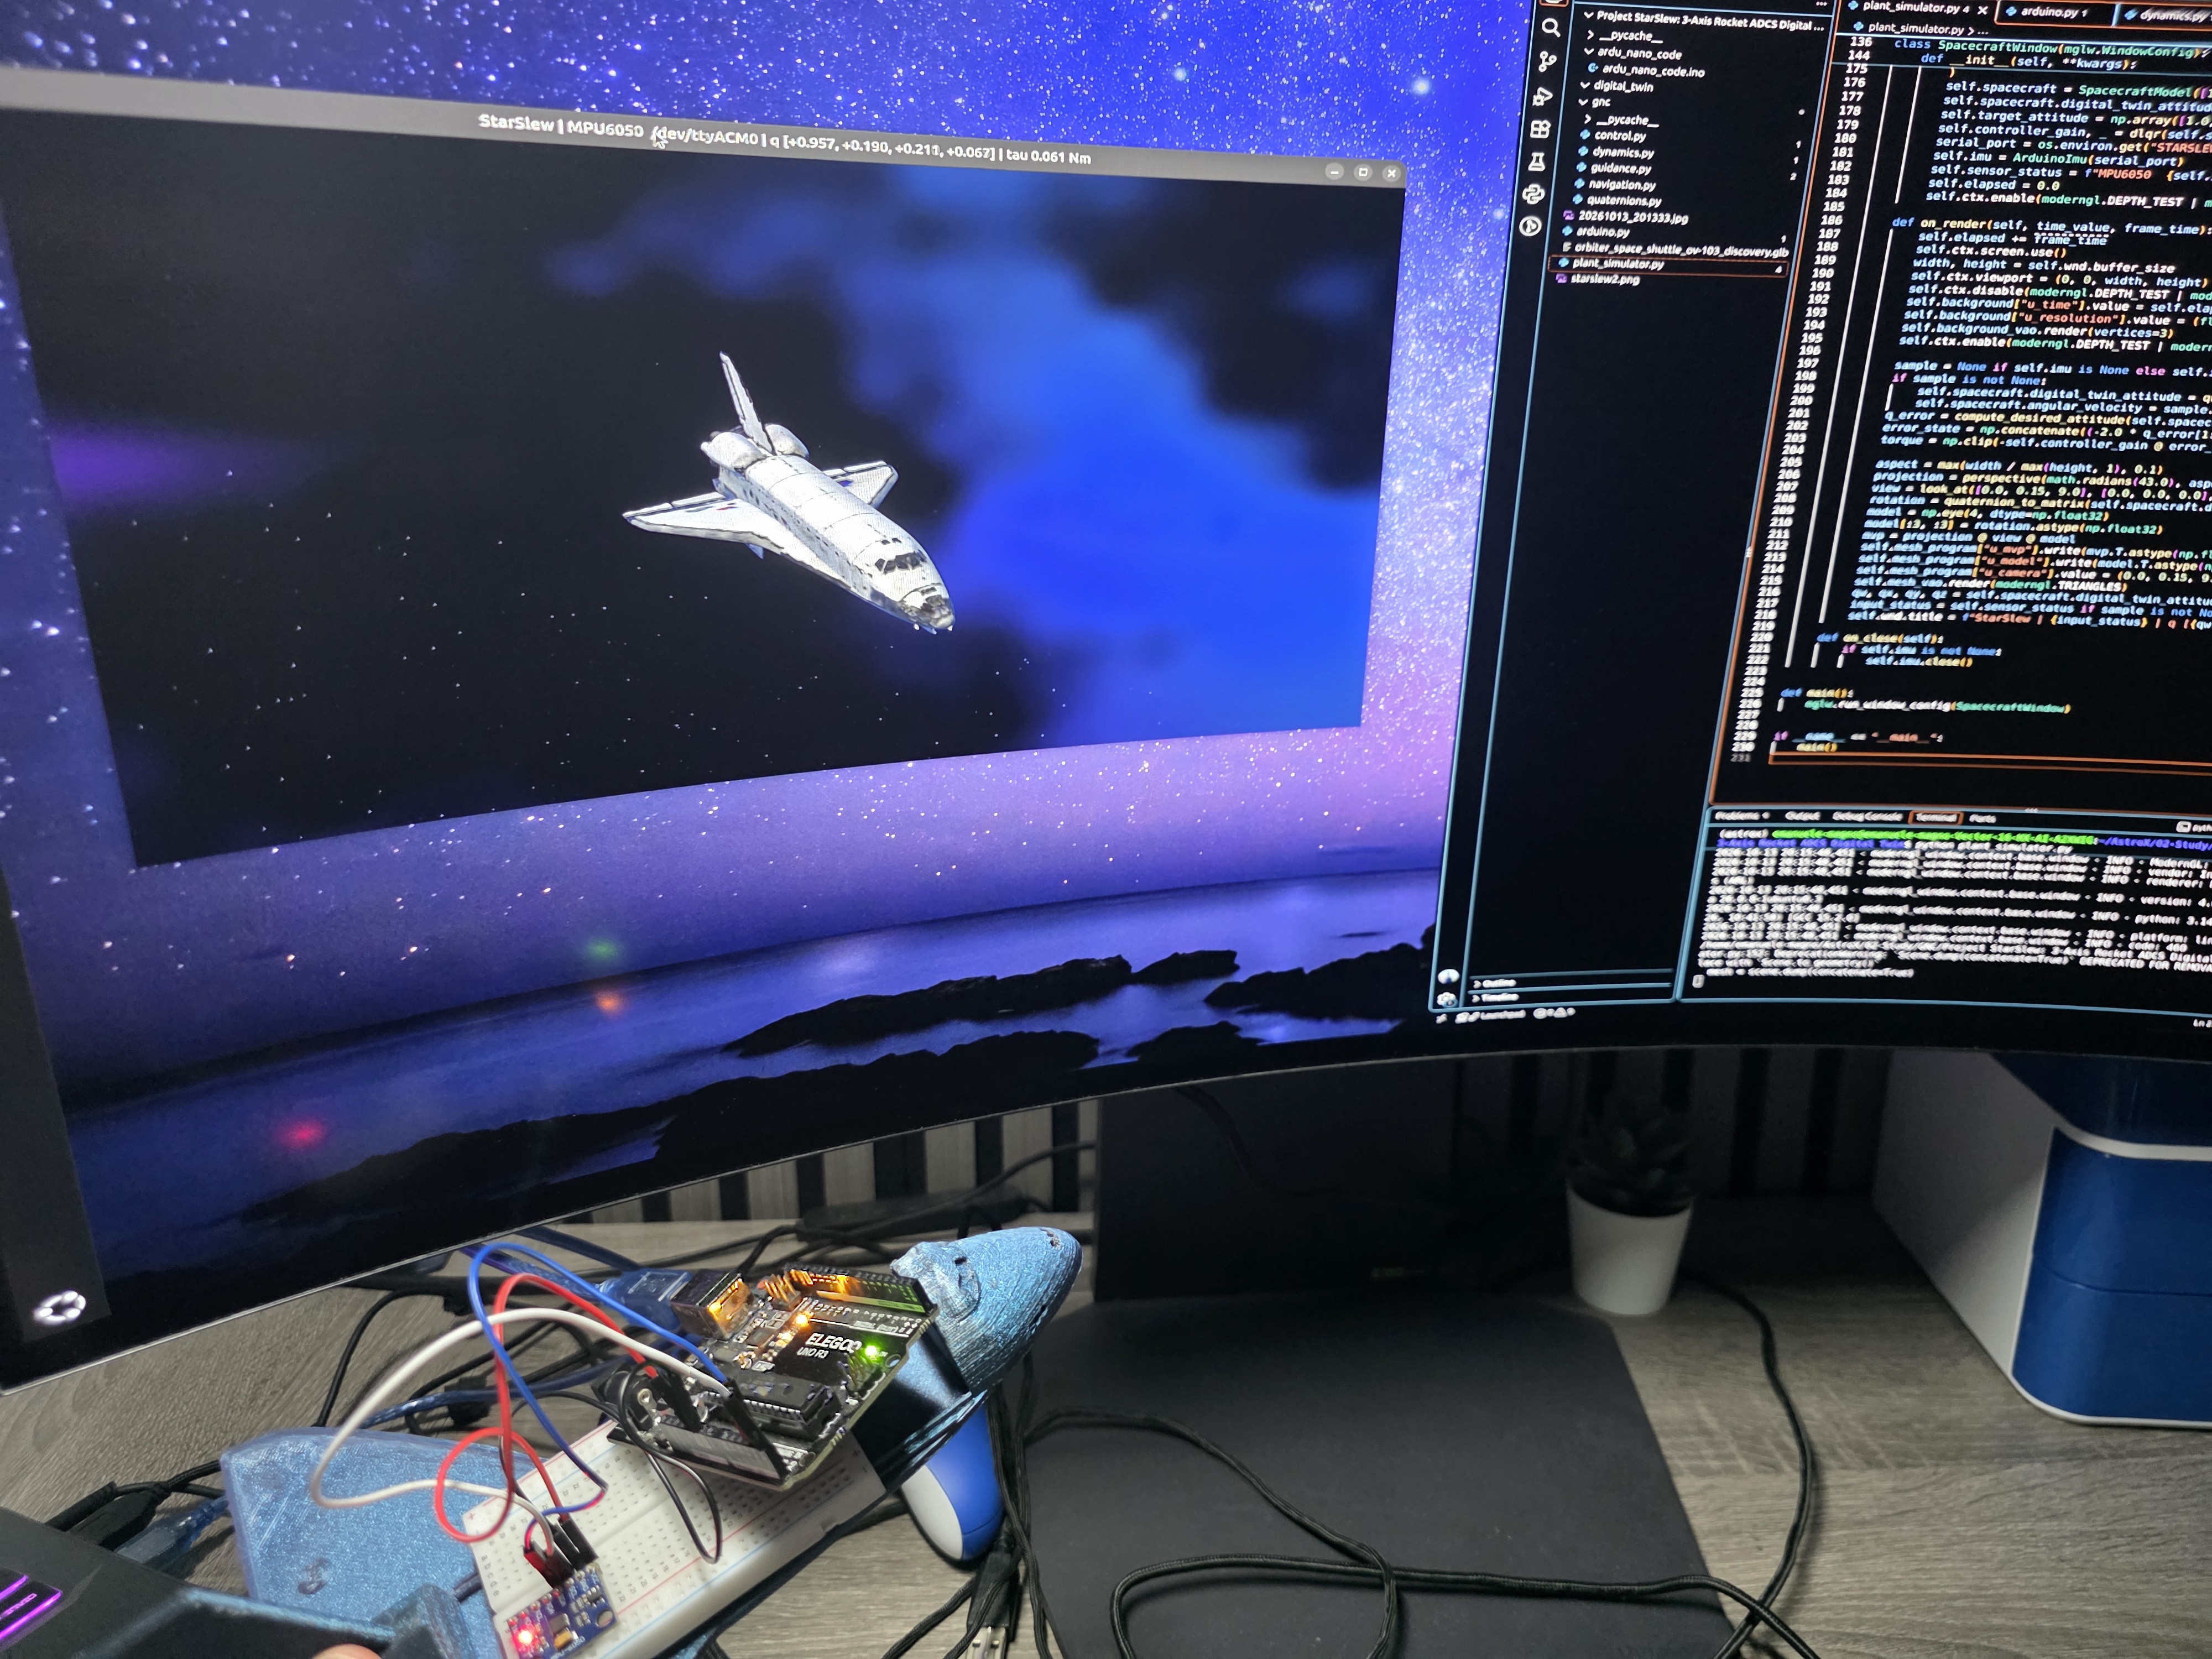
TECHNICAL PROJECT / Project StarSlew 3-Axis Rocket ADCS Digital Twin
StarSlew is a 3-axis attitude-control digital twin that connects an Arduino Nano and MPU6050 to a quaternion-based GNC software stack and a 3D spacecraft visualization.
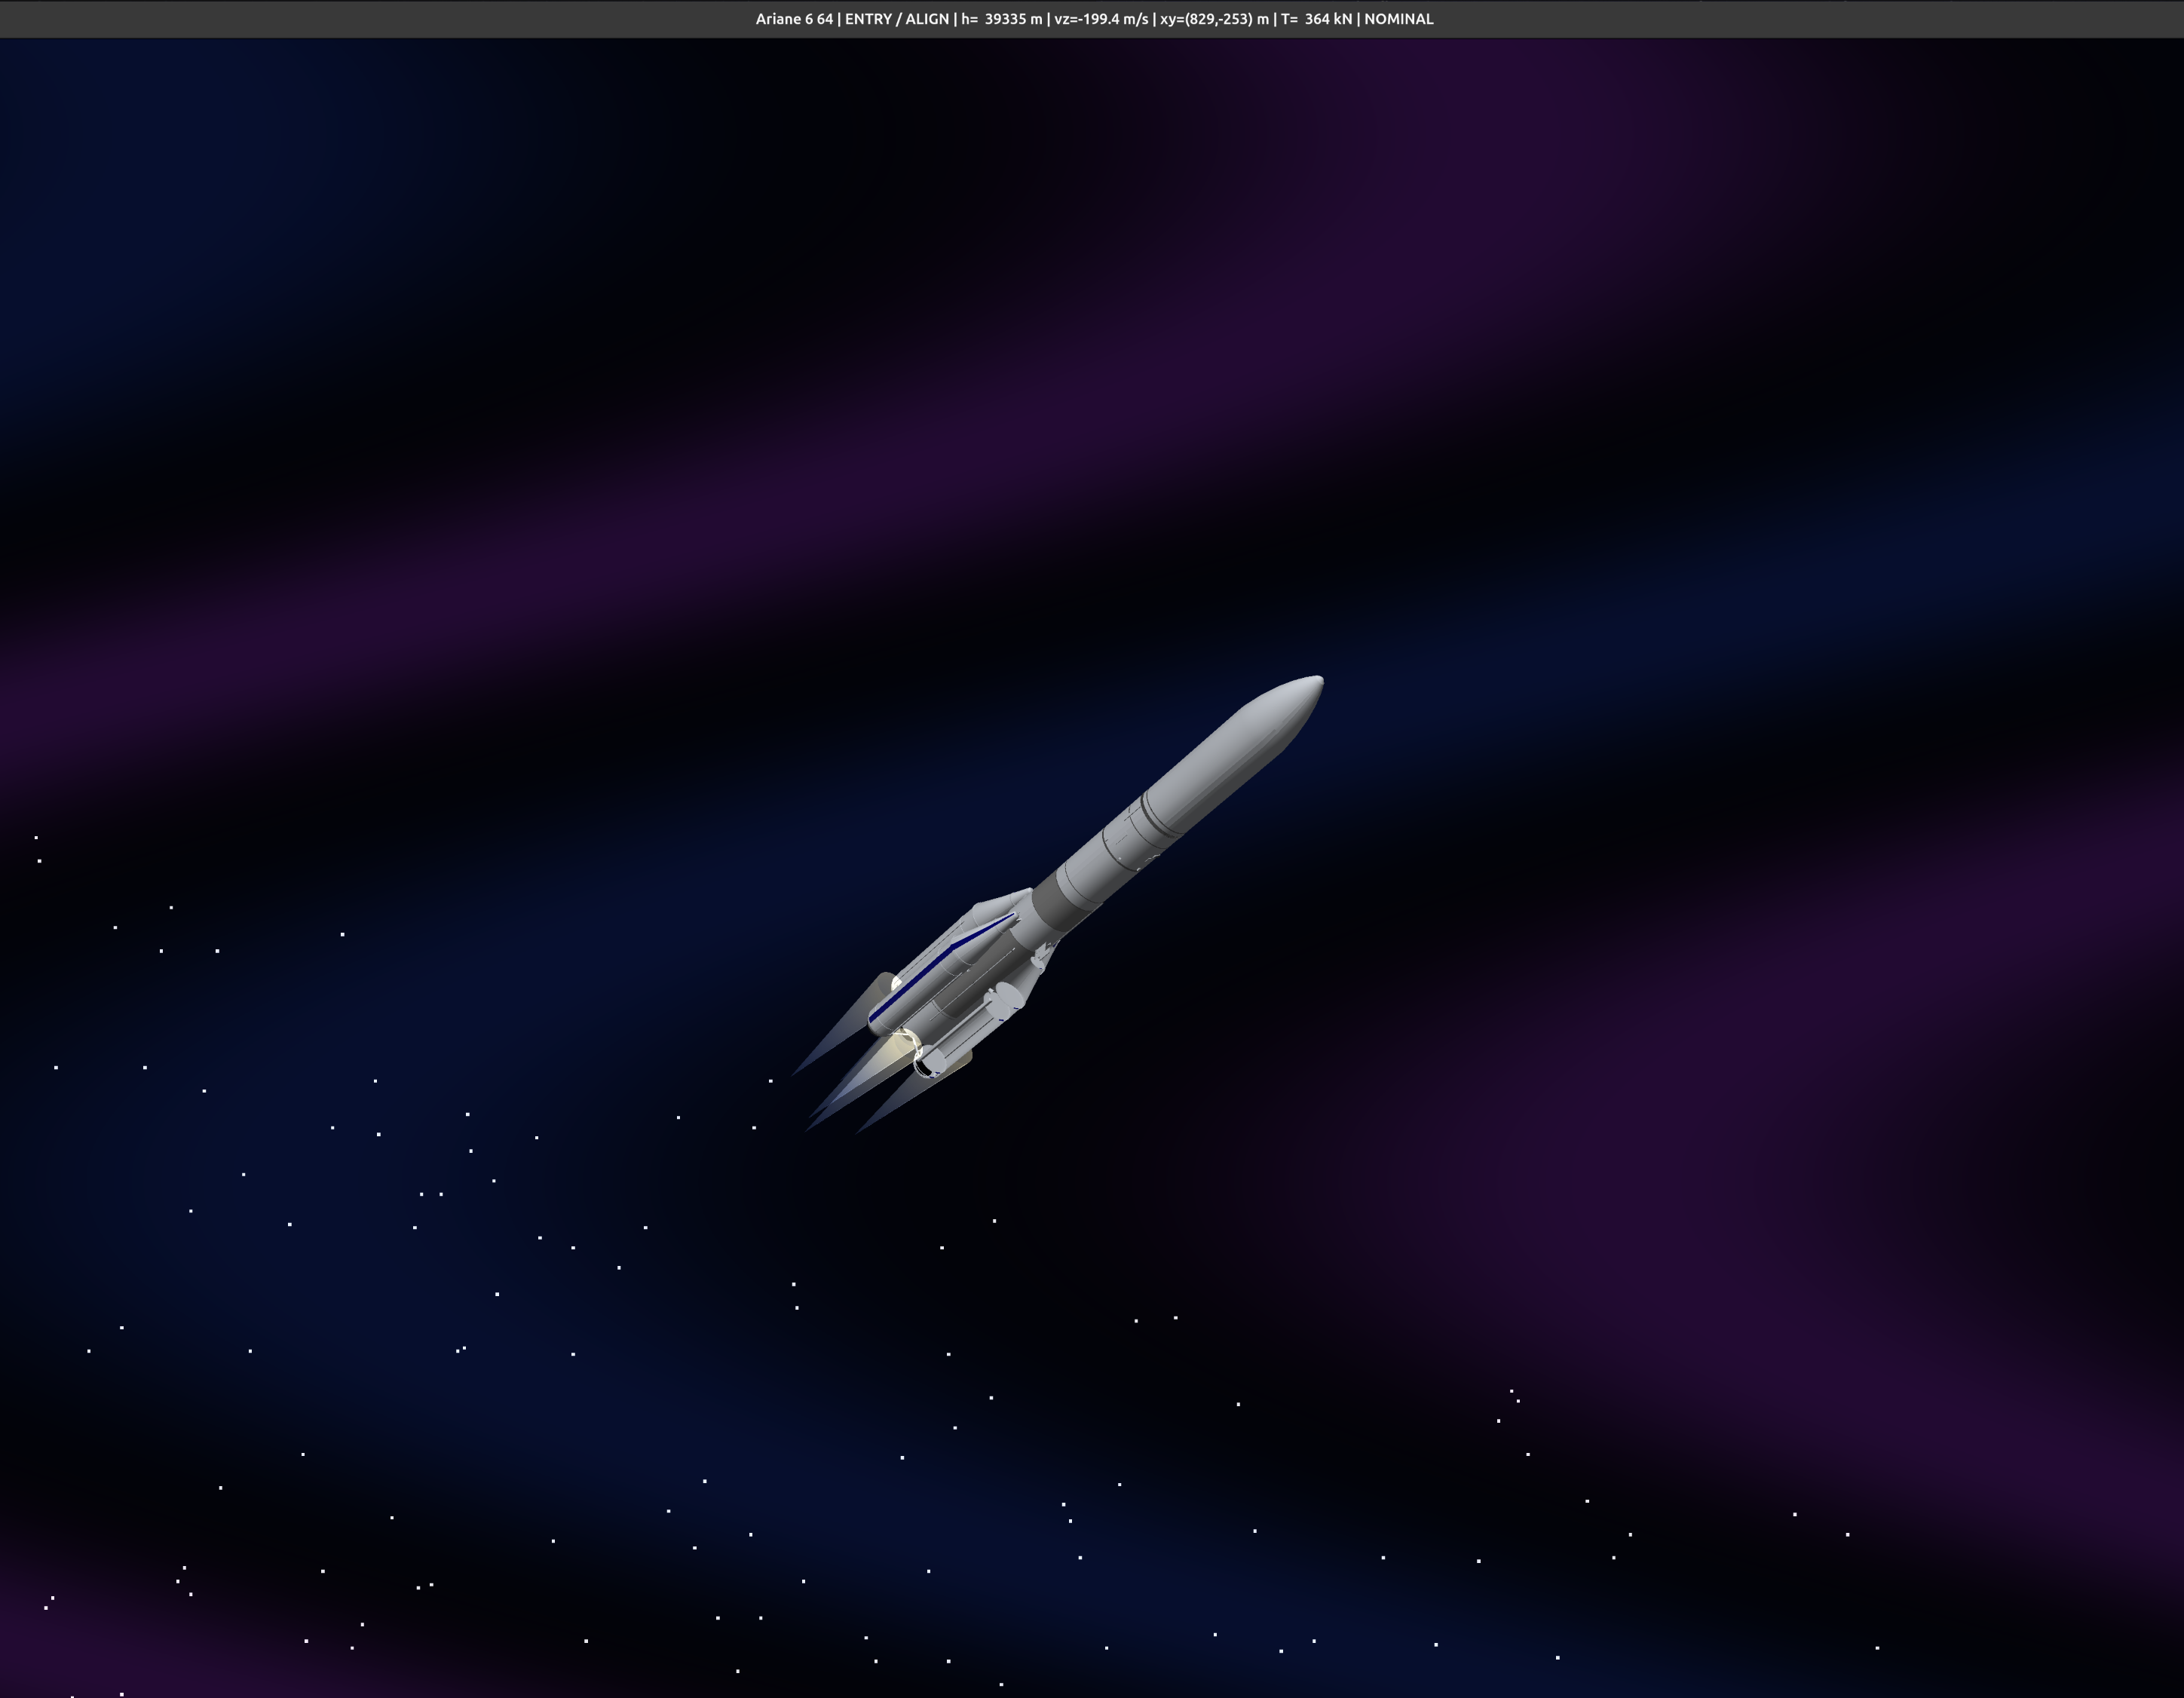
TECHNICAL PROJECT / Robust 6-DOF Guidance, Navigation and Control for Autonomous Powered Descent Under Wind, Navigation Uncertainty and Partial Actuator Degradation
The objective is to recover a six-degree-of-freedom vehicle from an initially descending, laterally displaced and
deliberately tilted state, reject atmospheric wind and sensor uncertainty, command thrust and two-axis t…