SOLSTICE · HORIZON BA9B
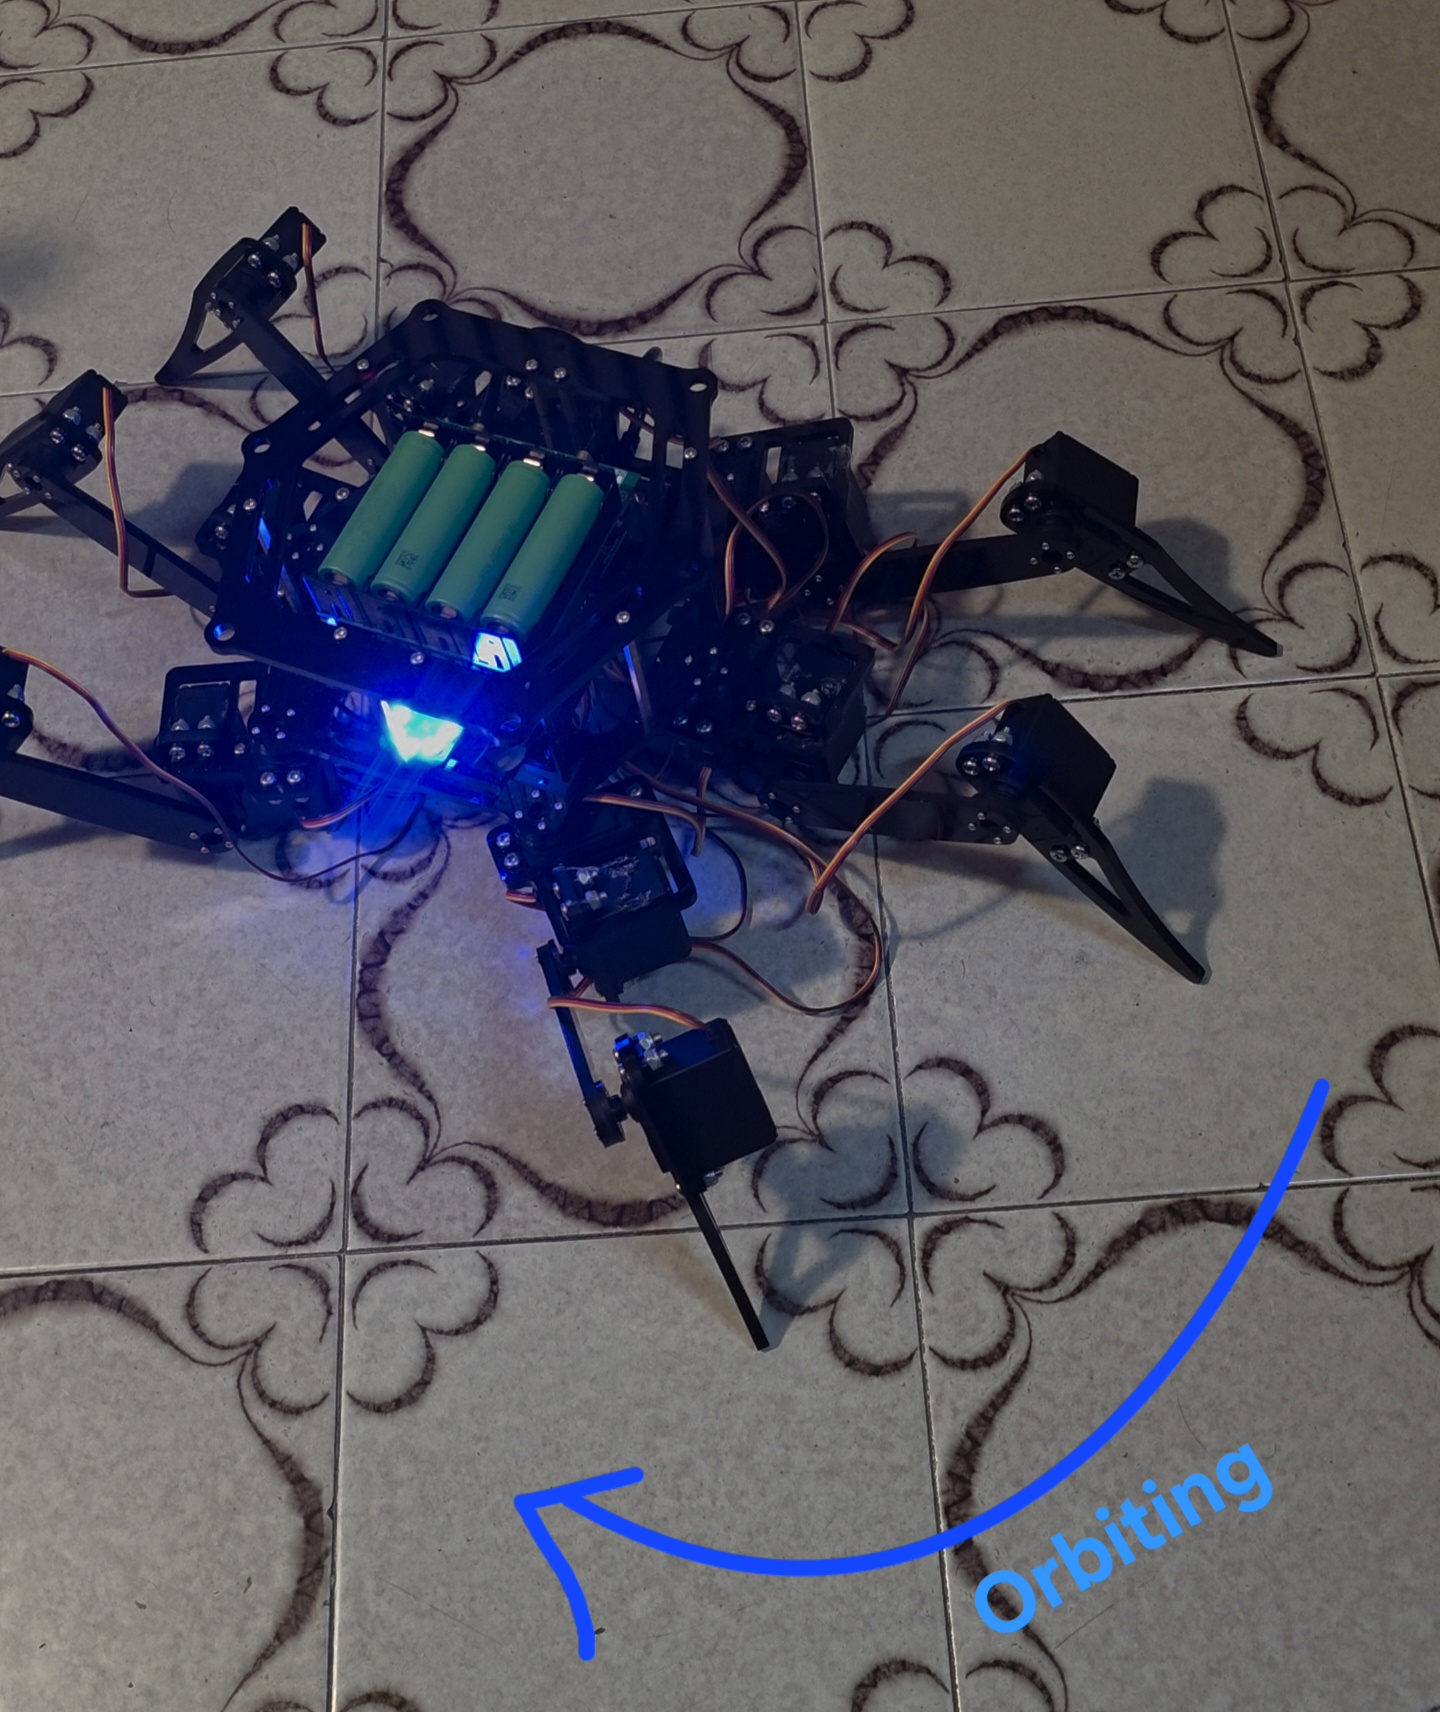
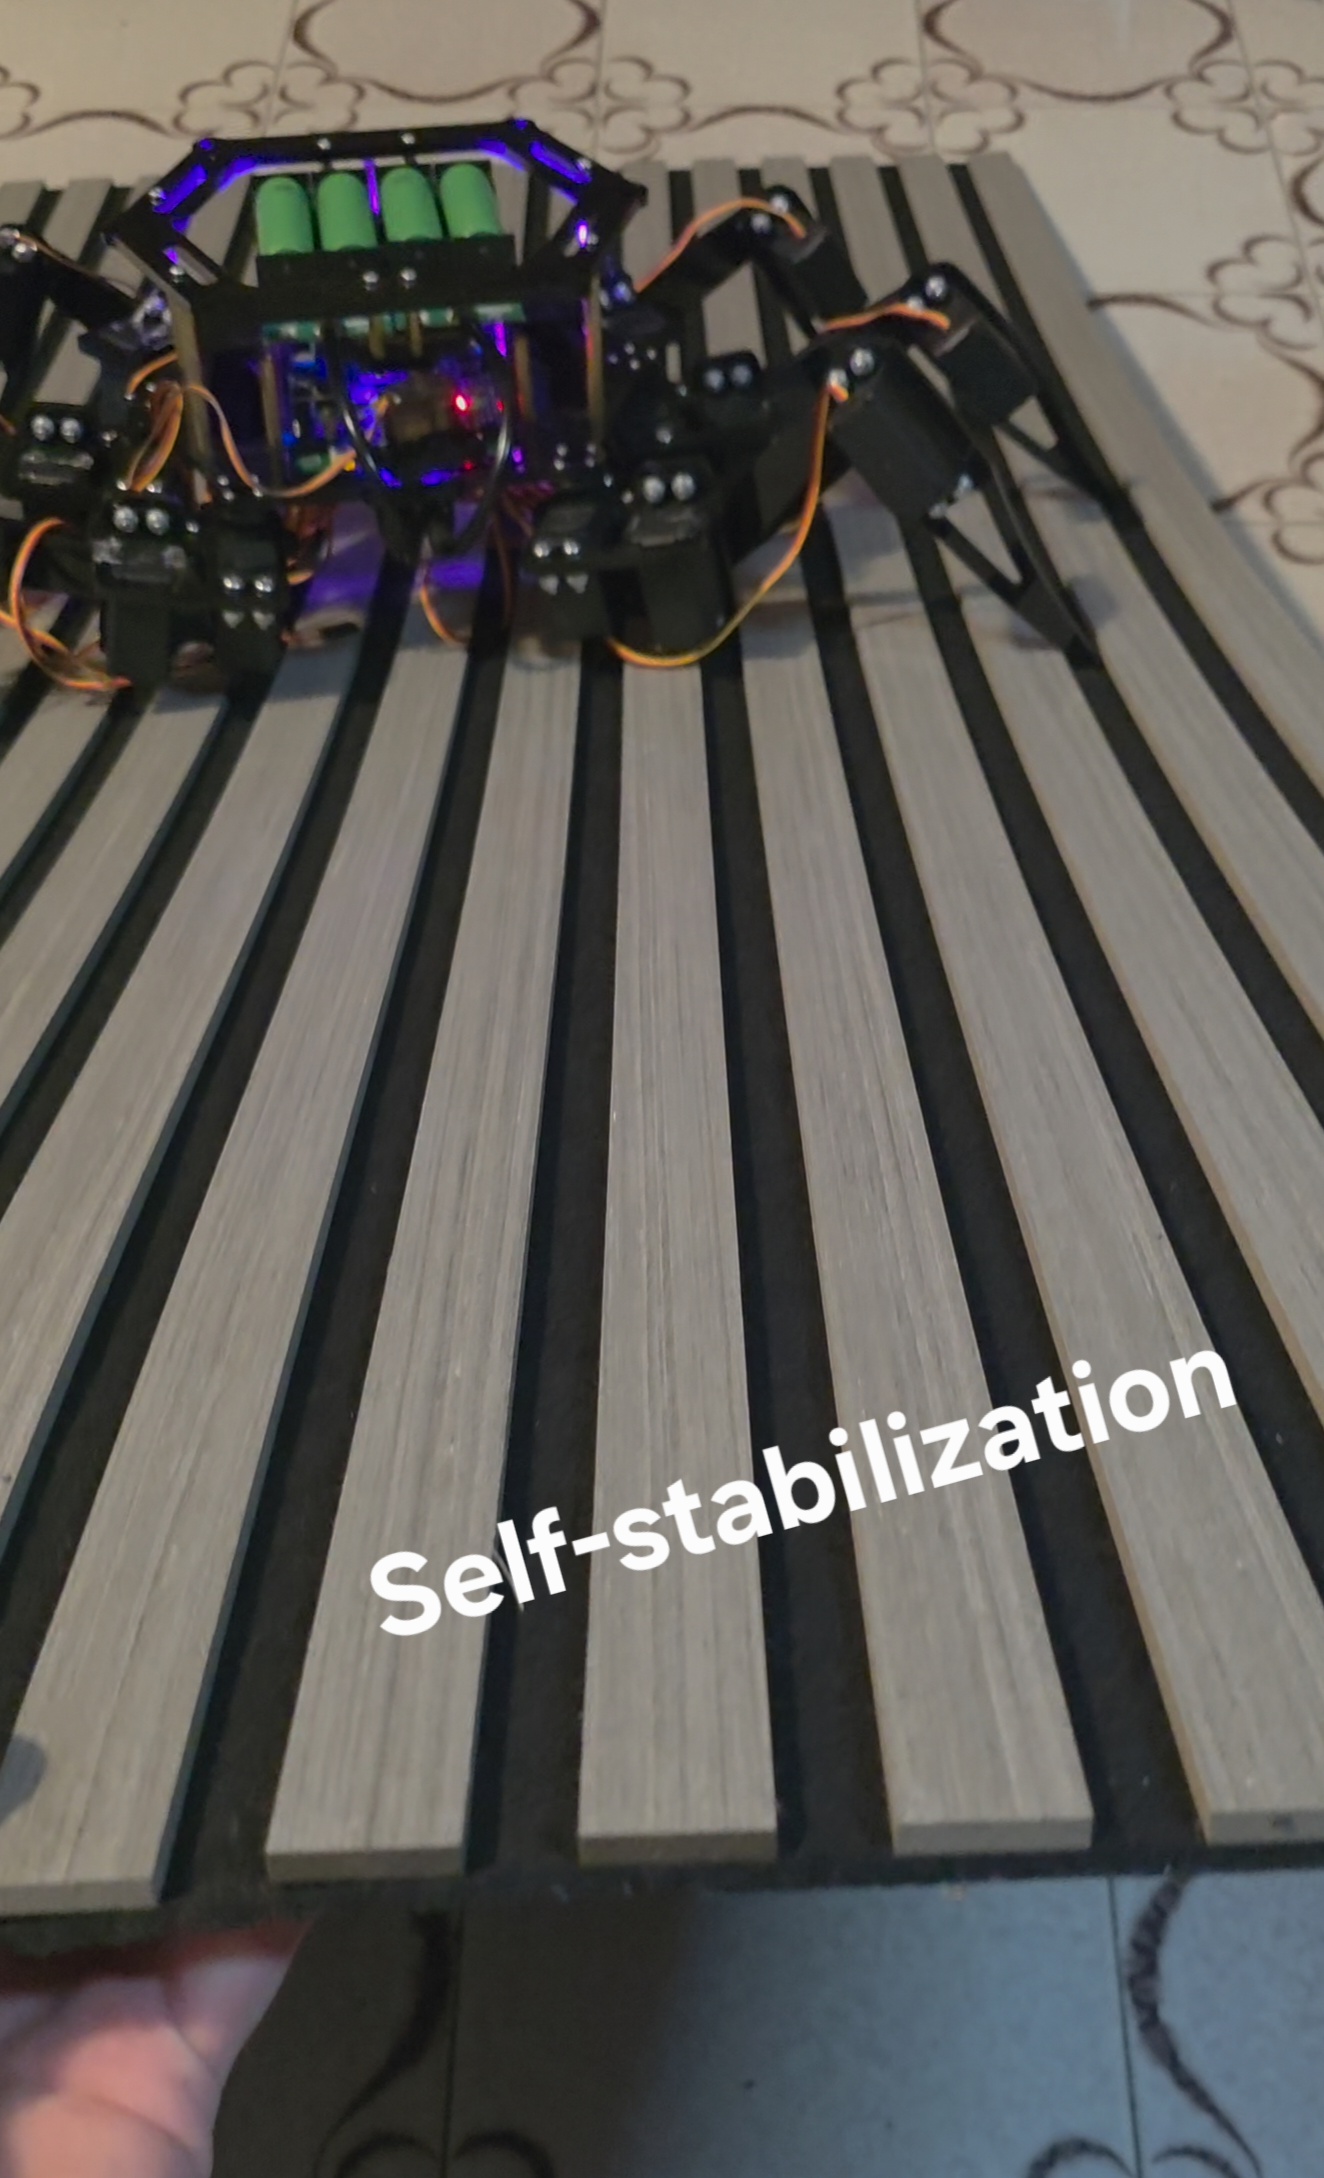
A Raspberry Pi 4-controlled Freenove FNK0052 hexapod connected to a private web portfolio. The platform combines supervised locomotion, live telemetry, an experimental custom GNC controller, Astro Tutor study tools, and Astro Codex repository assistance. The operator stays in command of every physical movement.
Challenge
Build a useful bridge between a real six-legged robot, aerospace engineering study and software
development while keeping the robot reachable only over a private network. The system also needed to
expose sensor and controller state clearly, so that GNC experiments could be inspected rather than
hidden behind an “AI autopilot” claim.
Approach
Use a Raspberry Pi API as the robot-side boundary; connect the Freenove motion server locally; read
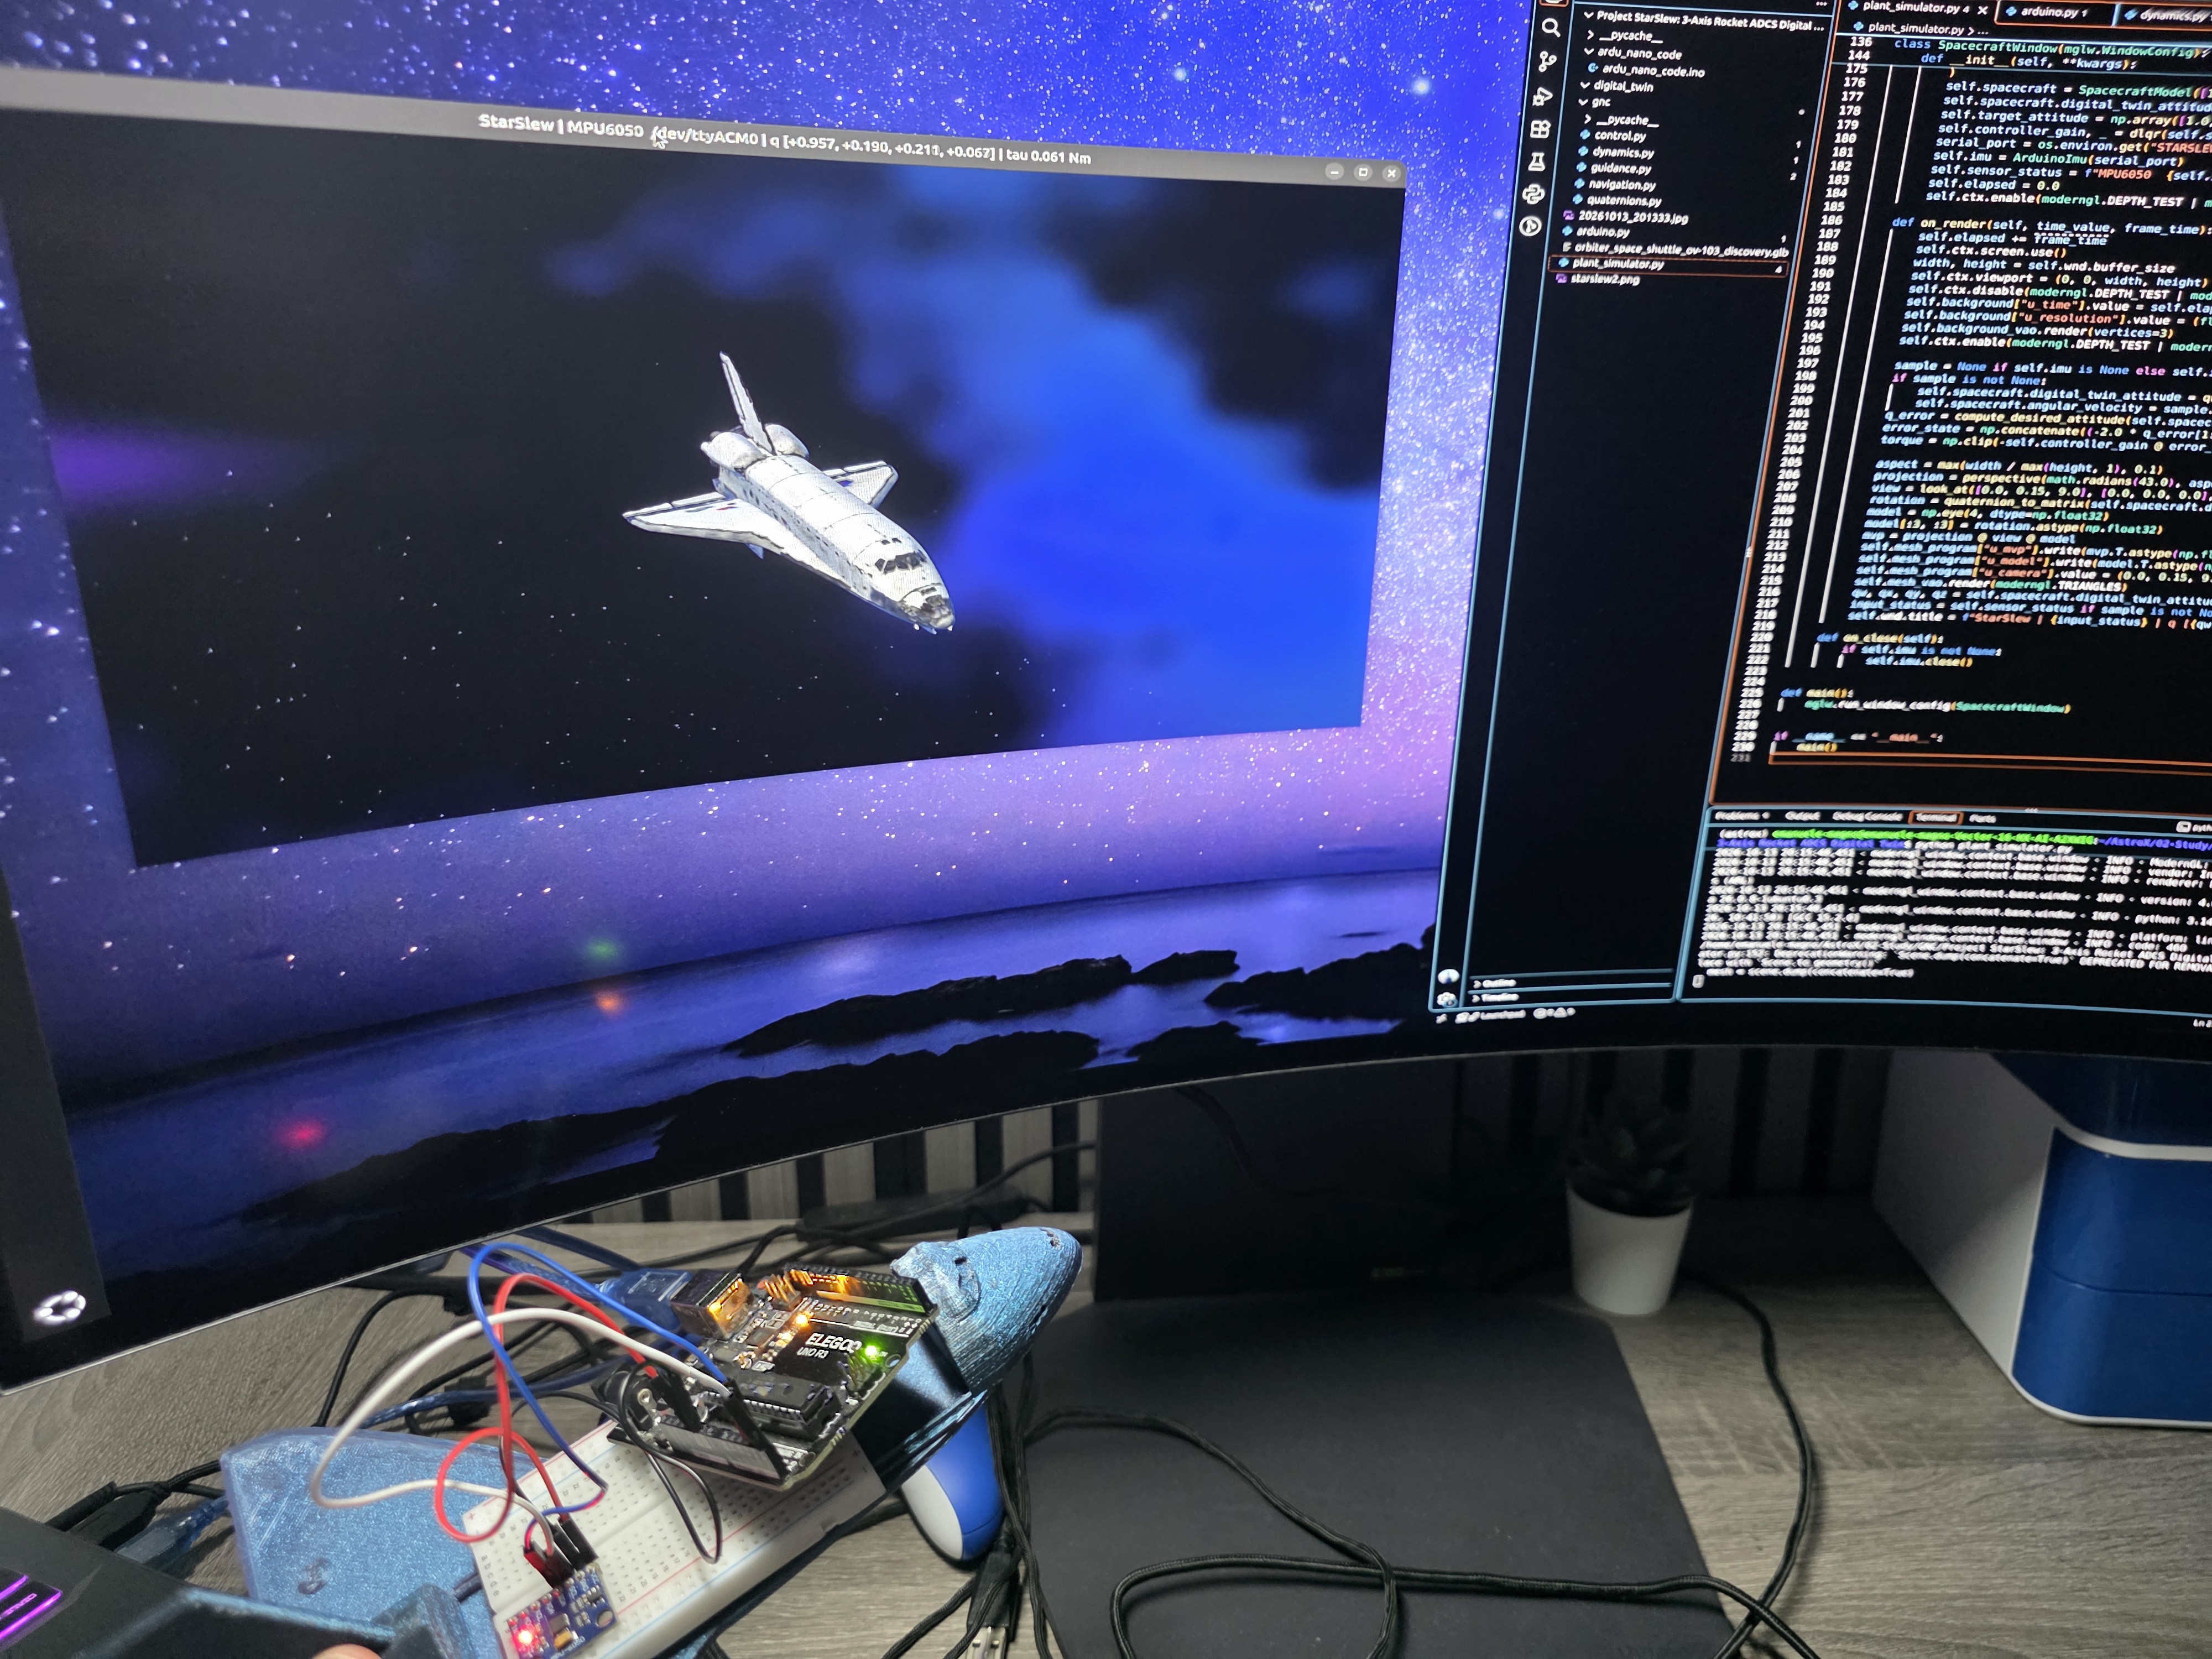
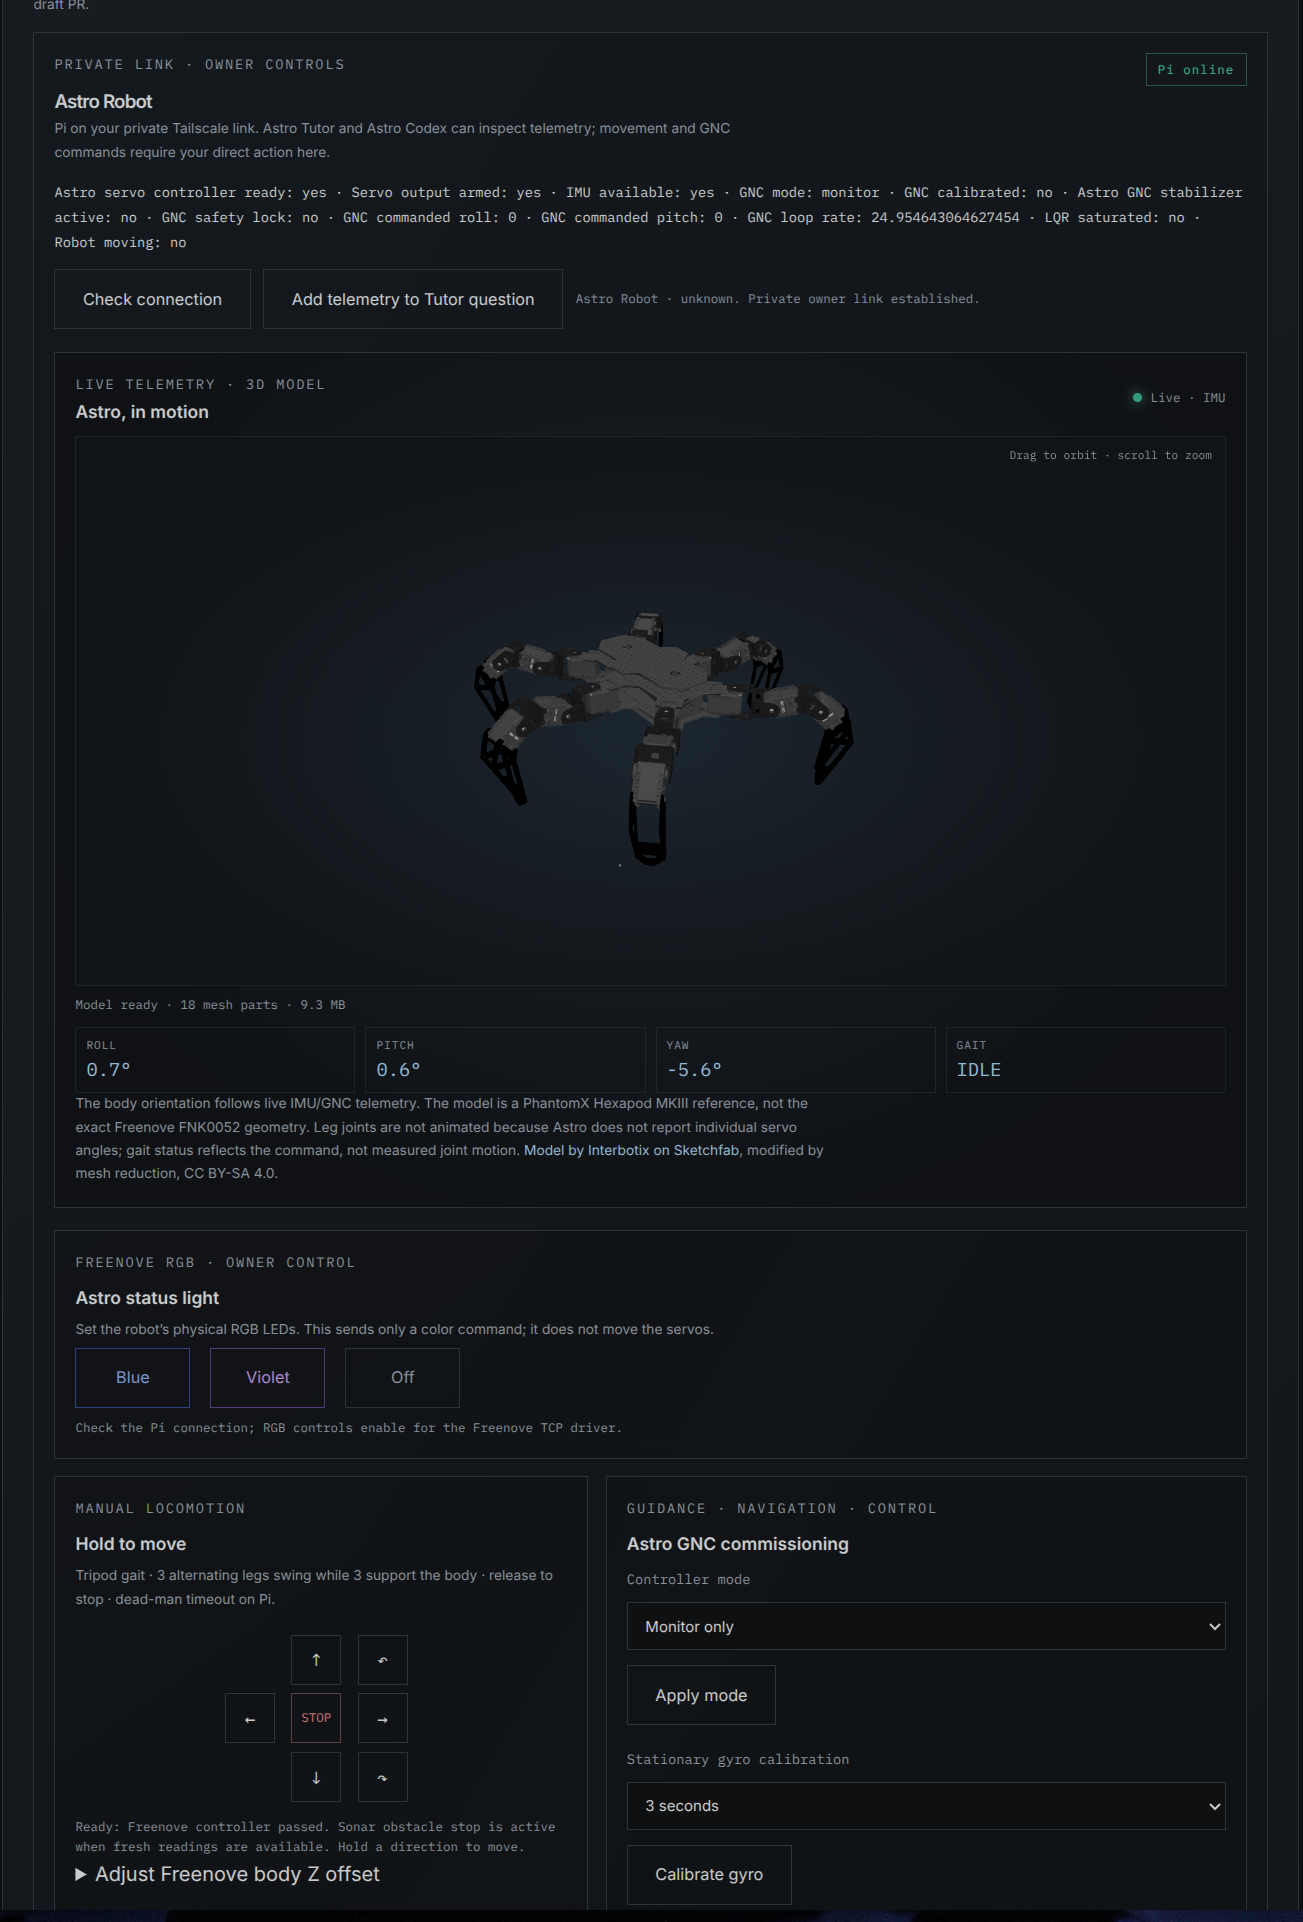
MPU6050 telemetry for Astro’s own attitude estimator; process attitude through a
multiplicative/error-state EKF, rate-limited roll/pitch guidance and discrete LQR; send bounded
body-attitude requests through Freenove kinematics. A private Django bridge exposes only
owner-authorized telemetry and fixed, bounded actions. Tutor adds reviewed telemetry to learning
questions; Codex inspects authorized GitHub text and requires a separate confirmation for a draft PR.
Outcome
Owner-run tests have demonstrated servo movement, manual forward gait and yaw rotation, private Pi
connectivity, IMU telemetry, gyro calibration, GNC mode changes and attitude-command output.
Reported GNC telemetry reached approximately 25 Hz. Physical stabilization is still experimental: tremor
on a level surface and occasional LQR saturation remain unresolved. The 3D view uses a reference
hexapod model, not an exact FNK0052 digital twin; the project makes no claim of autonomous slope
walking or flight readiness.