ZENITH · PULSE F8EB
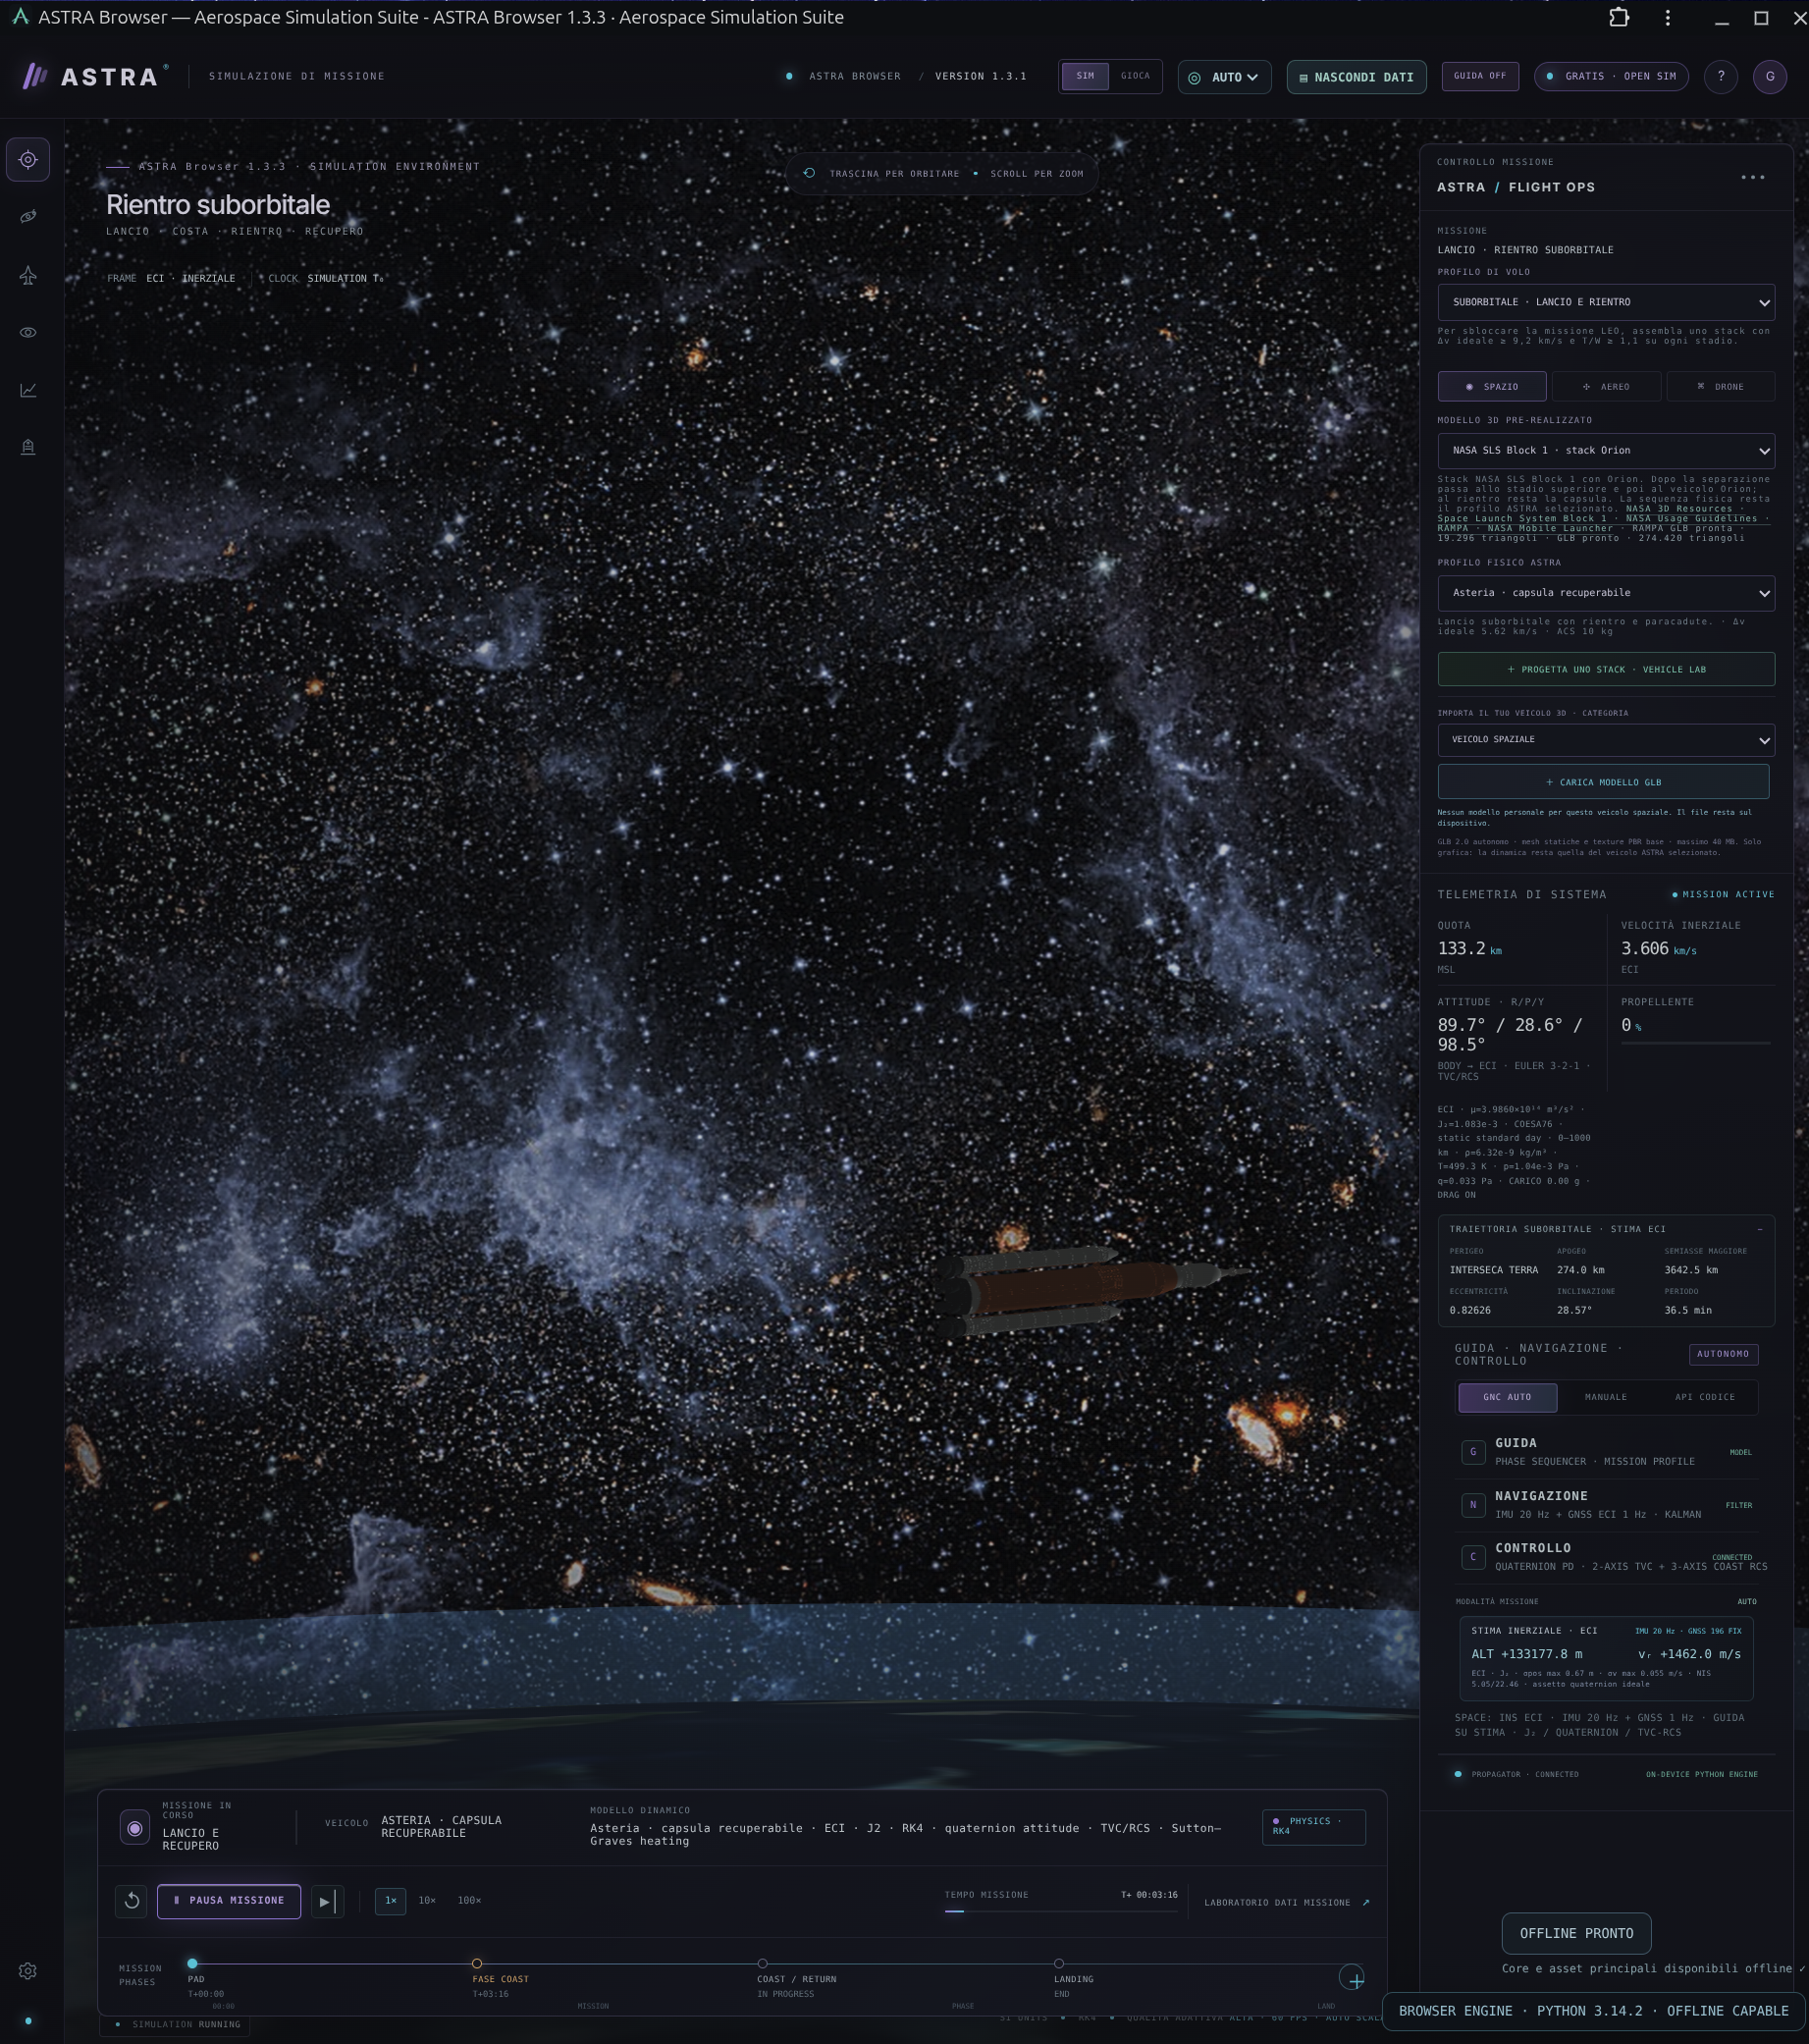
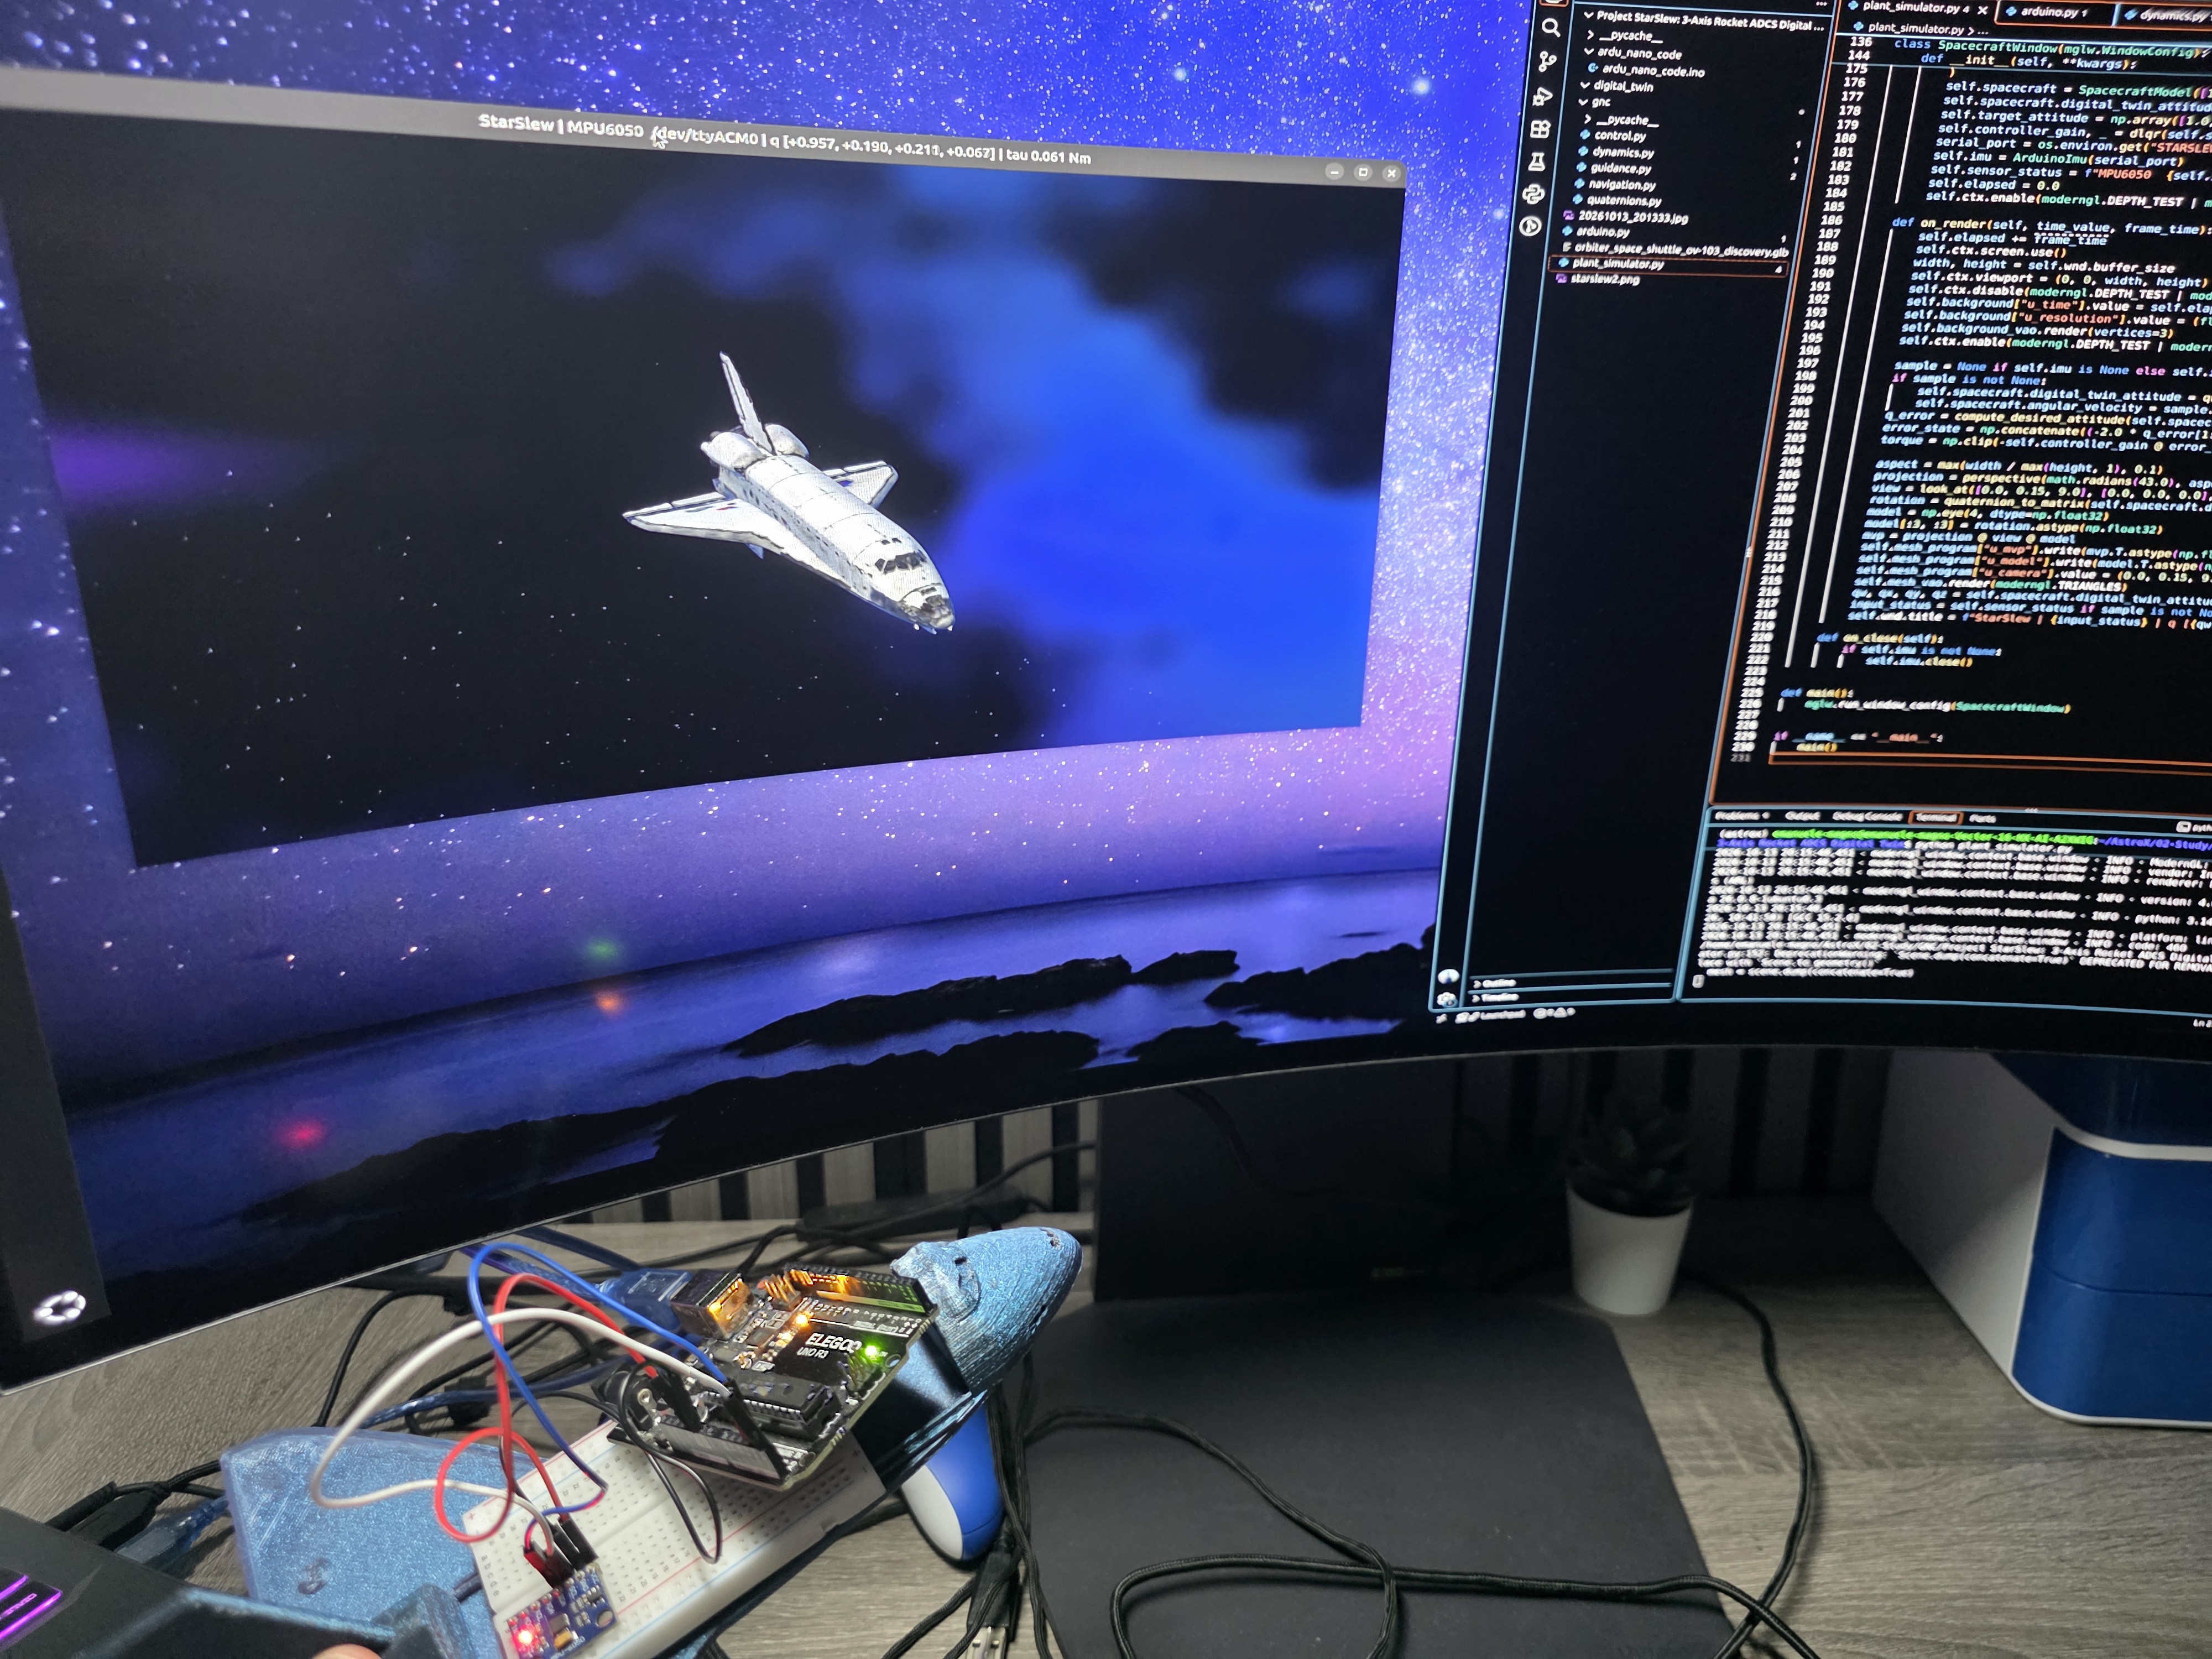
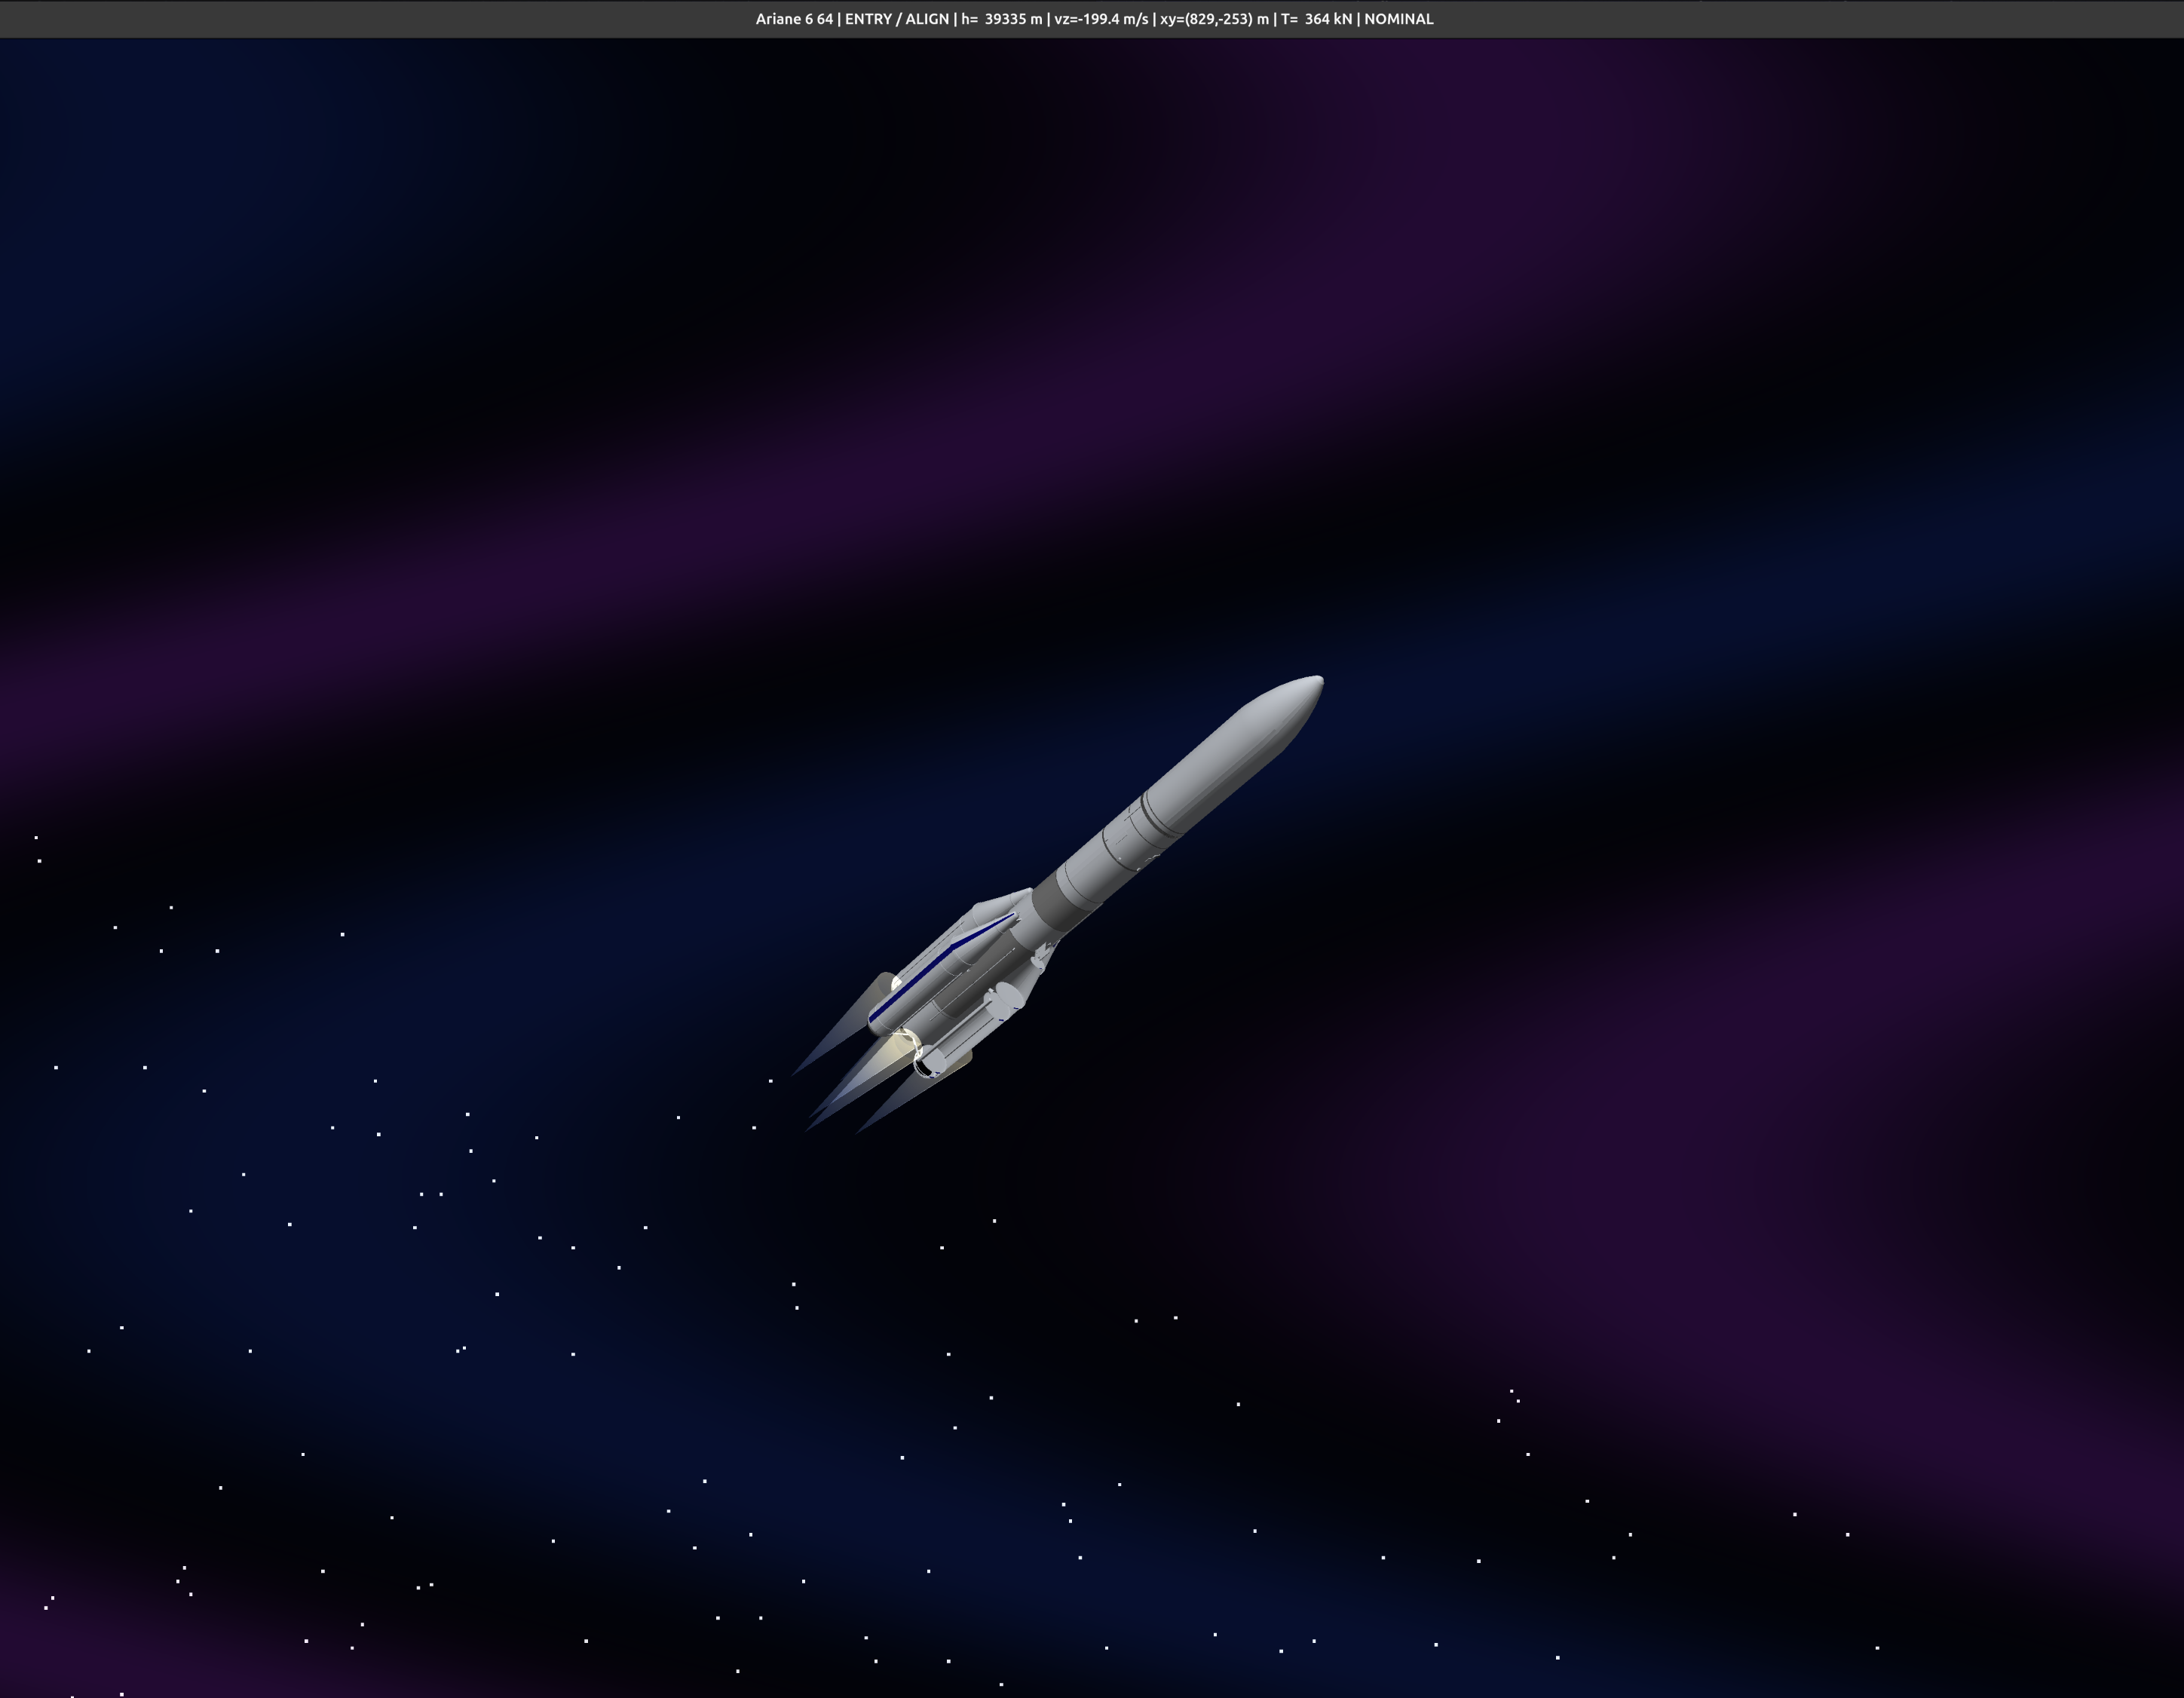
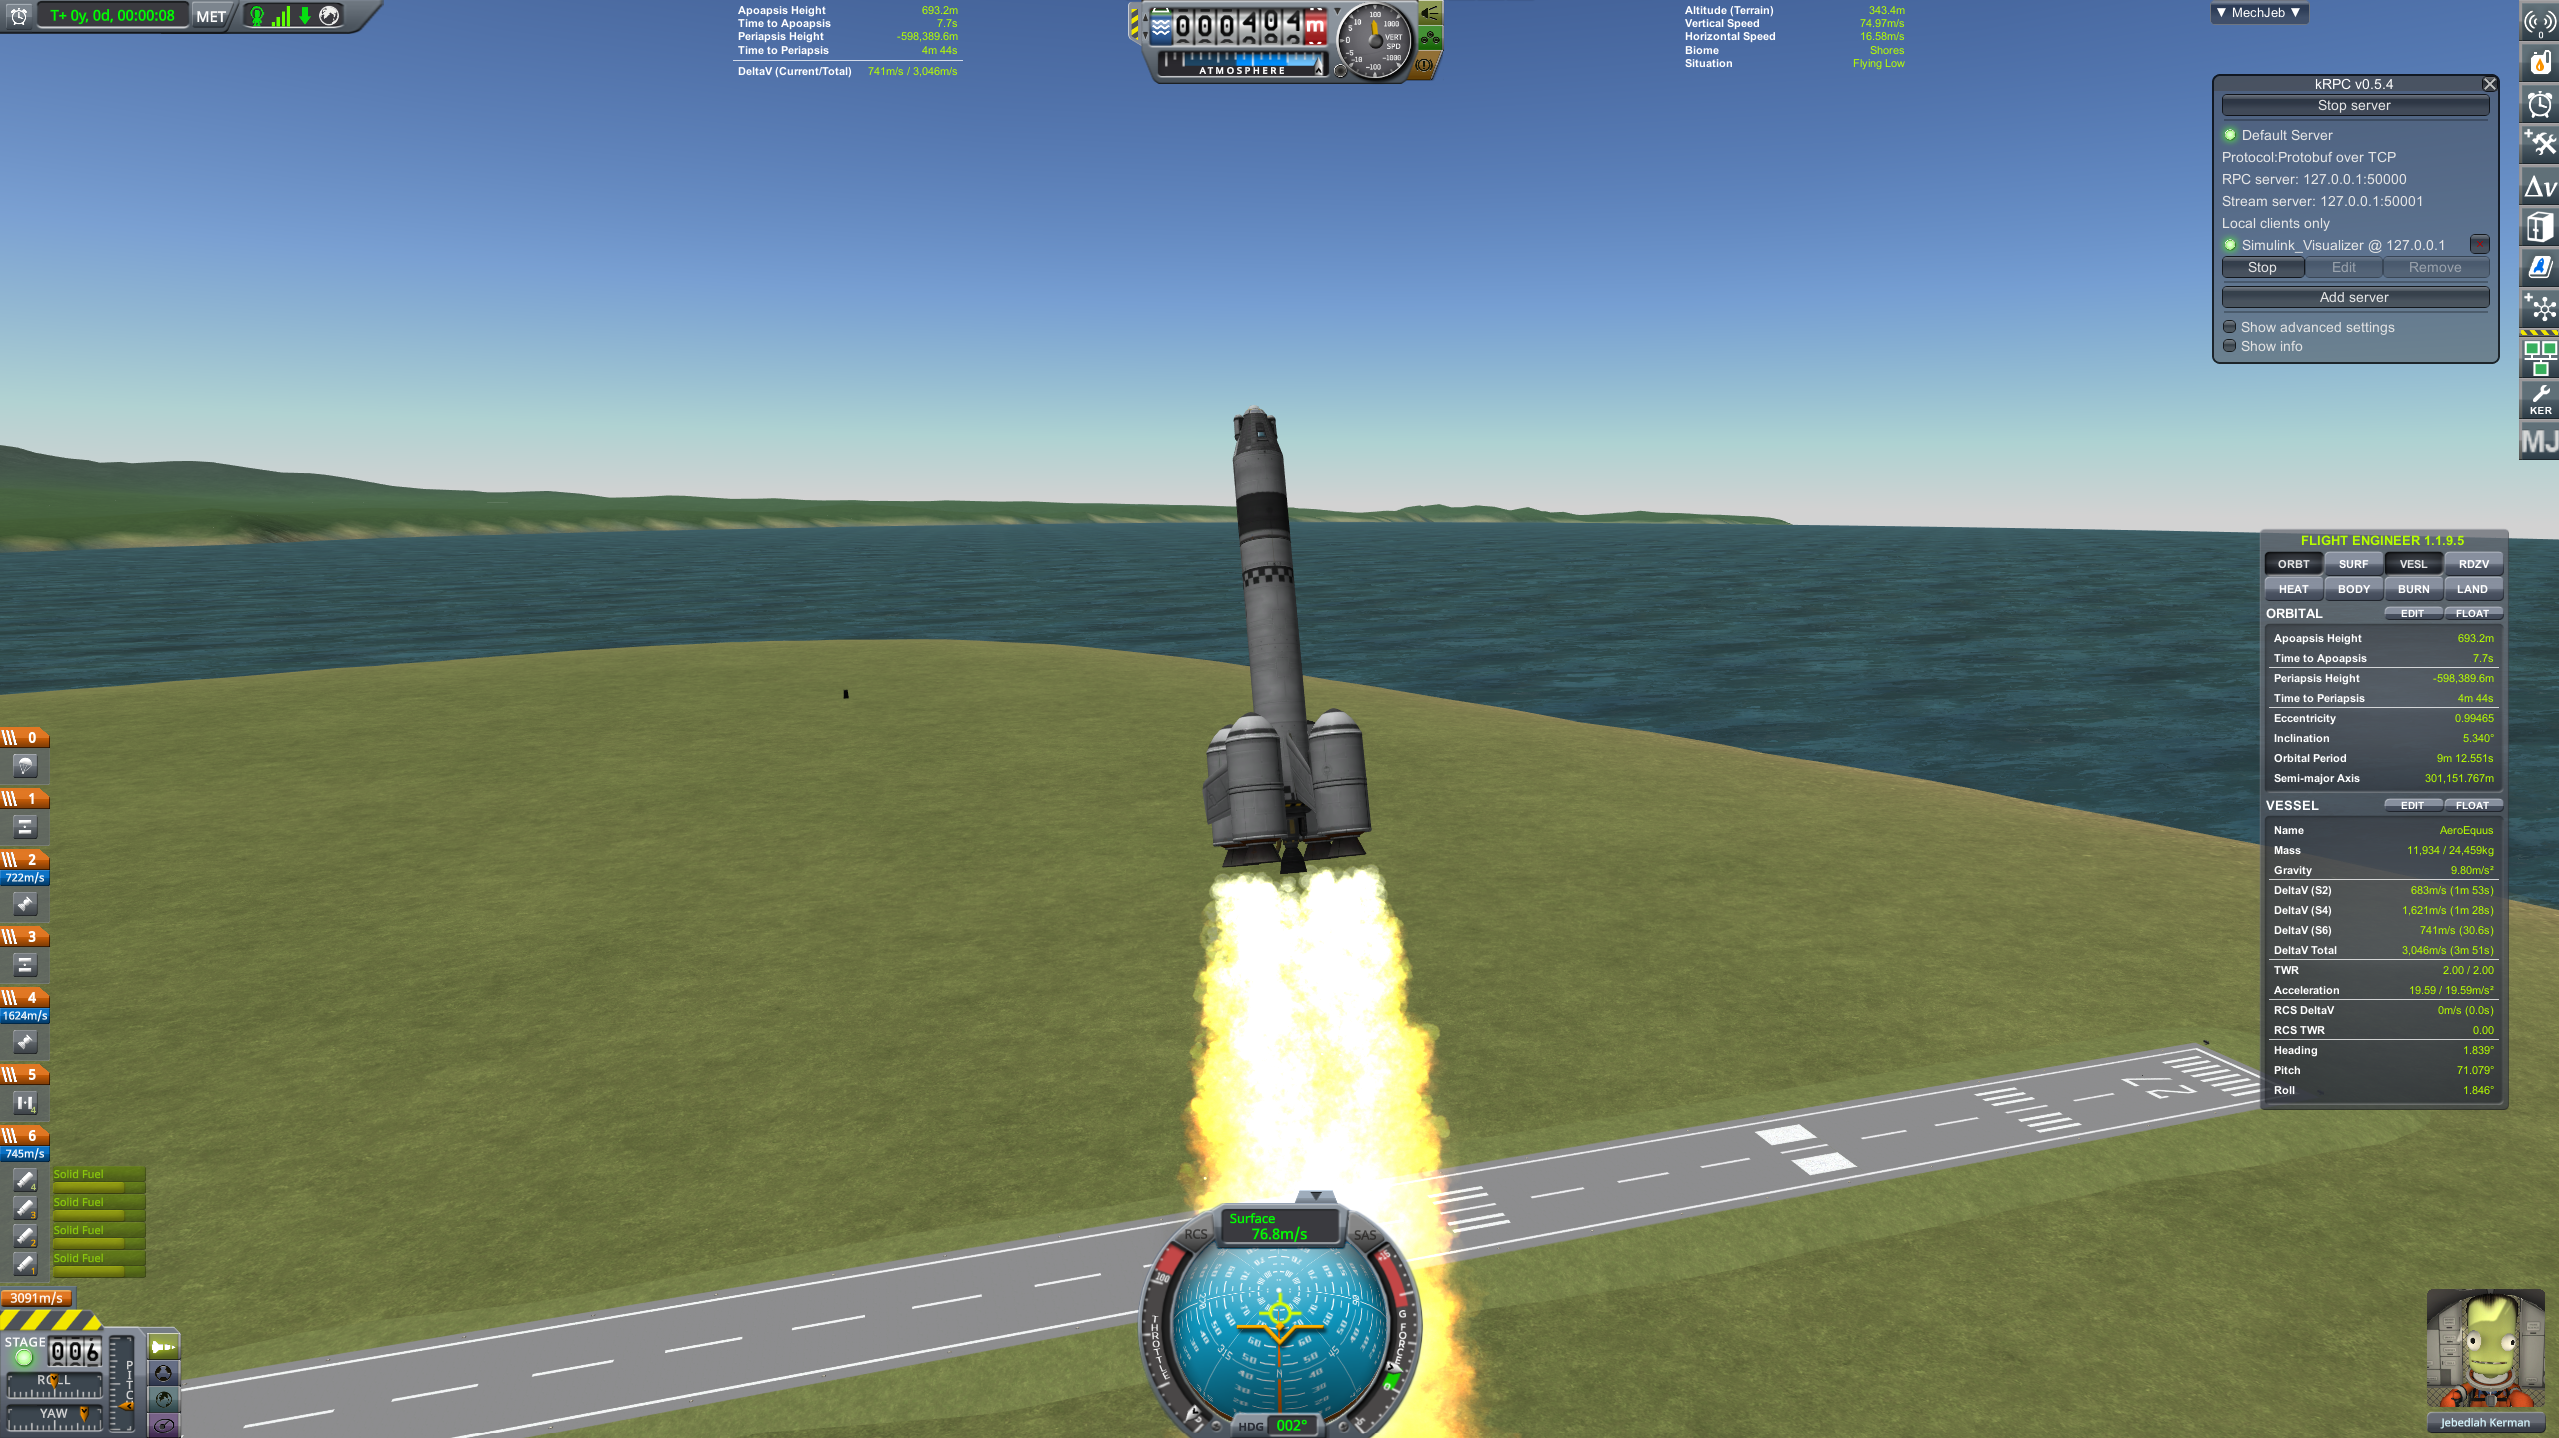
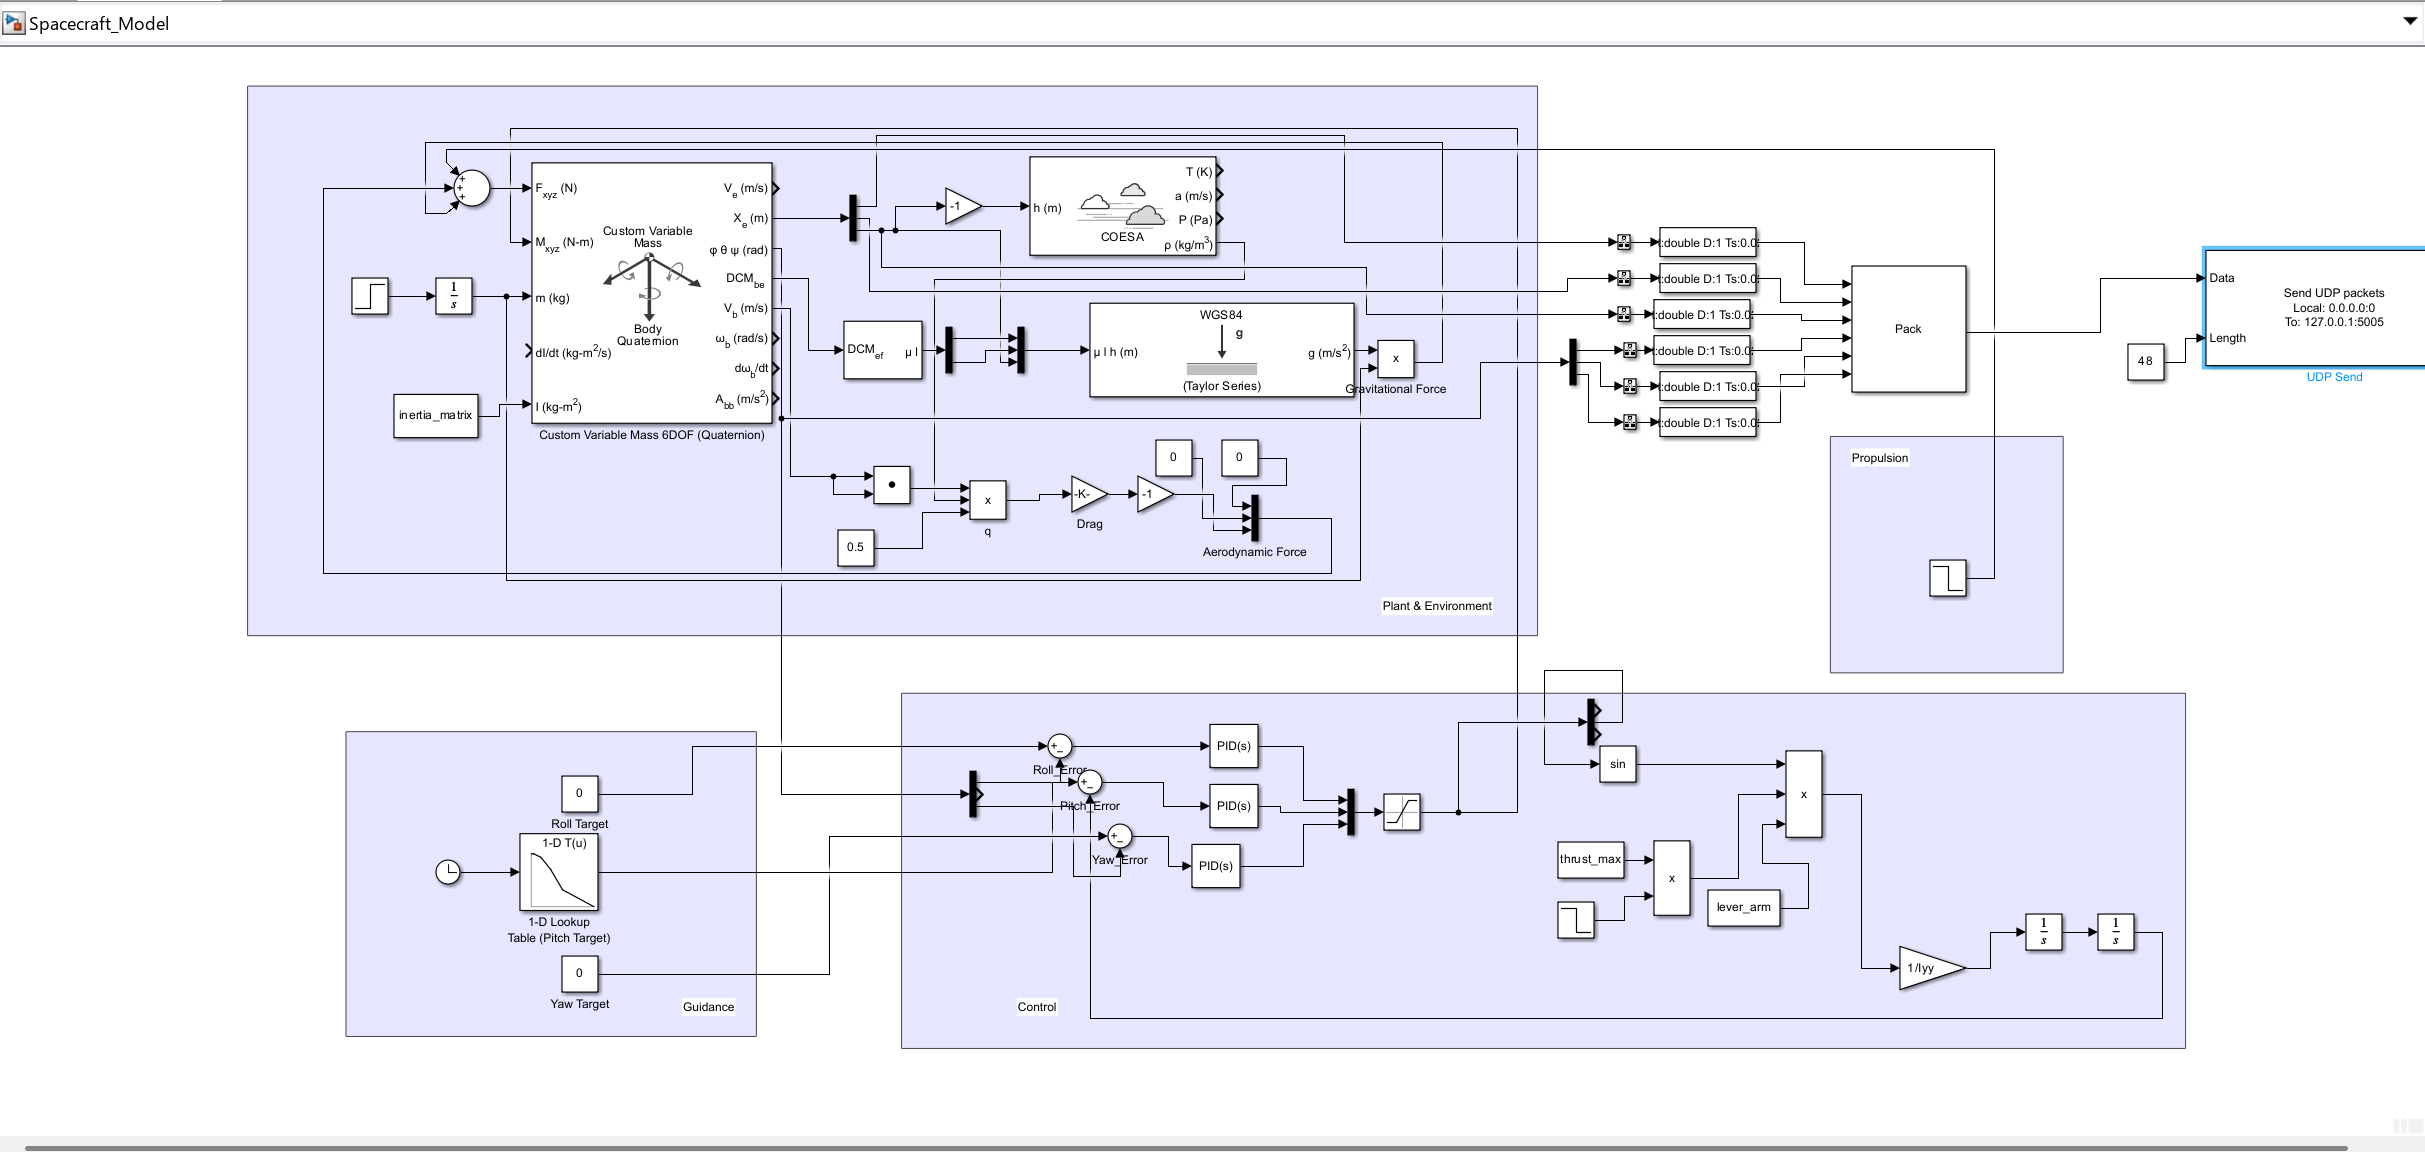
A complete Guidance, Navigation and Control (GNC) simulation framework for autonomous spacecraft operations. The project integrates orbital dynamics, attitude control, trajectory guidance, and mission execution into a modular architecture designed to emulate real spacecraft autonomy.
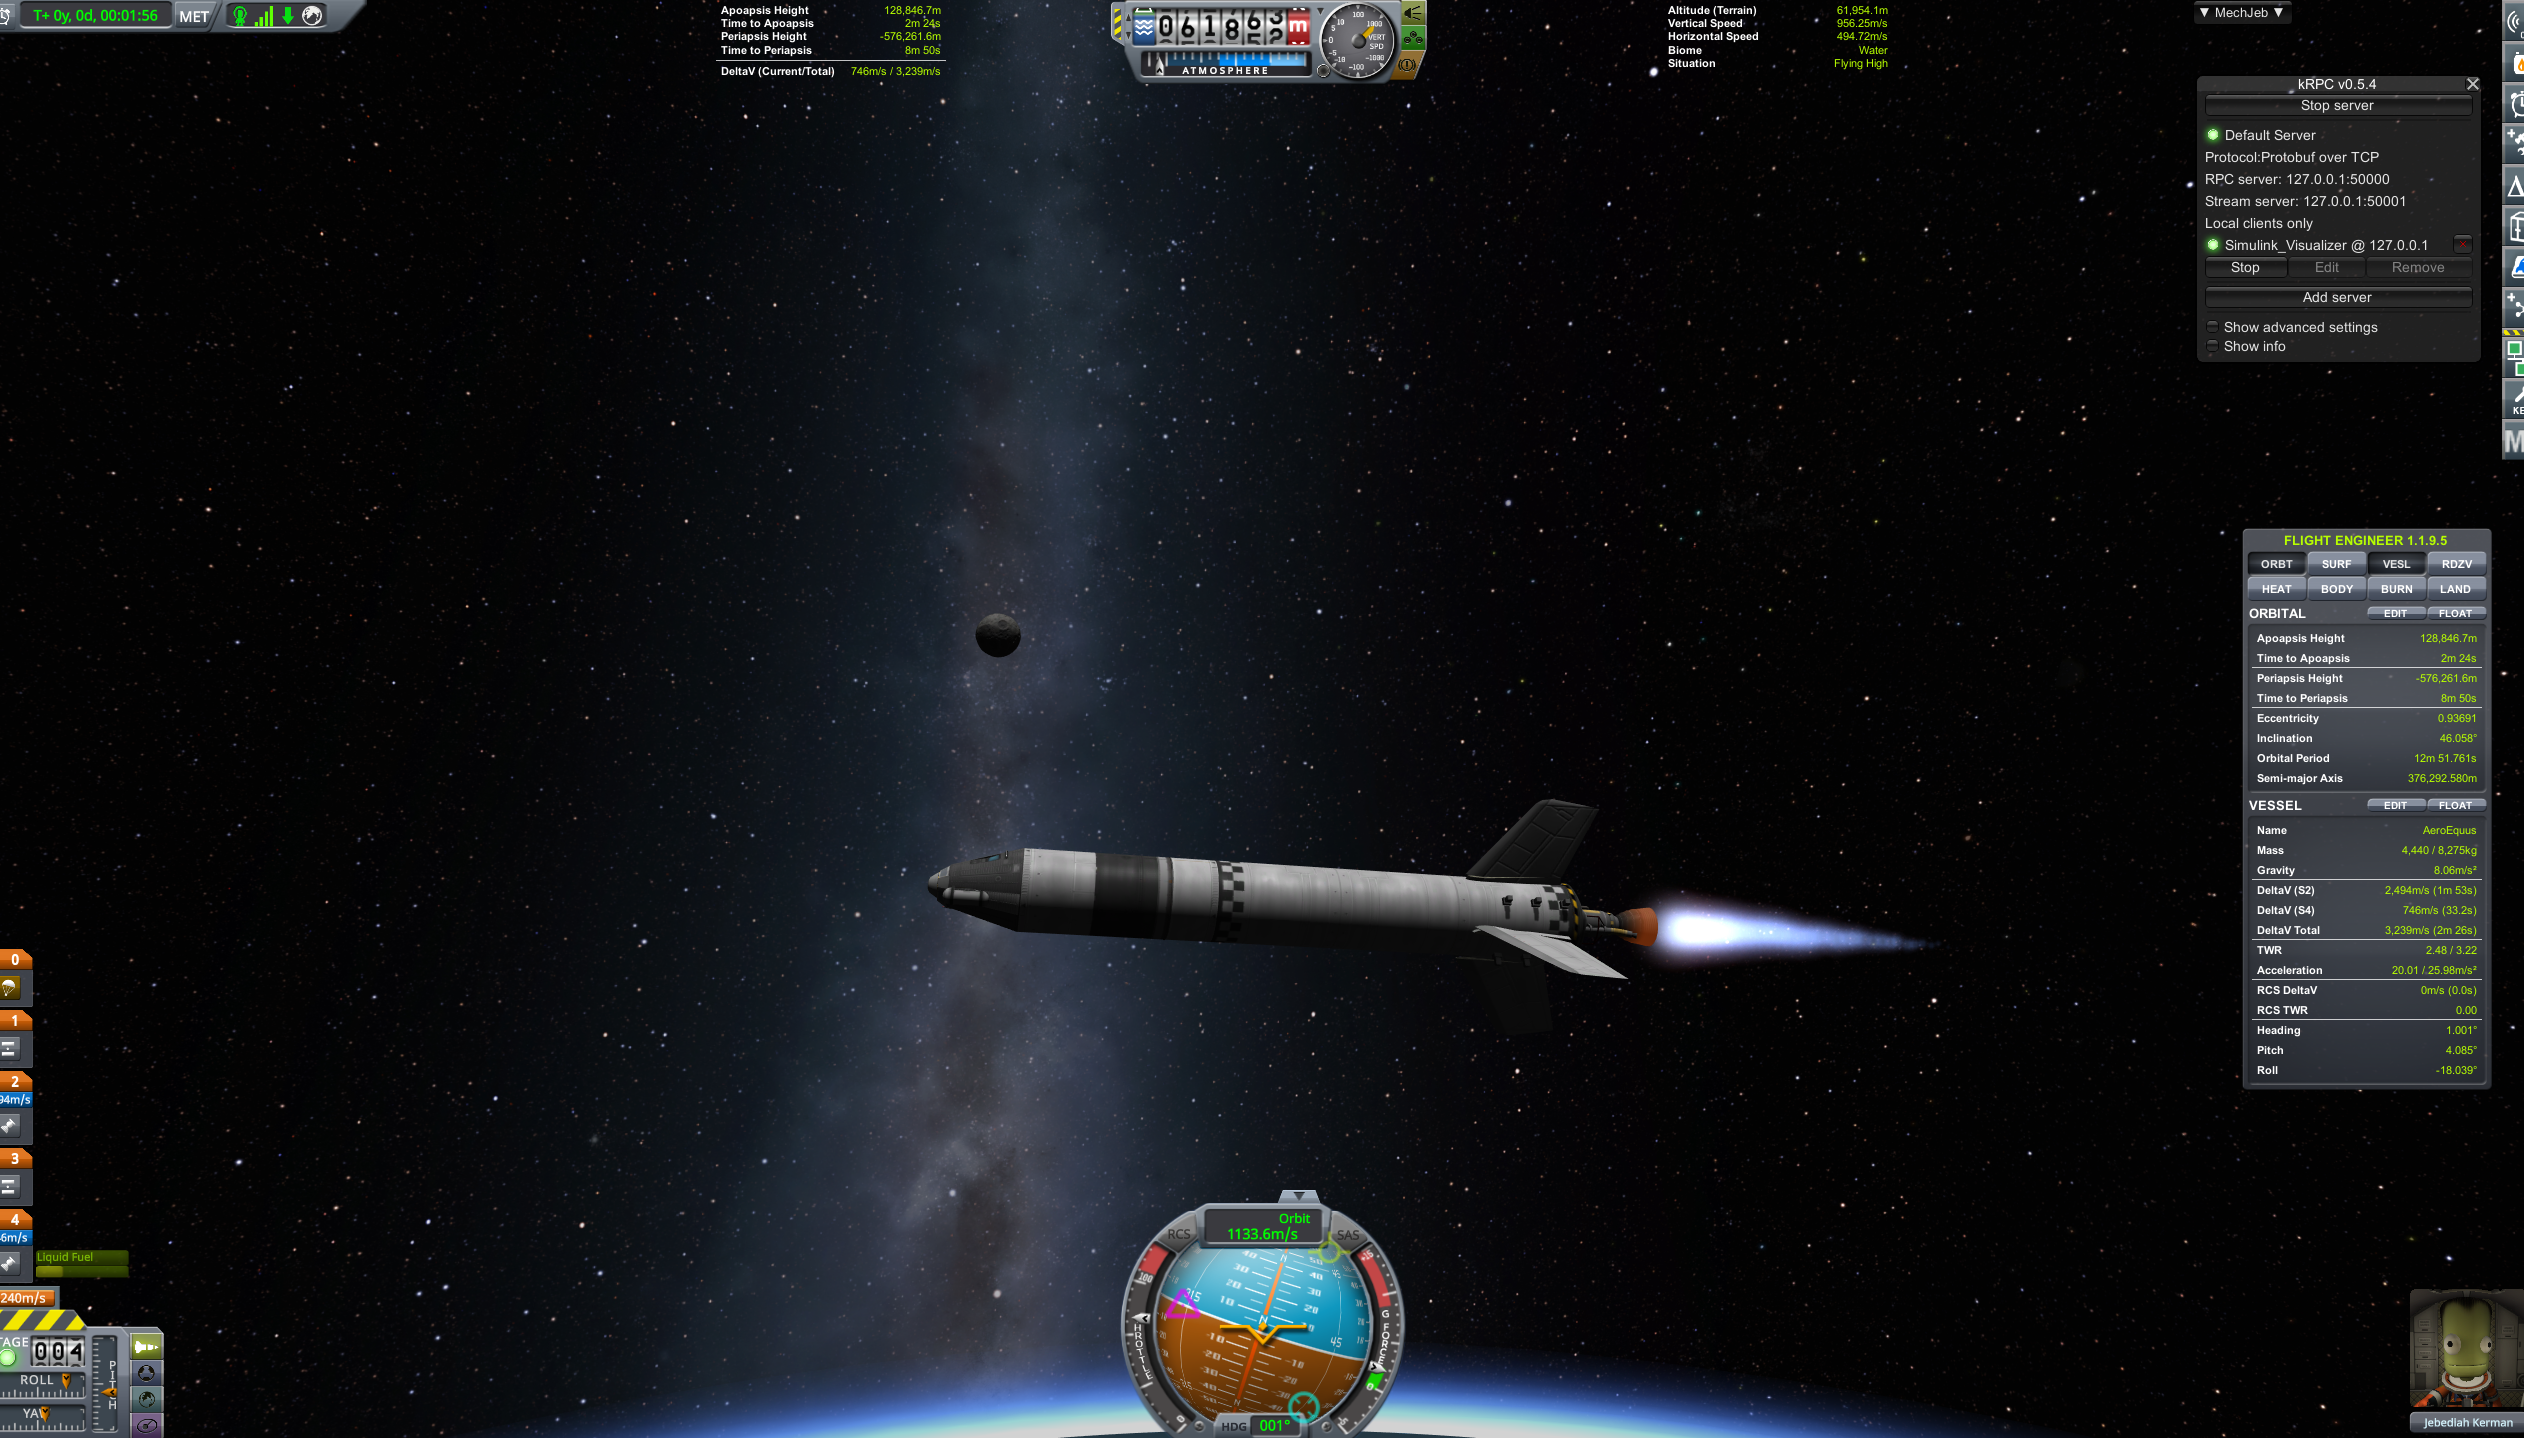
Challenge
Design a realistic autonomous GNC architecture capable of managing spacecraft guidance, navigation, and control simultaneously while maintaining numerical stability and modularity for future subsystem expansion.
Approach
Developed a modular Python-based simulation framework combining orbital propagation, control algorithms, spacecraft dynamics, and mission logic. The architecture separates guidance, navigation, and control layers to improve maintainability, scalability, and algorithm testing.
Outcome
Produced a reusable spacecraft GNC framework capable of simulating autonomous mission scenarios while providing a foundation for advanced guidance algorithms, state estimation, and autonomous decision-making.
Tools
Roadmap
Autonomous Spacecraft GNC
A complete Guidance, Navigation and Control (GNC) simulation framework for autonomous spacecraft operations. The project integrates orbital dynamics, attitude control, trajectory guidance, and mission execution into a modular architecture designed to emulate real spacecraft autonomy.
Completed