ZENITH · ECHO 1387
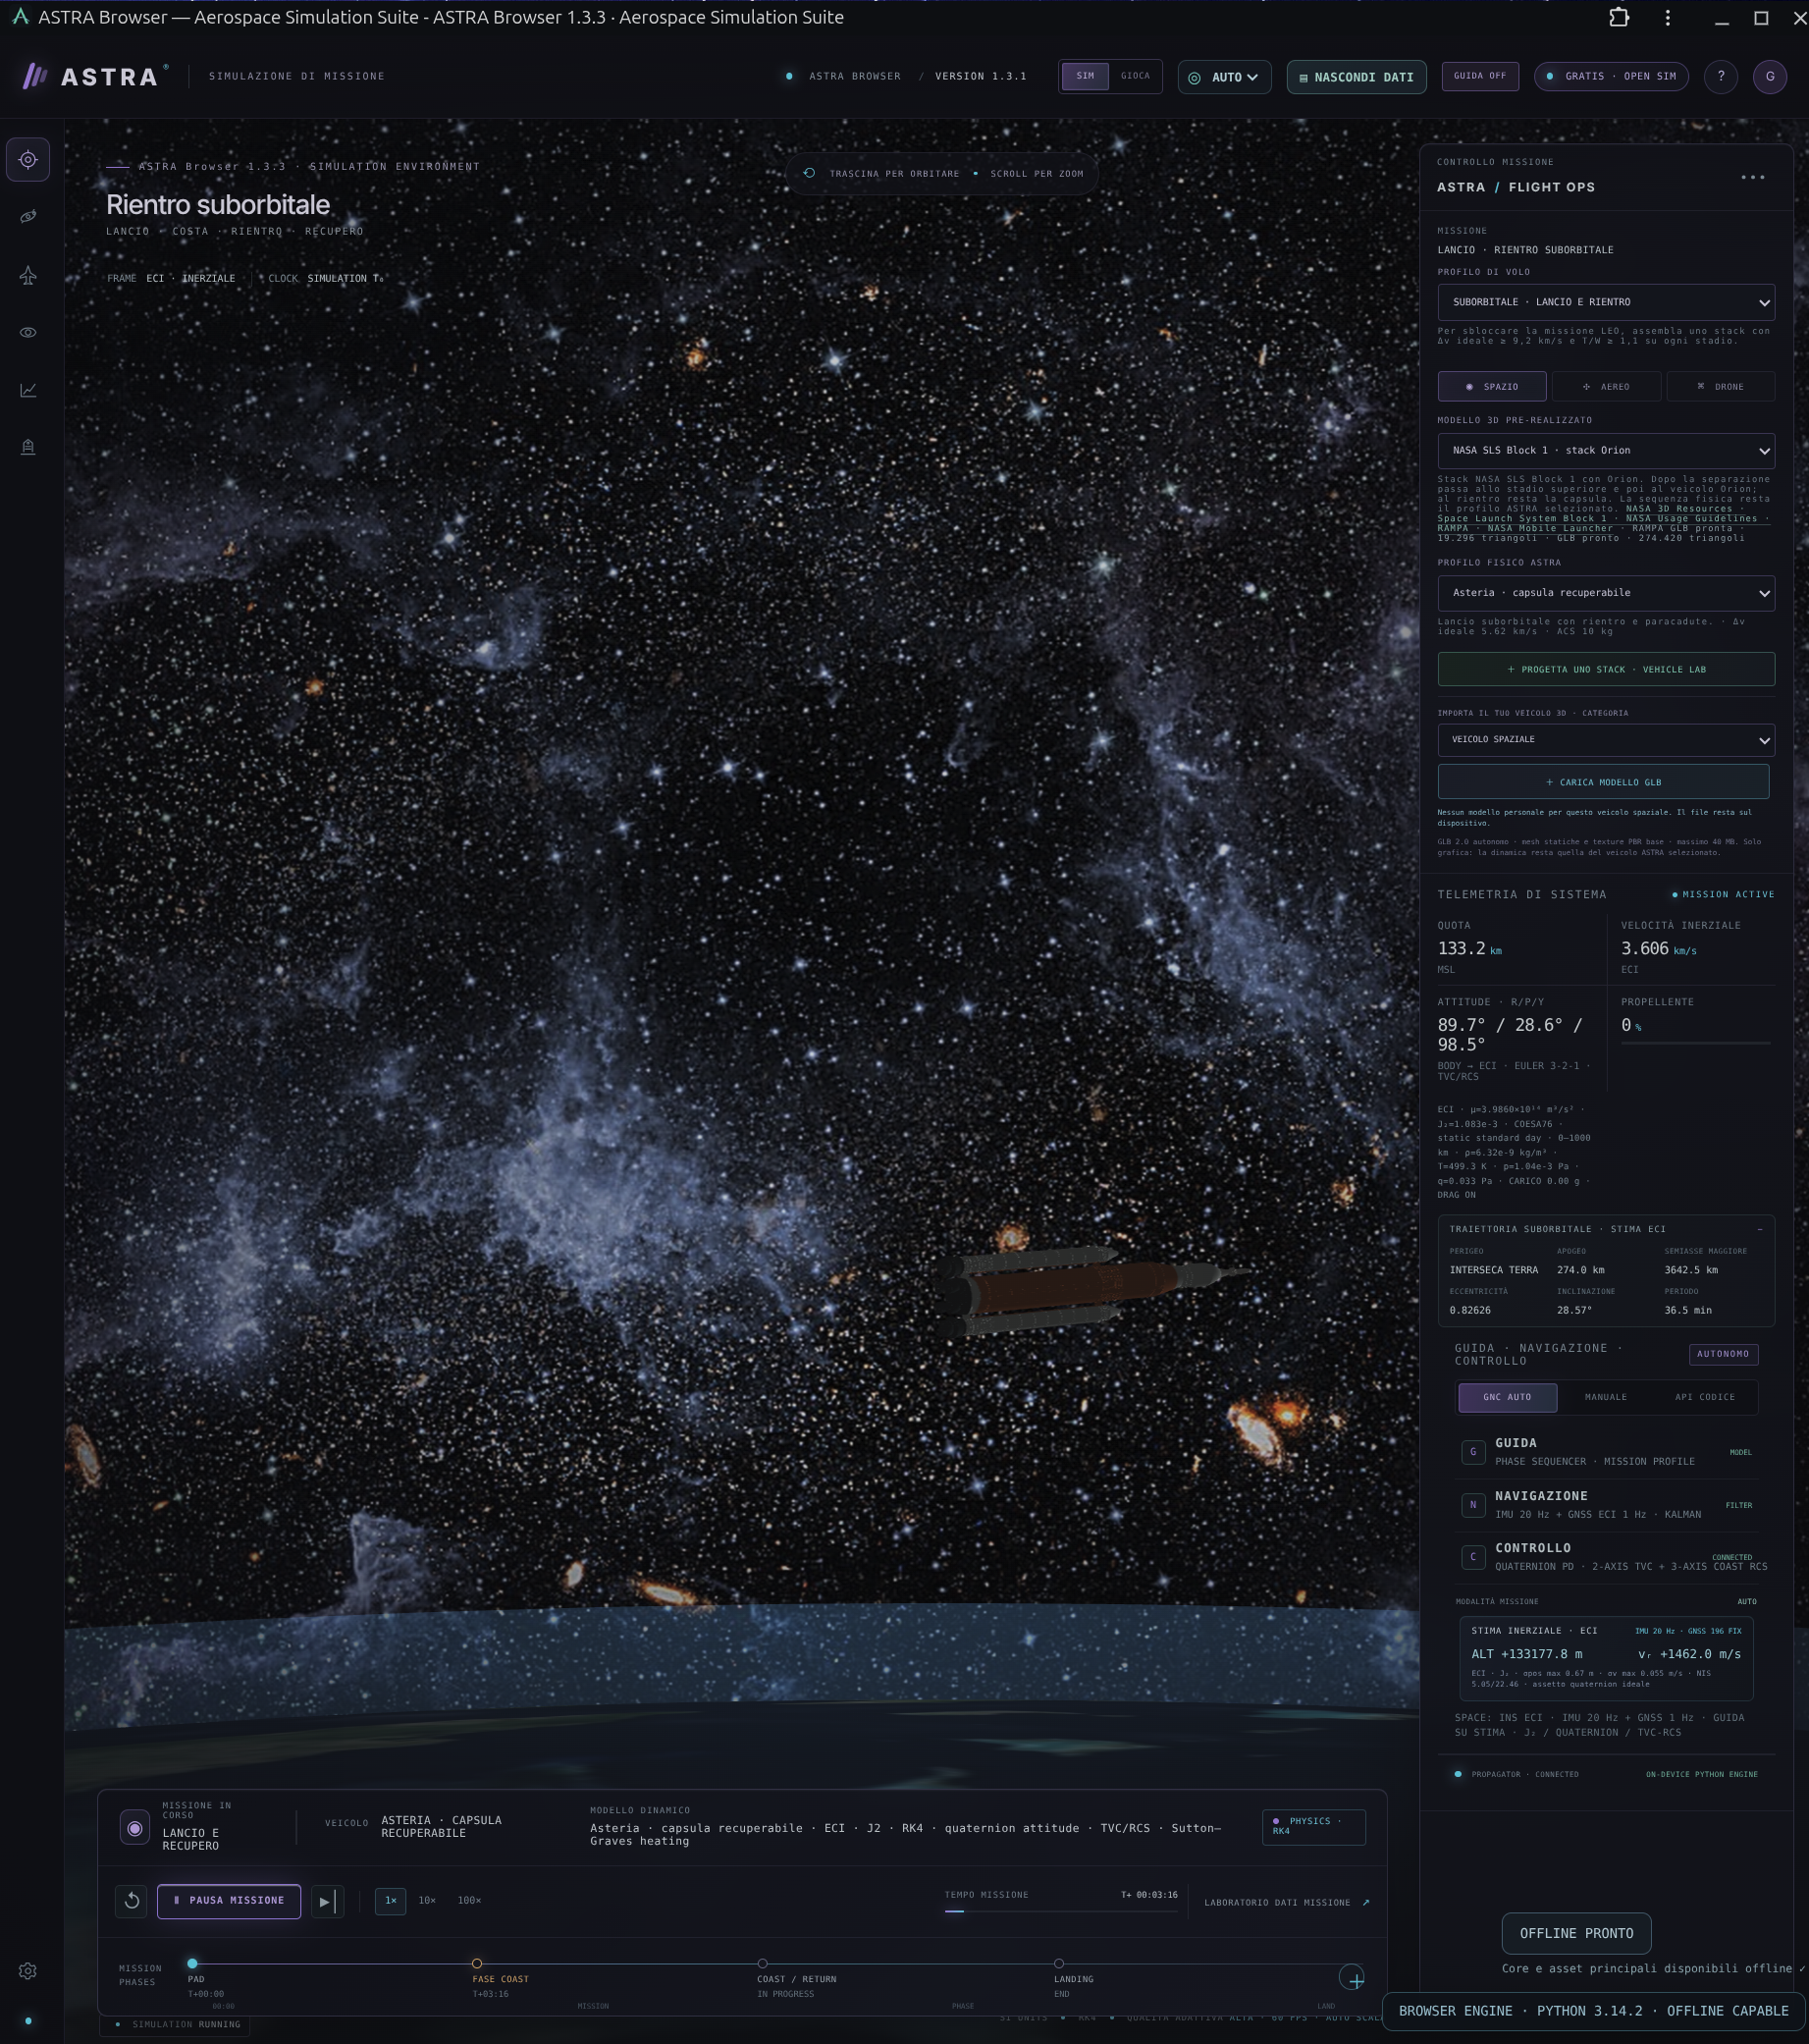
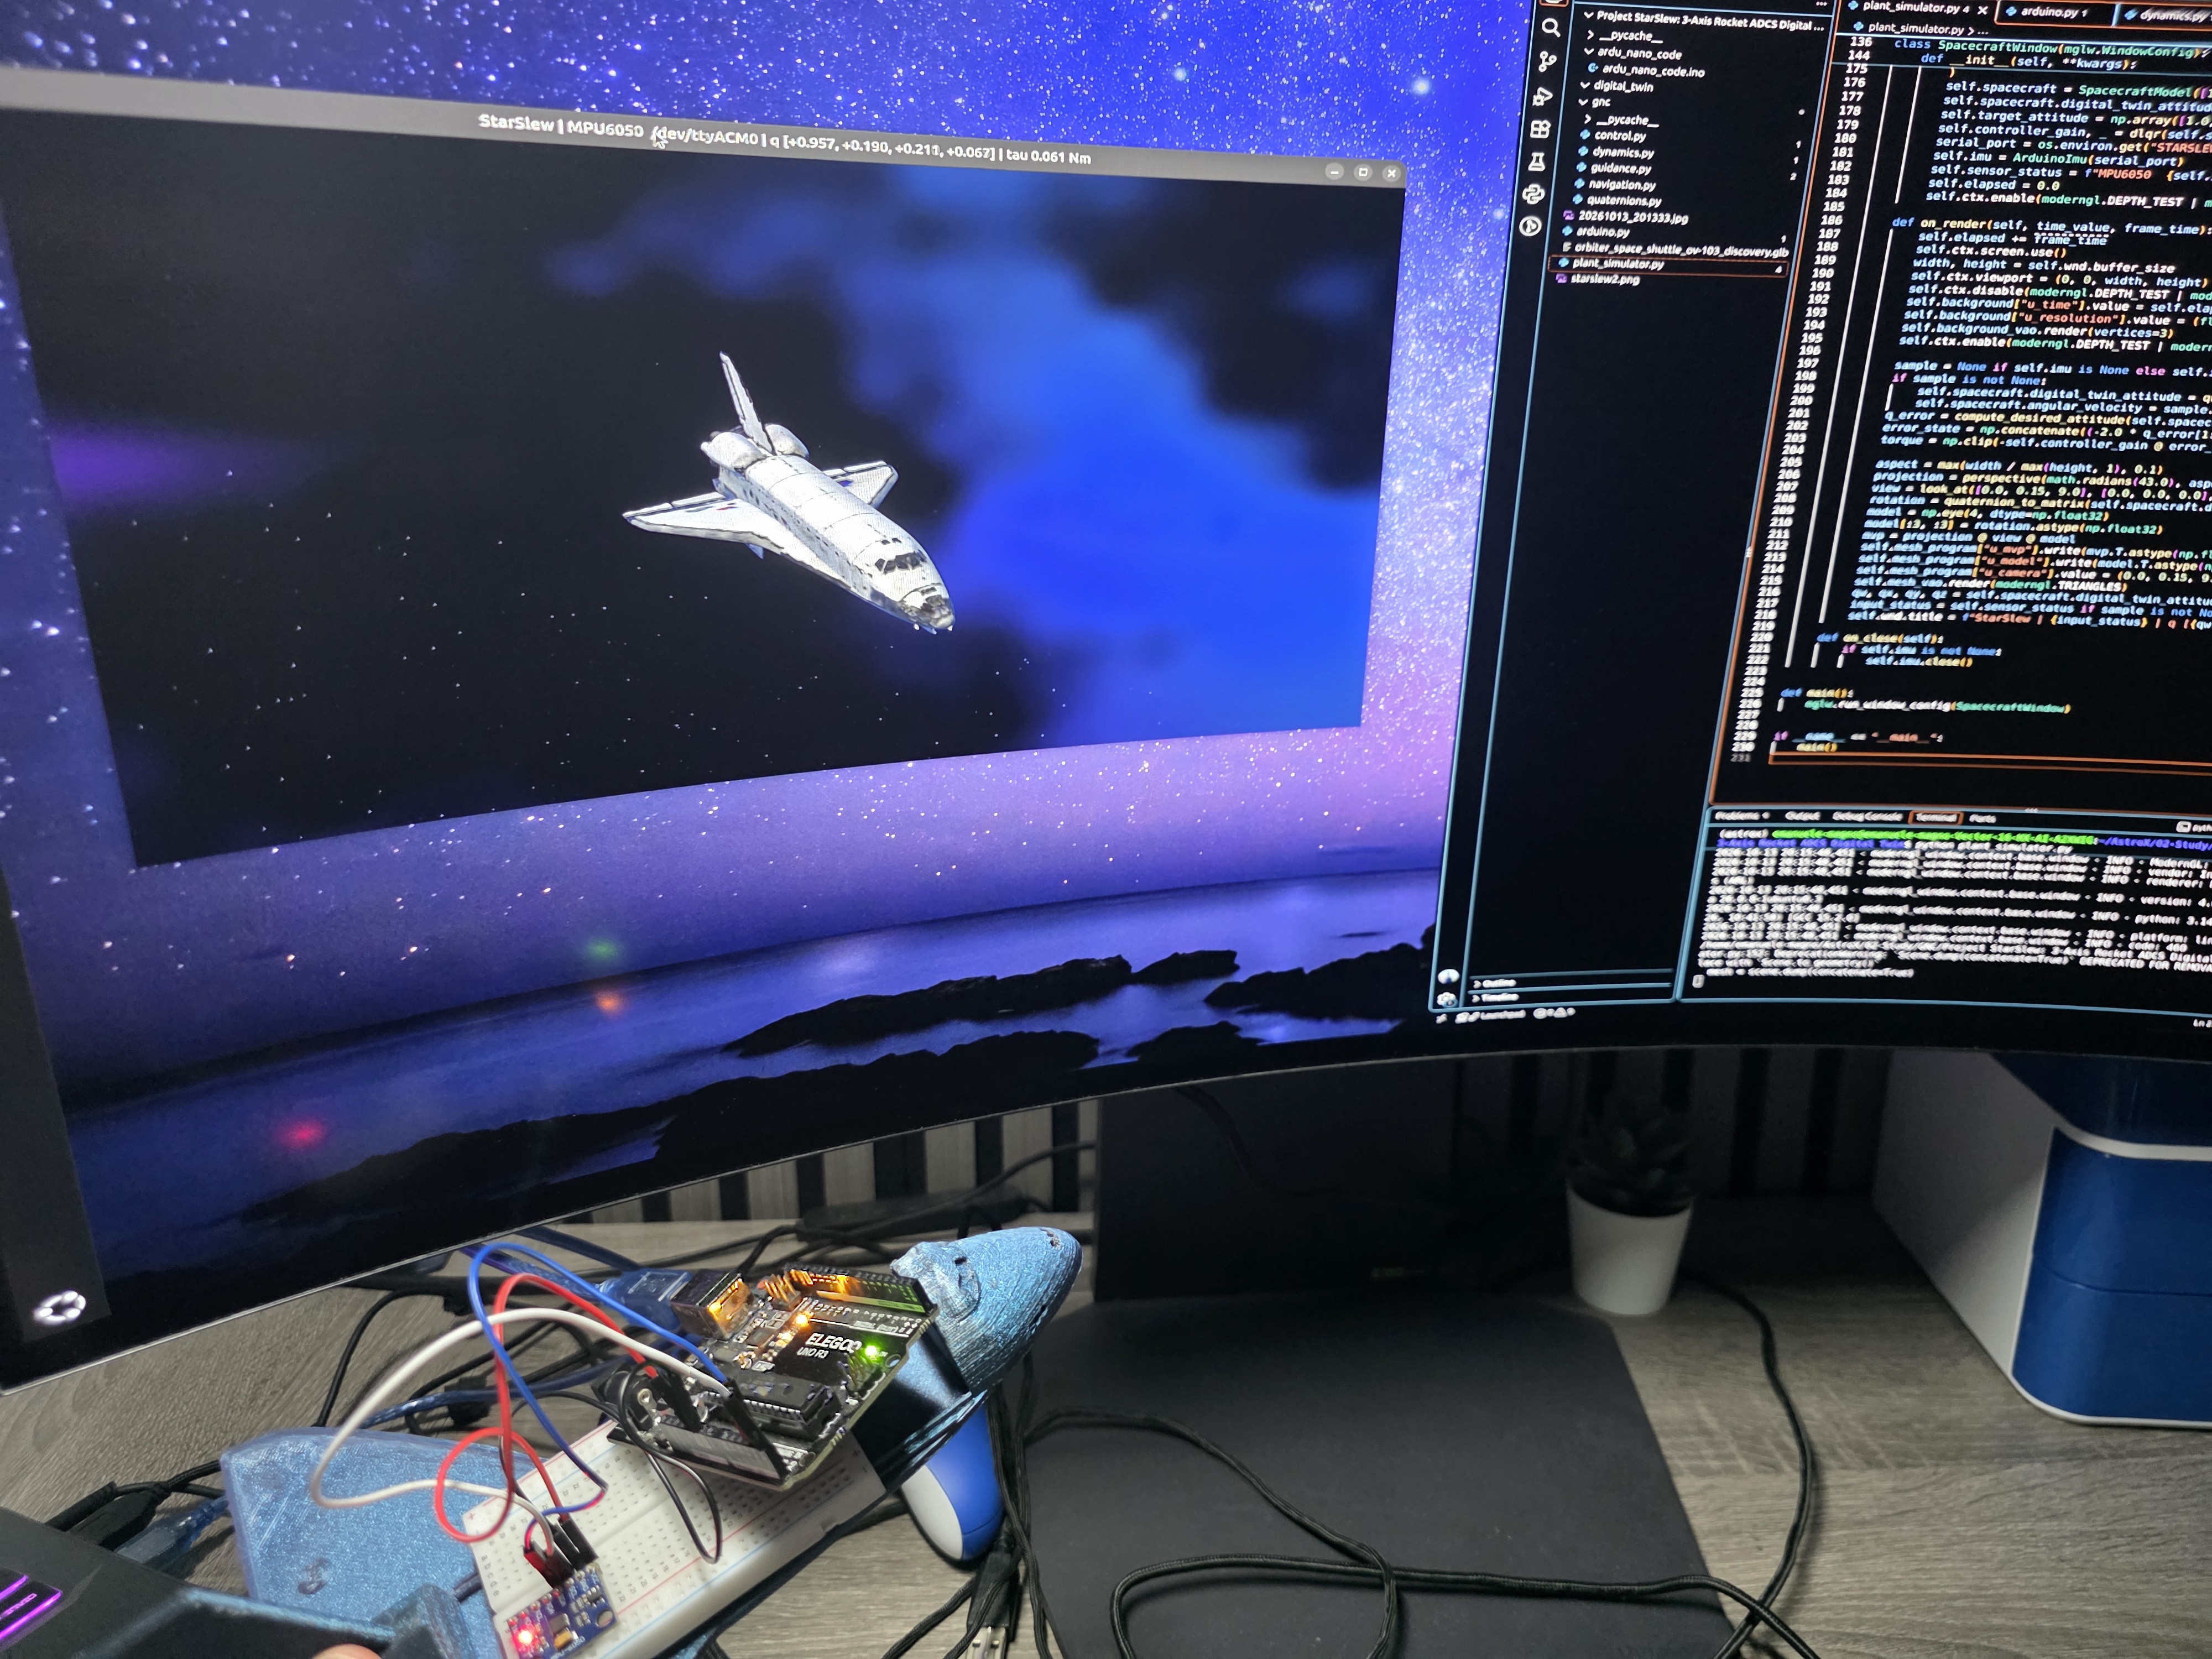
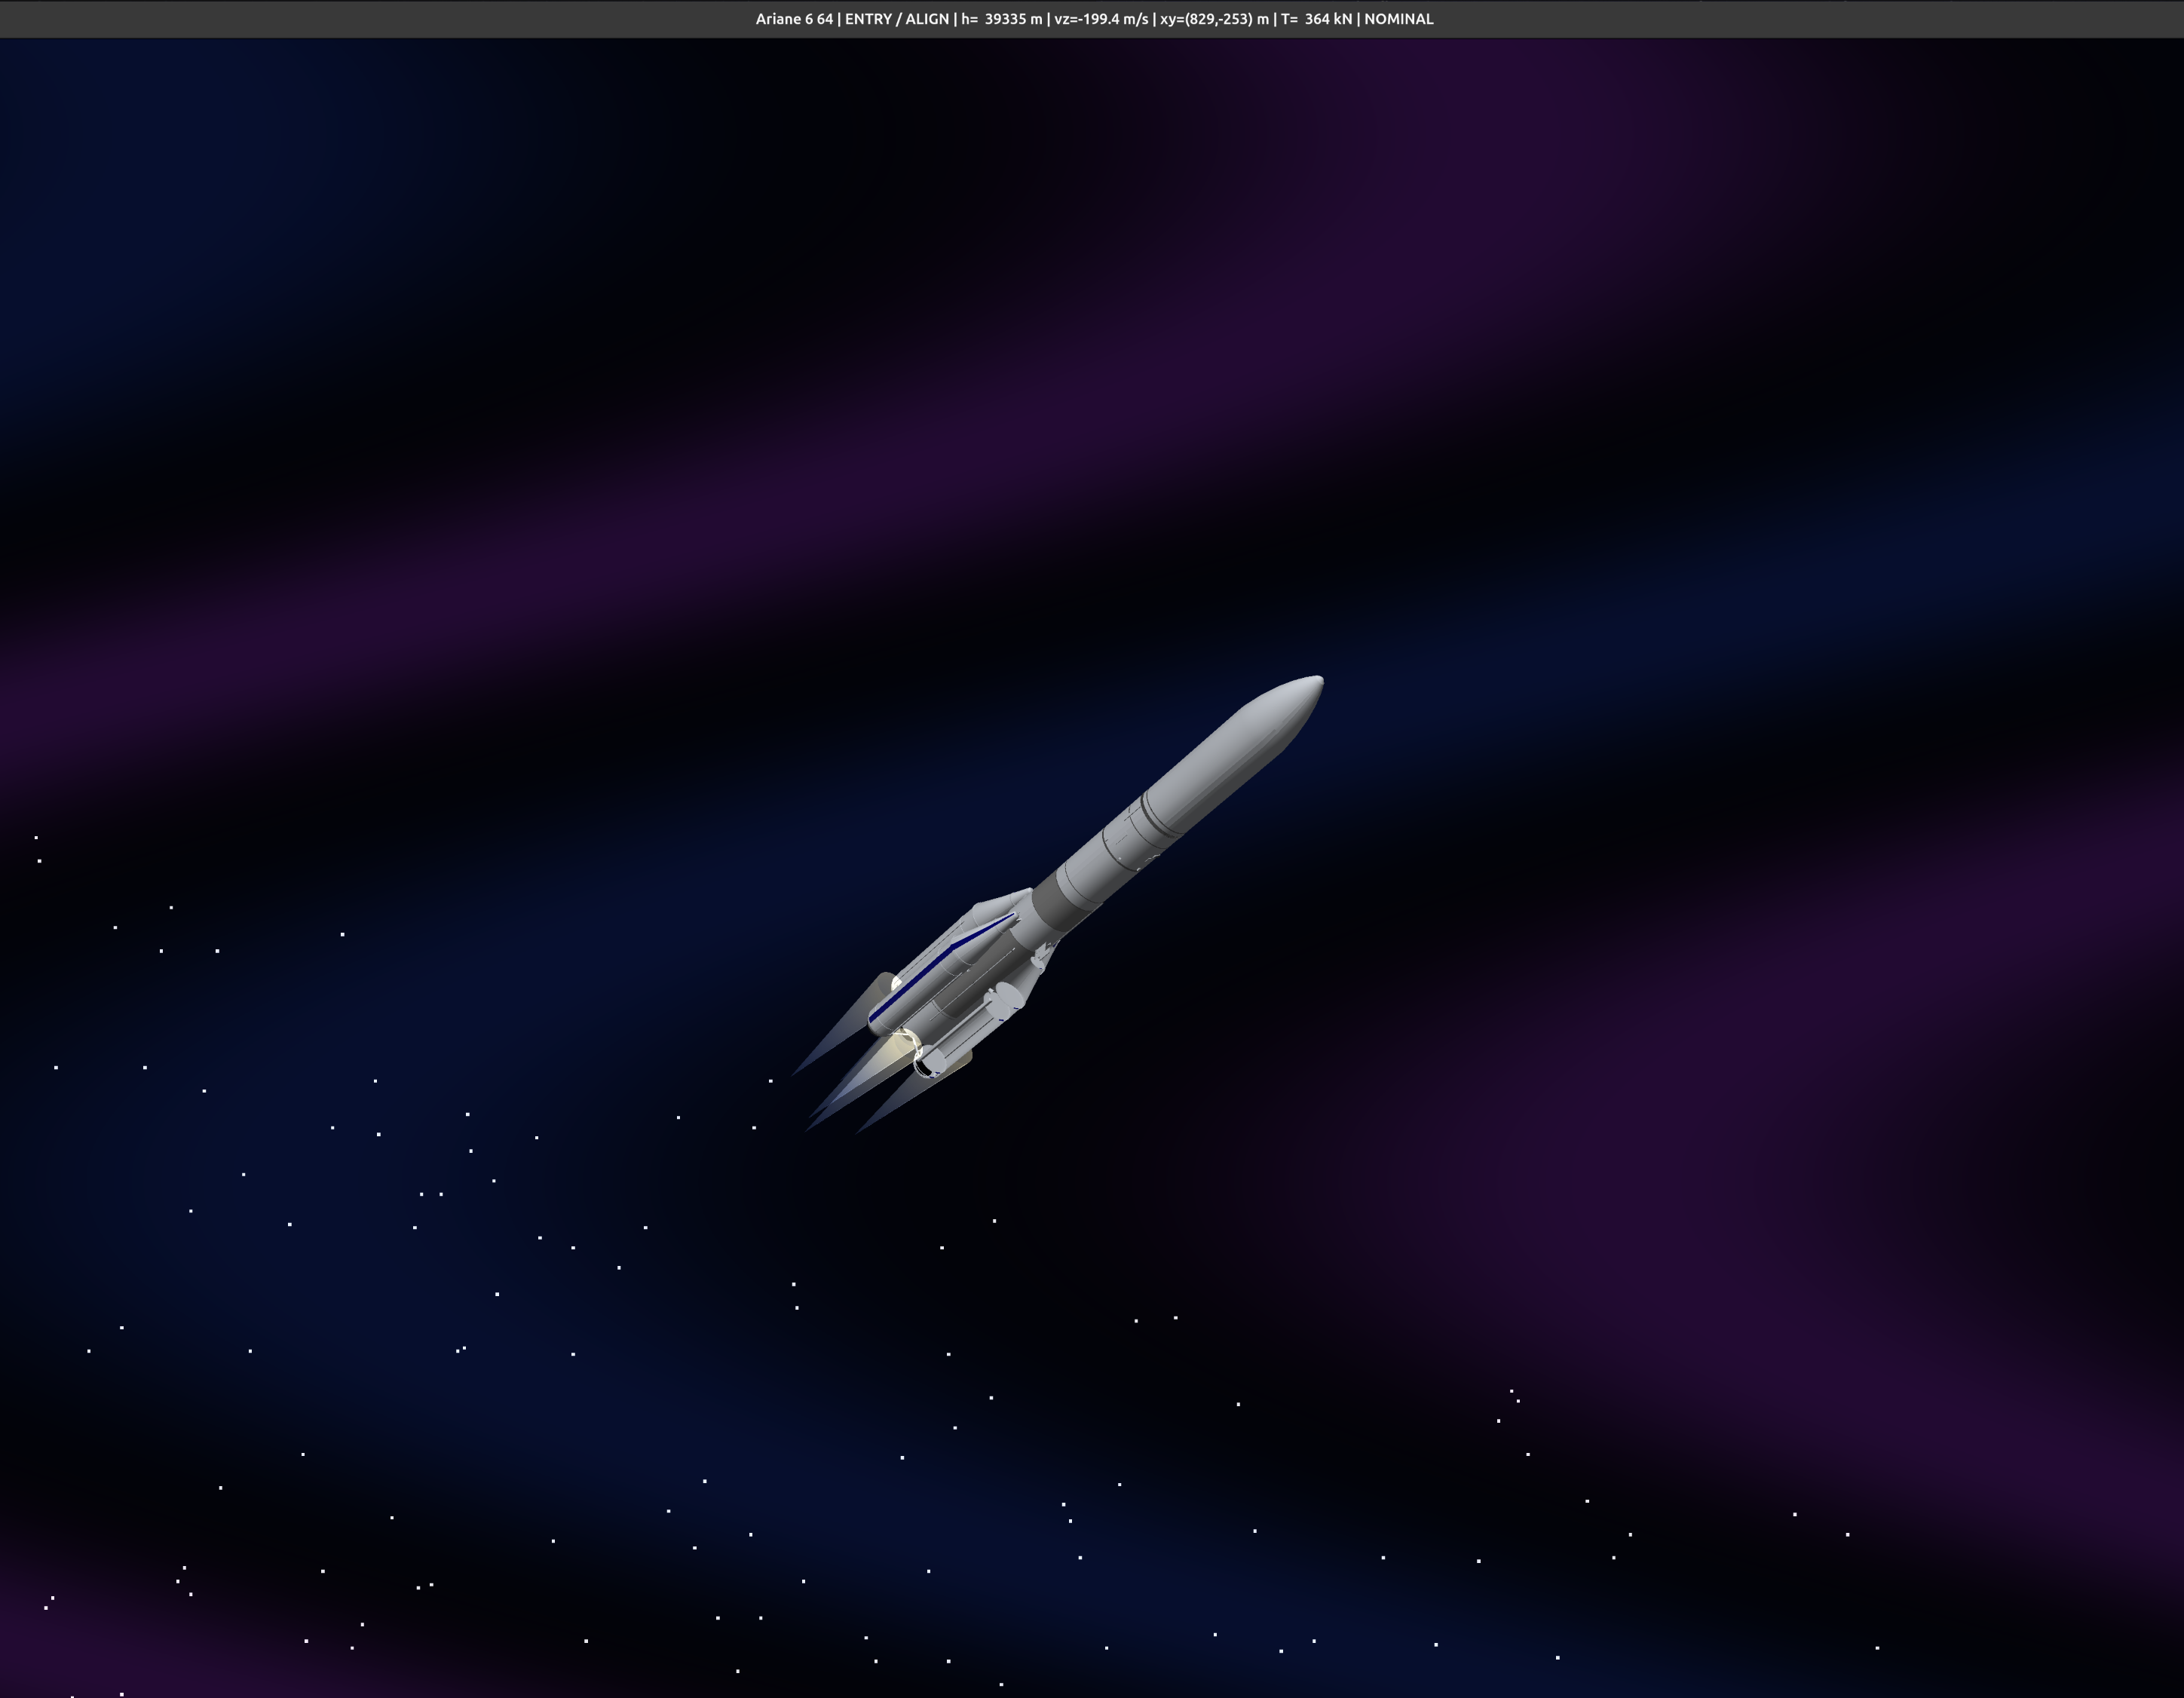
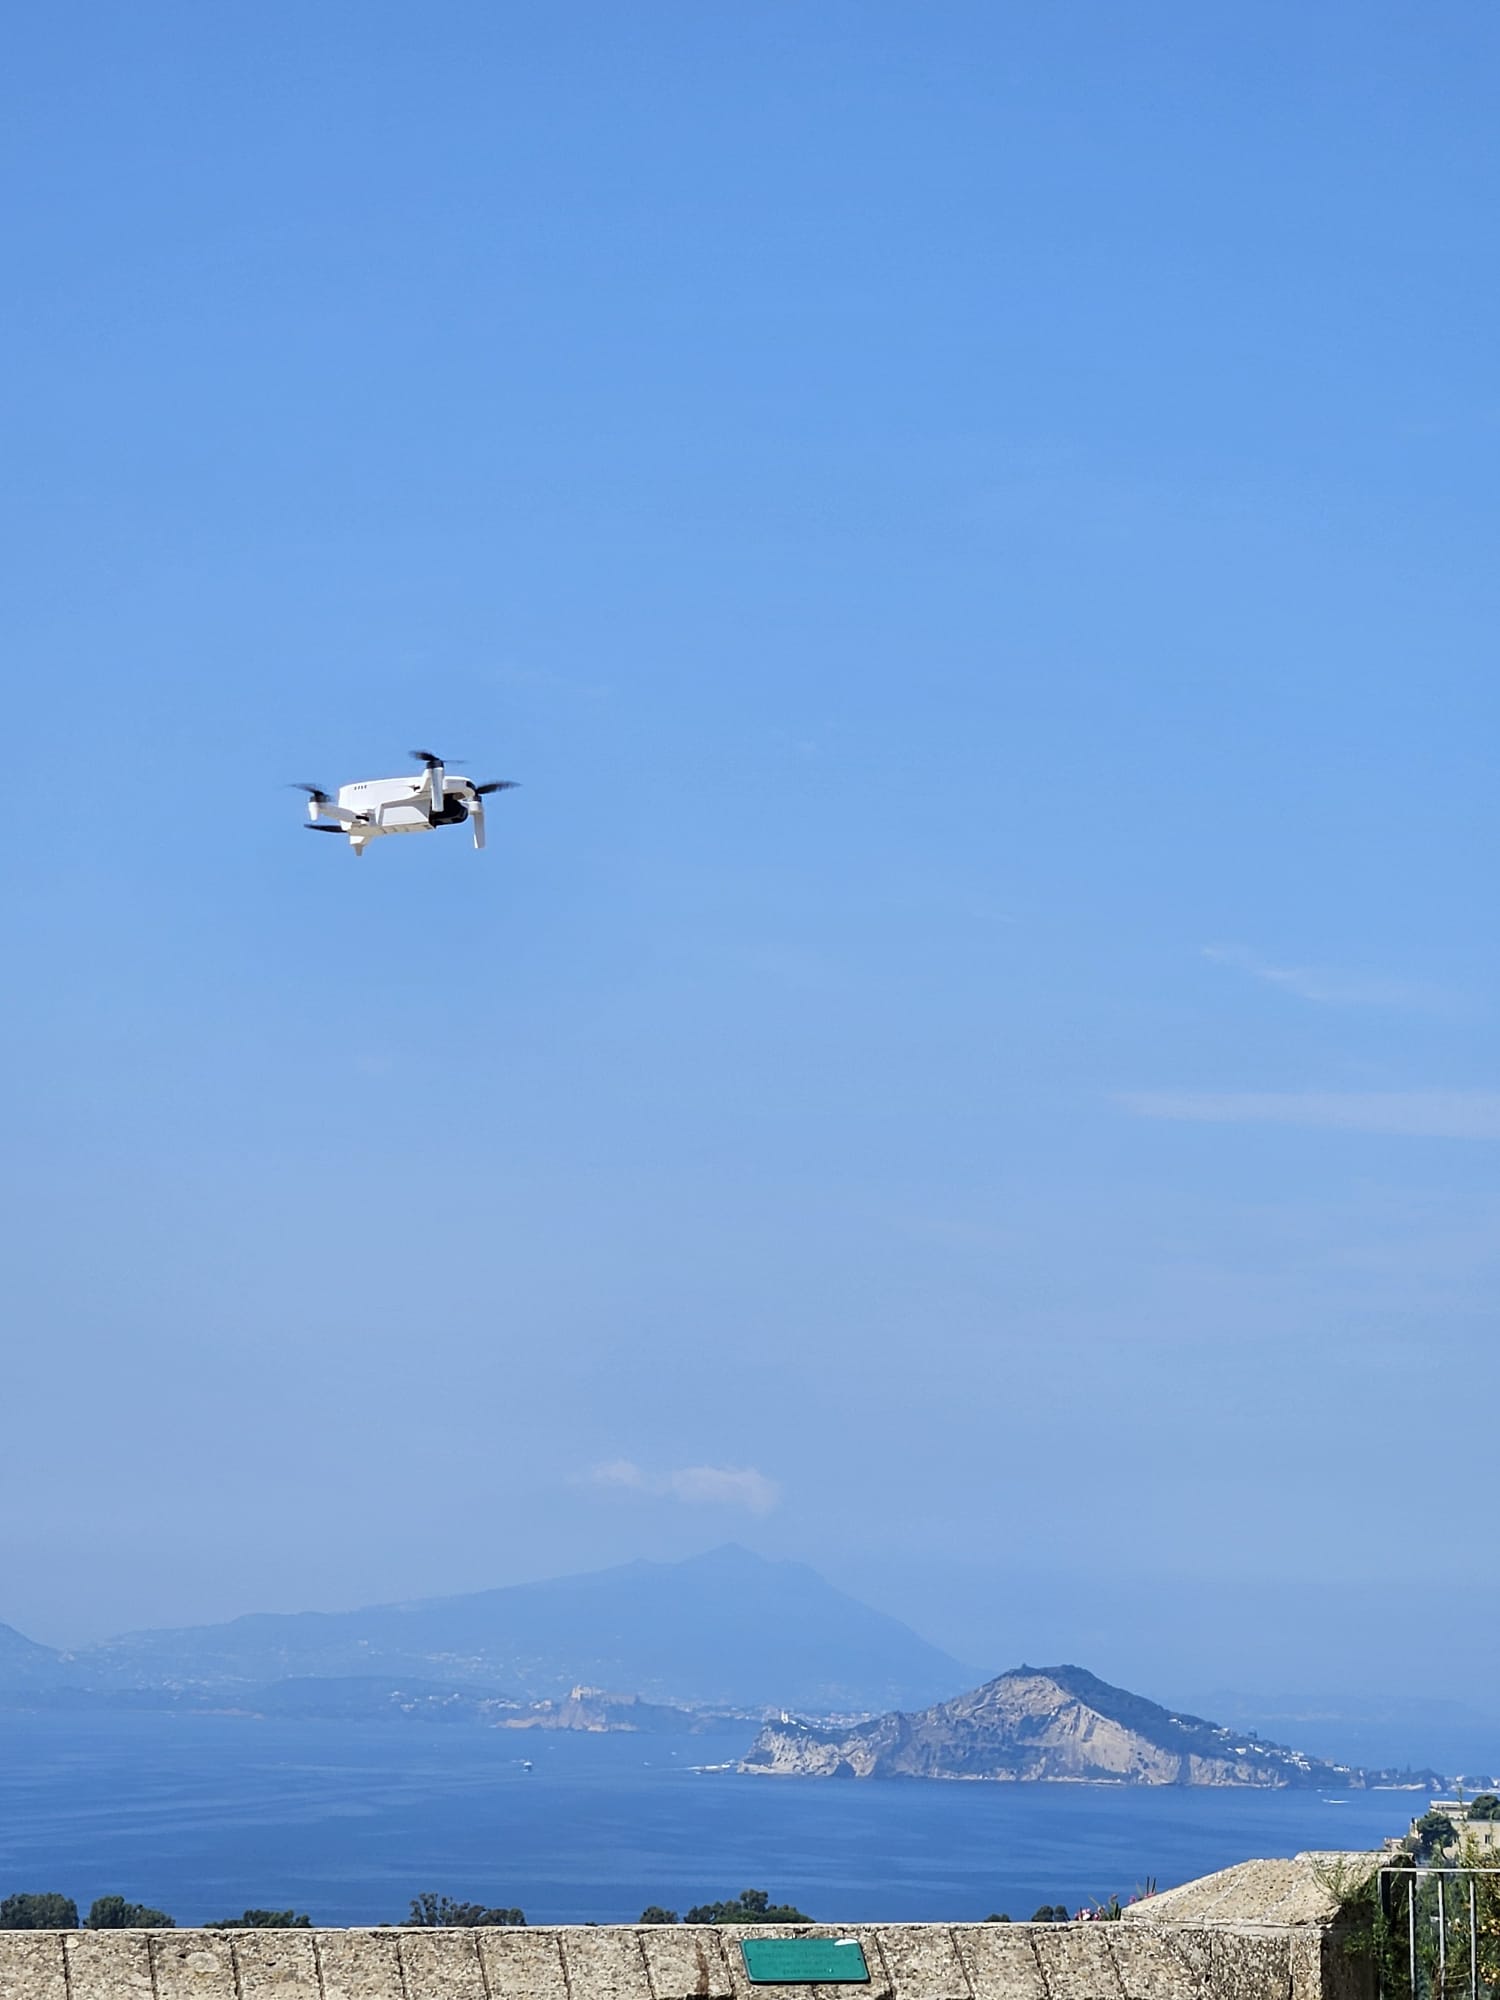
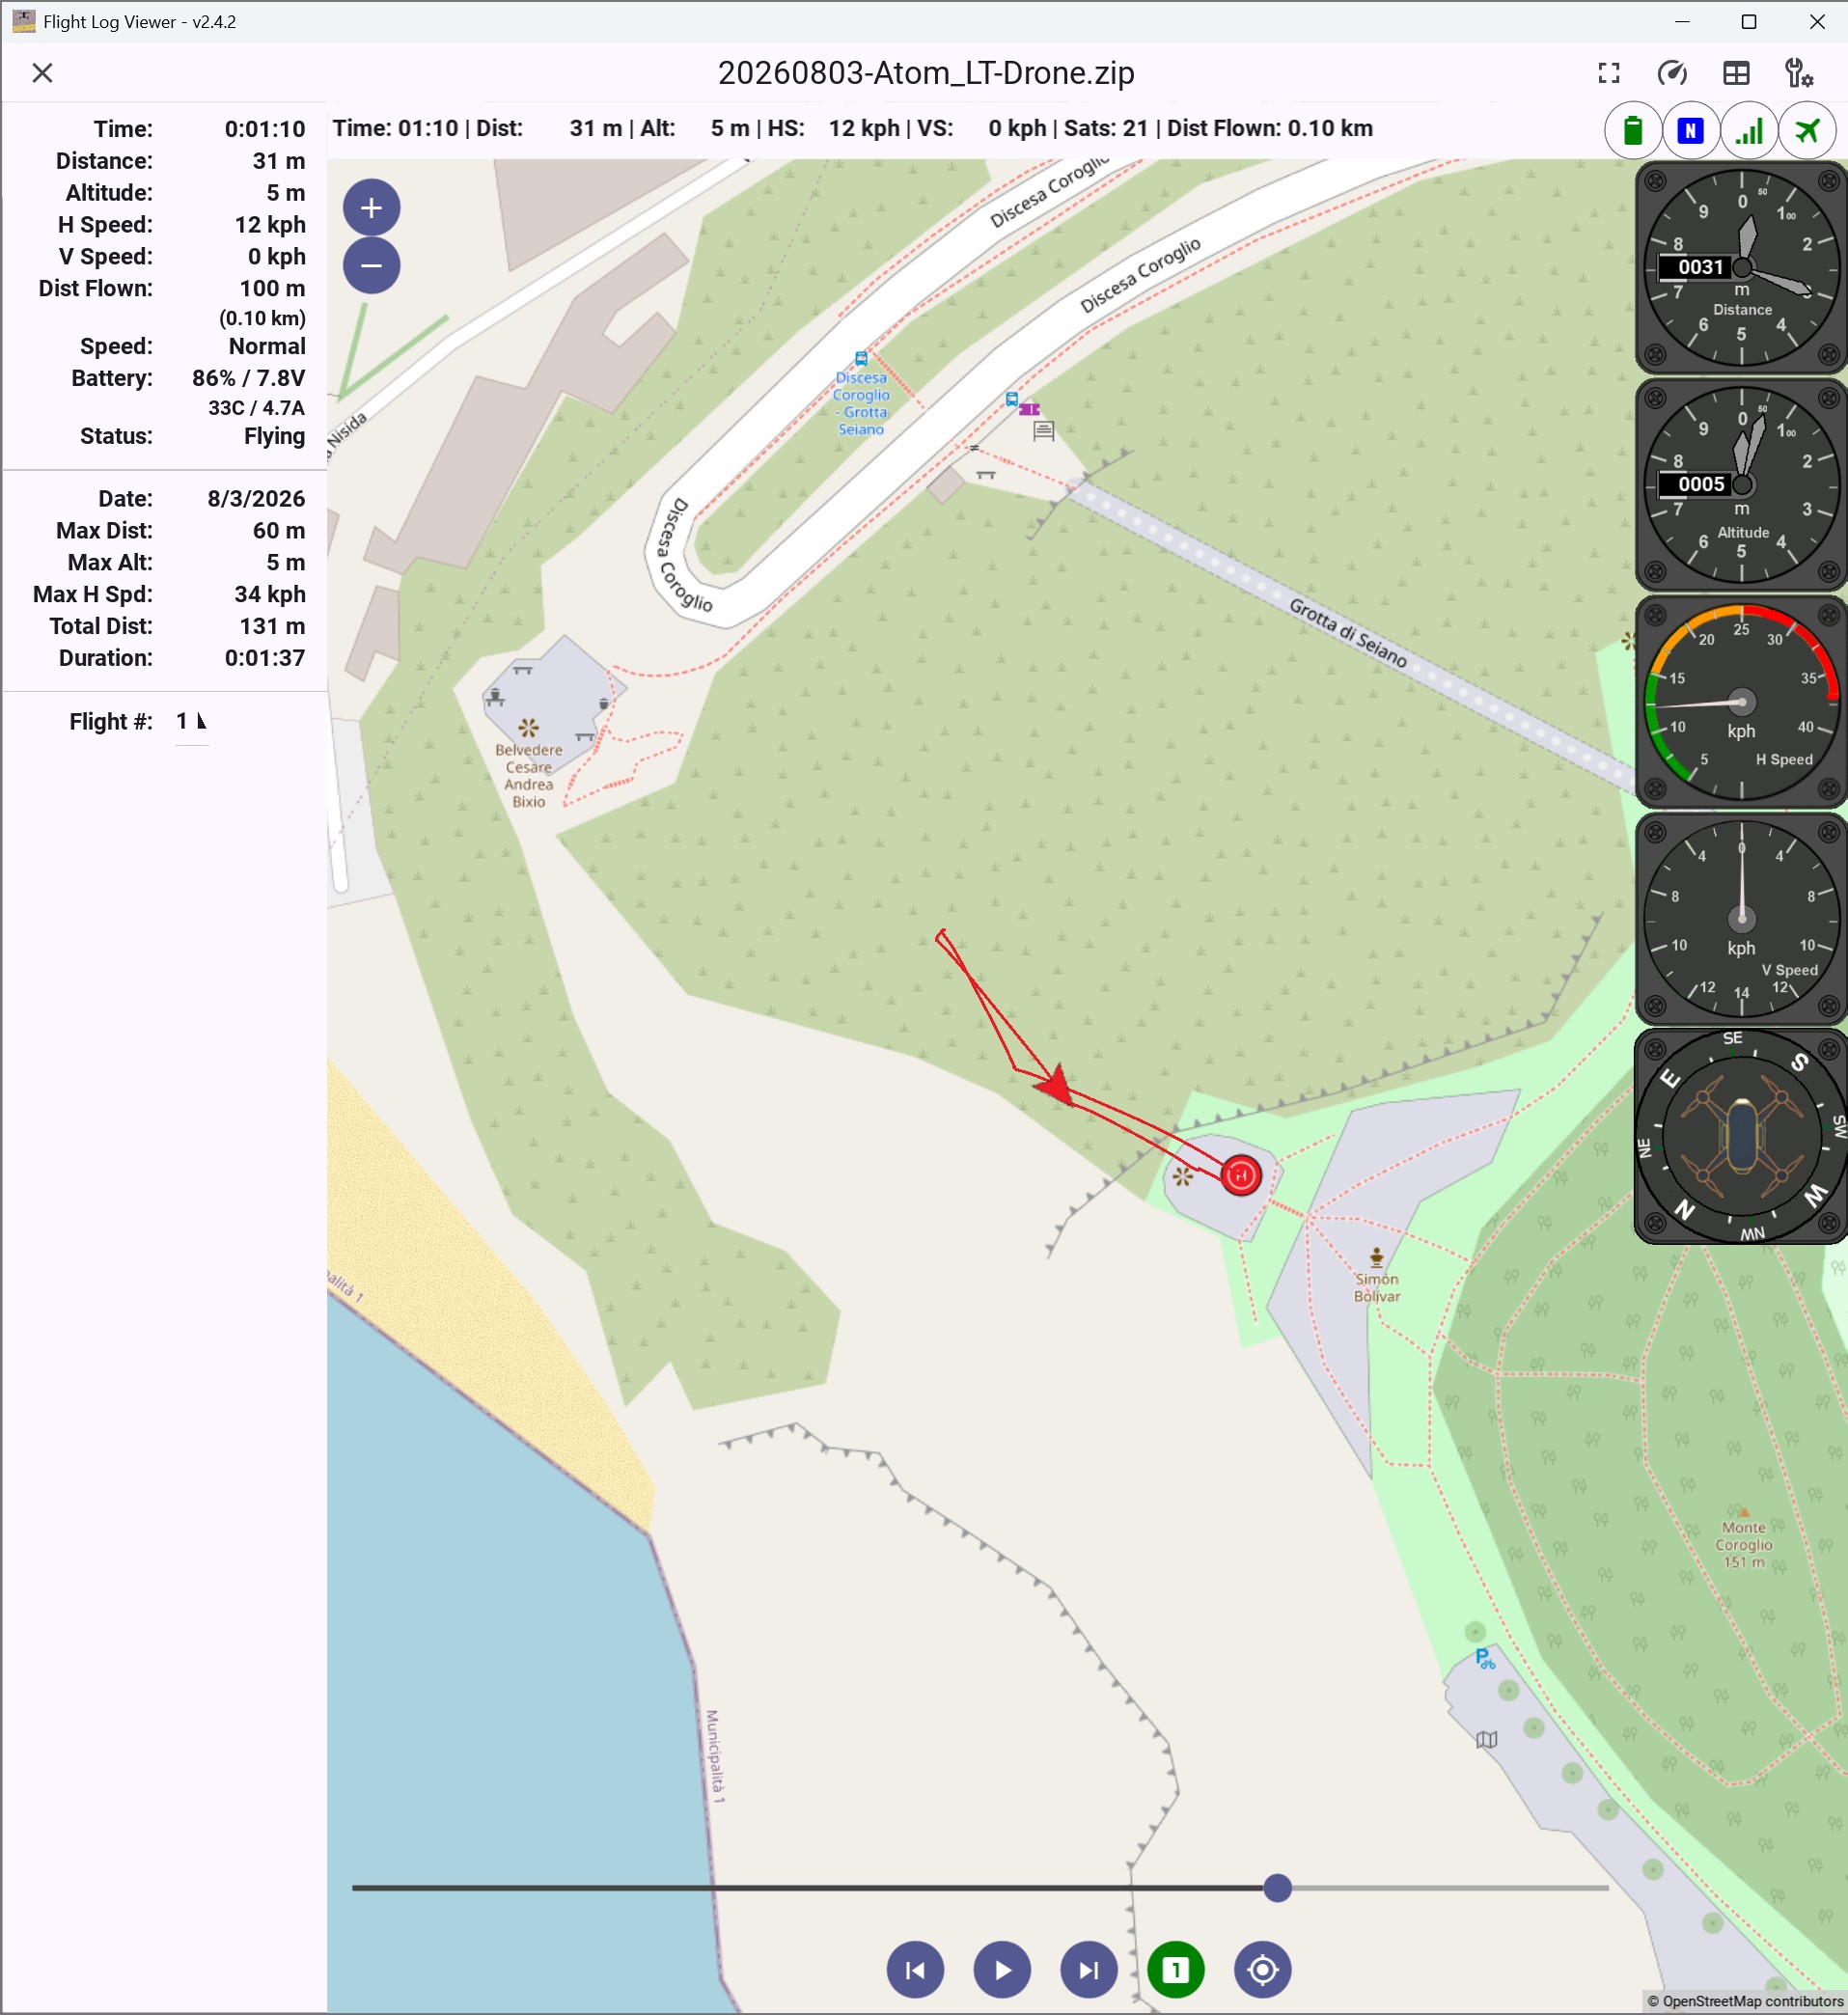
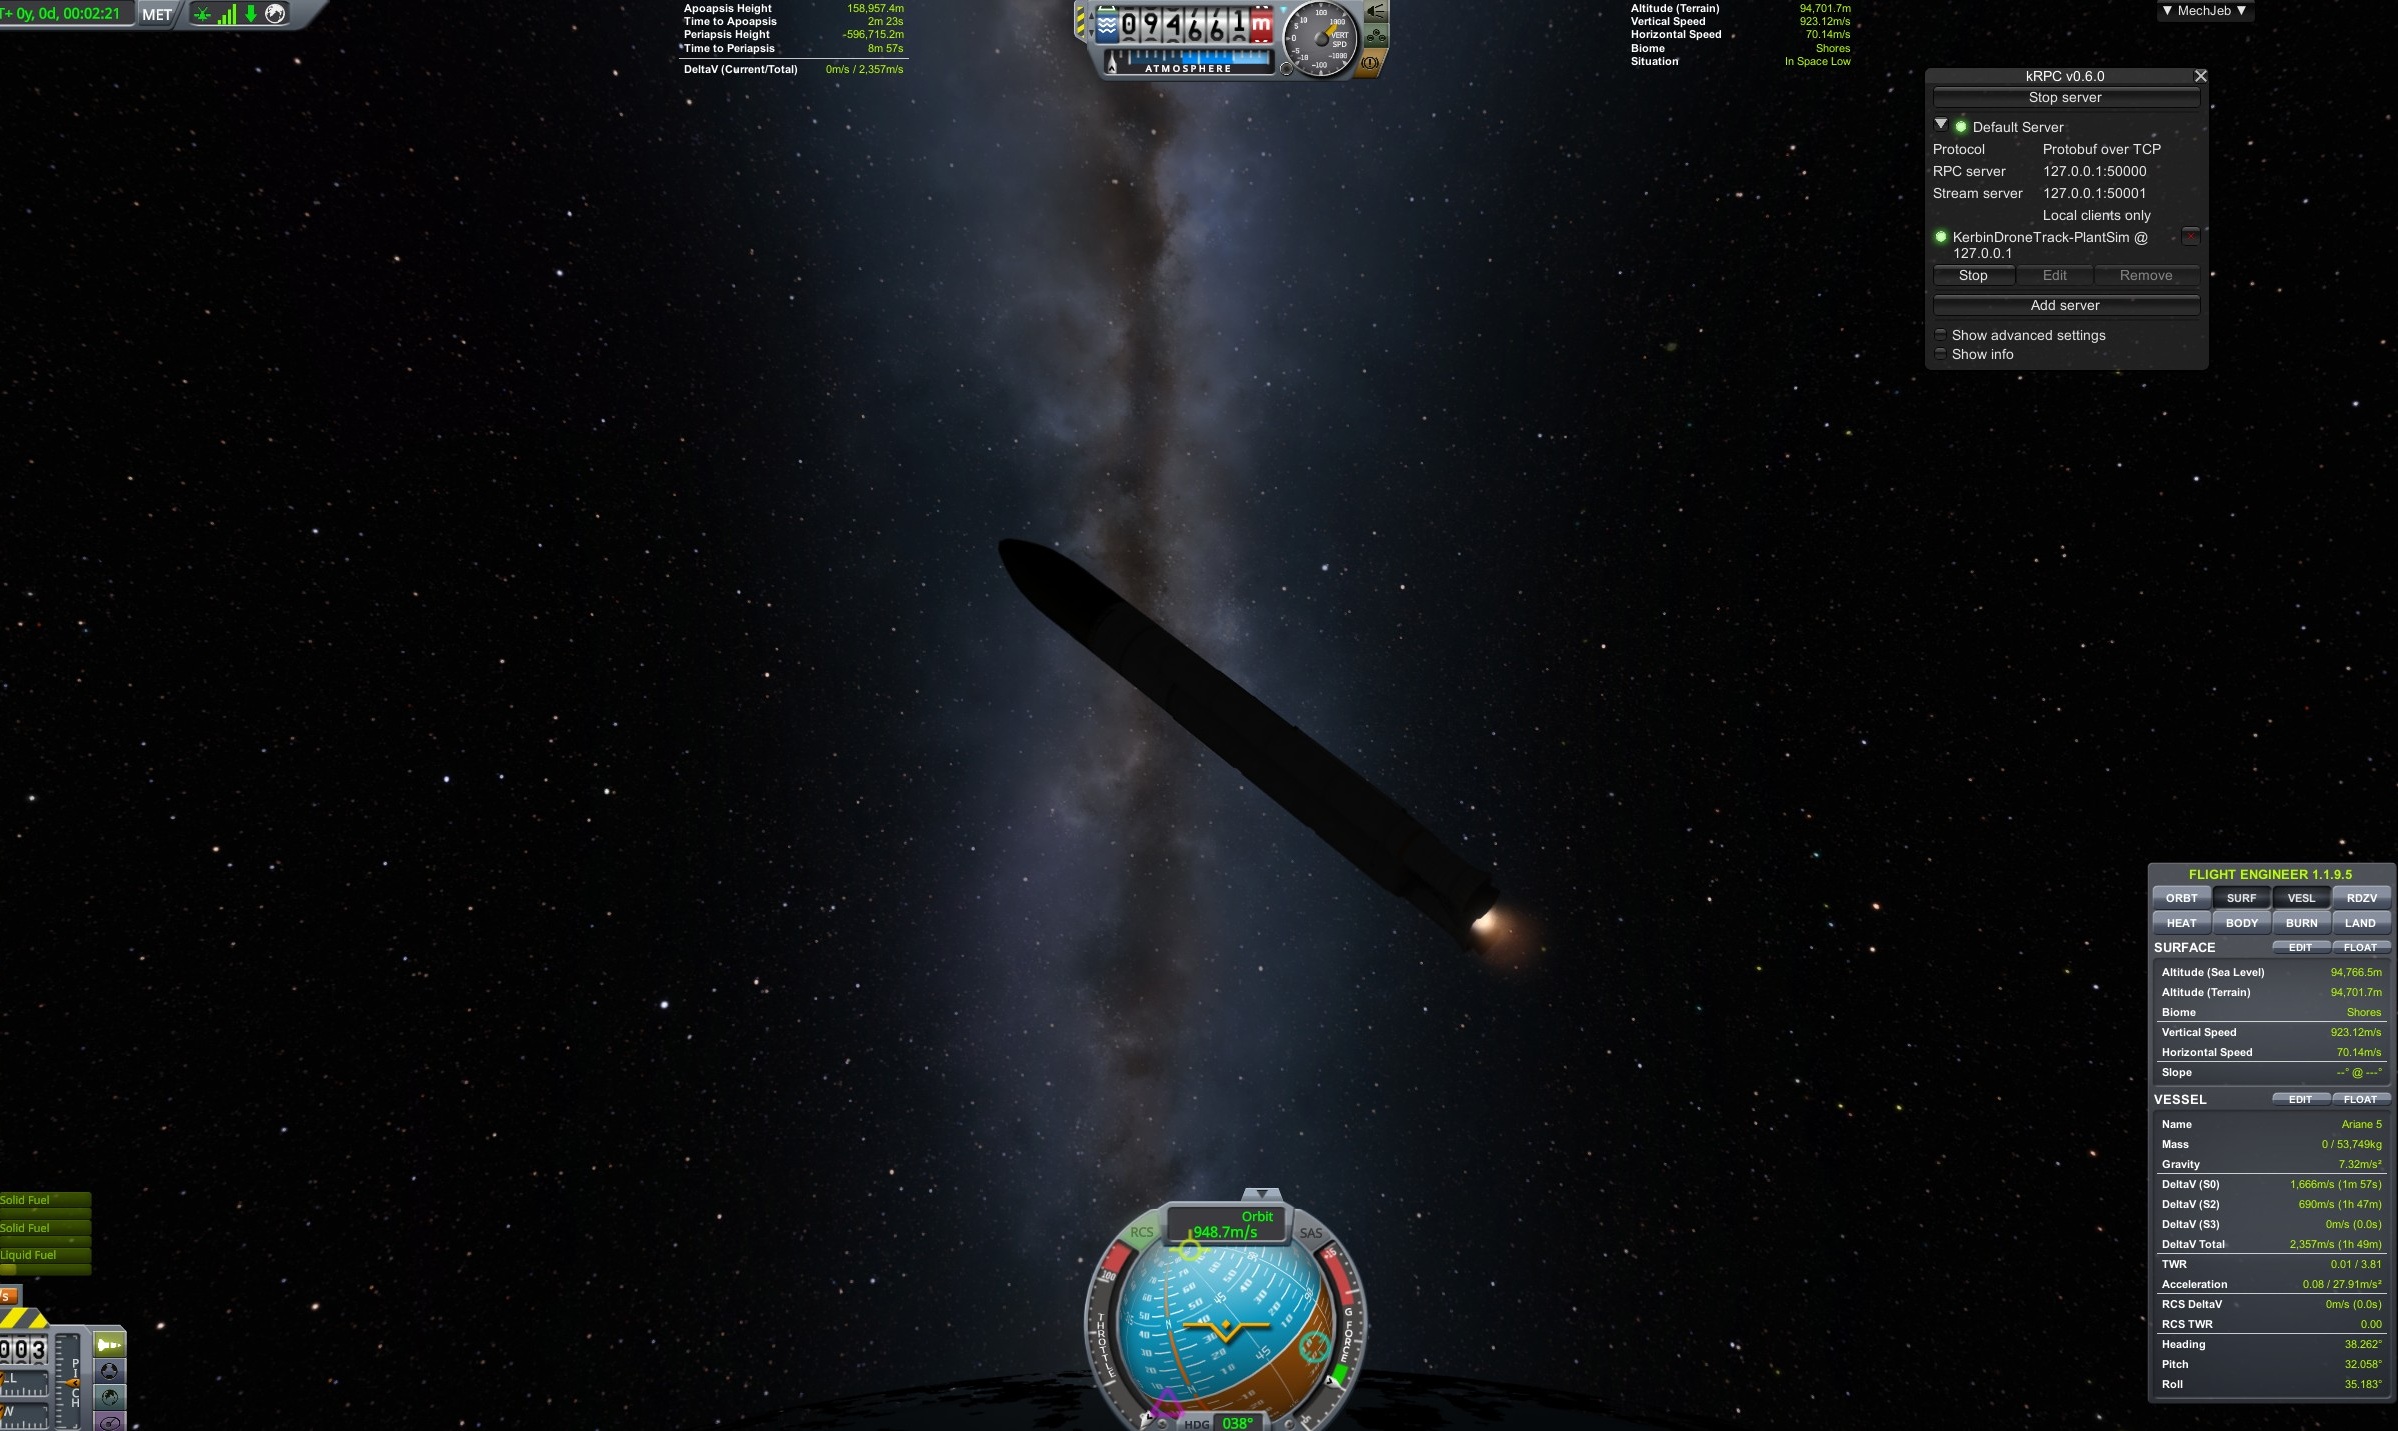
This project develops a full Guidance, Navigation and Control (GNC) stack for estimating and controlling the attitude of an Unmanned Aircraft System (UAS), and validates it against both real flight-log data and a live physics simulation.
Challenge
Turning a noisy, GPS/attitude-only drone log into a clean reference; representing 6-DoF pose/rate error without singularities; keeping the online LTV-LQR Riccati solve well-conditioned; stabilizing the EKF at high velocity while respecting IMU-unobservable states; and reconciling the drone's local motion with the vessel's real, curved Kerbin orbit, which have no shared reference frame.
Approach
Clean and convert the flight log to a local ENU/attitude trajectory; represent pose/error via dual quaternions and screw error throughout; re-linearize and re-solve the LQR gain online with saturated wrenches; restrict EKF corrections to the IMU-observable subspace; and compose the drone's local offset onto a two-body RK4-propagated orbital reference, with configurable playback speed and axis mapping.
Outcome
A working pipeline that replays a real drone flight log as a live attitude reference for a KSP vessel over kRPC, with all components validated (quaternion normalization, orbital propagation accuracy, interpolation correctness). Attitude tracking performs as expected; a known limitation is documented where coupled position error can grow large due to the two systems' unrelated reference frames.